# Welcome

To the most advanced hardware and software ecosystem for enterprise drones.

## Sky-Drones Online Documentation

We provide the entire full-stack hardware and software ecosystem for enterprise drones.

This online documentation covers the how-to, what-if, and just-in-case elements of our whole product range, including:

[SmartAP AIRLink](/avionics/airlink): The most advanced AI Drone Avionics: autopilot, mission computer and LTE module.

[AIRLink Telemetry](/avionics/airlink-telemetry): Command & Control + video broadband datalink with AES-256 encryption and 20km.

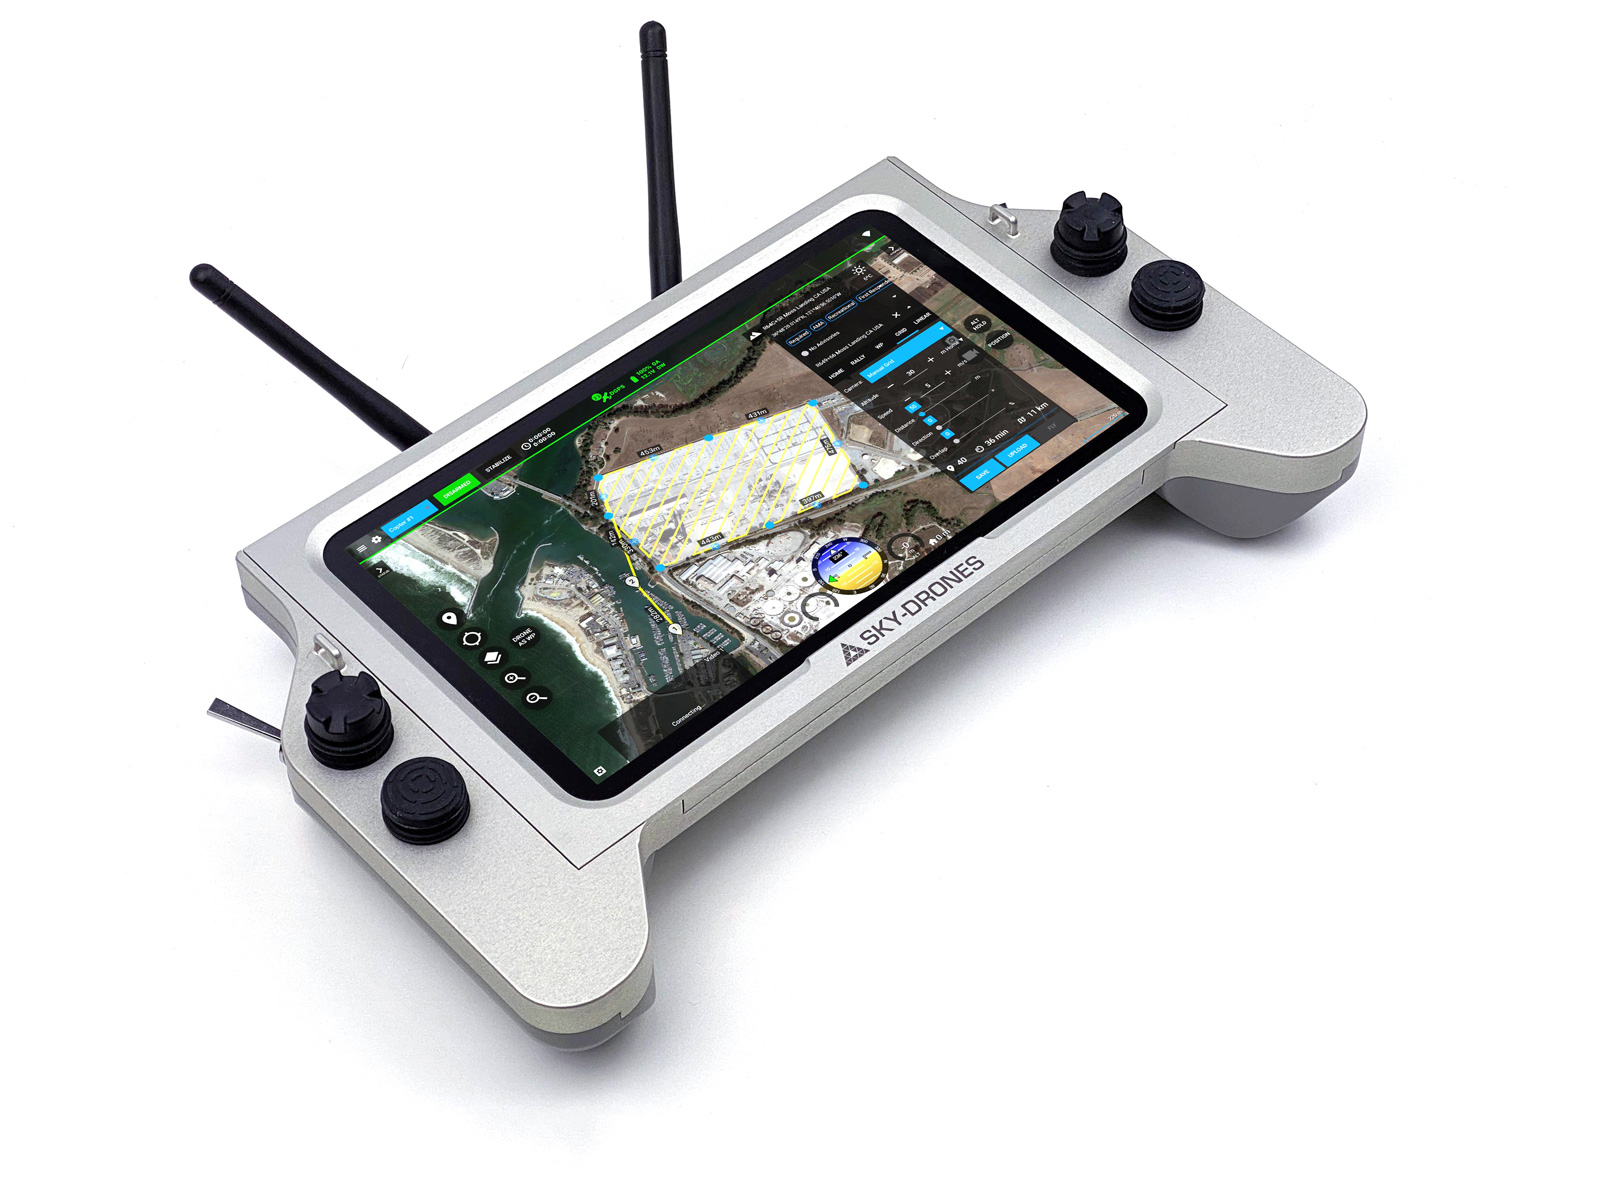
[ATLAS Handheld](/avionics/atlas-handheld): Compact and light weight IP-rated mobile industrial handheld ground station unit.

[SmartLink](/avionics/smartlink): Drone connectivity system with integrated onboard computer. Provides direct datalink, LTE connectivity, video streaming, remote control from the Cloud and more.

[Sky-Drones Cloud](/flight-operations/cloud): Cloud-based web application for drone fleet management, asset management, performance monitoring, mission planning, real-time control and post-flight AI analytics.

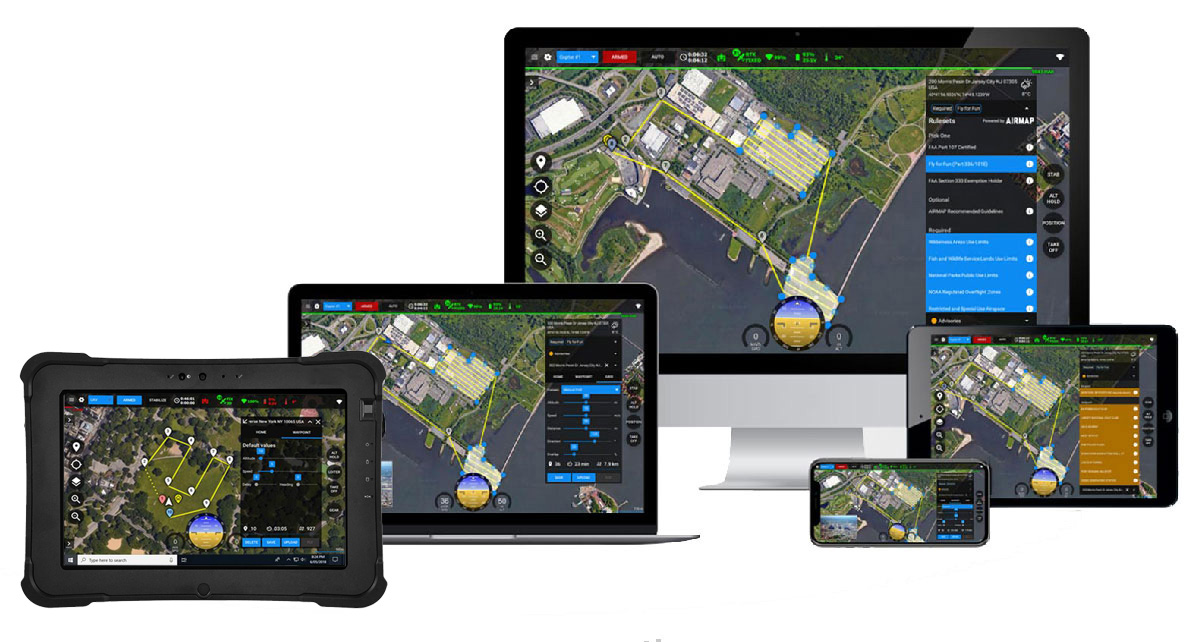
[SmartAP GCS](/flight-operations/smartap-gcs): Cross-platform ground control station software for vehicle configuration, mission planning and flight control.

[SmartAP PDB](/avionics/smartap-pdb): Power transfer from the battery to ESCs / motors and power supply for the flight controller and other peripherals with different voltage levels.

[SmartAP MAX](/avionics/legacy-autopilots): Legacy Flight Control System aimed at a wide range of purposes for consumer and professional applications with a compact main core and externally connected peripherals.

[SmartAP PRO](https://github.com/aviaks/SmartAP-Docs/tree/26912afd4da01dc4c66f7513f989640a408e0856/smartap-pro/specifications/README.md): Legacy Flight Control System with outstanding reliability, precision positioning, and control accuracy for professional applications with various peripherals already integrated onboard.

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2Ff2CzsqHsrSEMxaaV5yKv%2FSky-Drones%20Pitch%20Deck%20-%20May%202022%20ID%20VERSION%2022052022.jpg?alt=media&amp;token=825c6324-fc70-4fd8-8e07-0cf4ec03cab0" alt=""><figcaption></figcaption></figure>

## Hardware Products

### SmartAP AIRLink - The most advanced AI Drone Avionics

![SmartAP AIRLink Enterprise Edition](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYqCGKcn2TyCppgkgm5%2F-MYqDRUcFZEvIBnIYlHw%2F23.jpg?alt=media\&token=52505cb3-6573-4bfd-af8d-74cb056e129f)

[AIRLink](/avionics/airlink) stands for Artificial Intelligence & Remote Link. The unit includes cutting-edge drone autopilot, AI mission computer and LTE connectivity unit. Start your enterprise drone operations with [AIRLink](https://sky-drones.com/airlink) and reduce the time to market from years and months down to weeks.

### AIRLink Telemetry - C2 & Video Datalink

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FBq8T3bPuxKwTACZwFc46%2Fairlink-telemetry.jpg?alt=media&amp;token=3daff1b5-c76a-49cf-8a51-571f97d6b89b" alt=""><figcaption></figcaption></figure>

AIRLink Telemetry provides broadband AES-256 encrypted private channel for 20km.

### ATLAS Handheld

[Atlas Handheld](#atlas-handheld) is a compact and light weight IP-rated mobile industrial handheld ground control unit. It includes powerful computer, broadband datalink, HD Video transmission, LTE connectivity, touchscreen and much more.

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FjxPbtuXrbyLL10njz2Ih%2Fatlas-controller-index.jpg?alt=media&amp;token=faf1d37c-ddf9-49f8-94da-23c3abcd3037" alt=""><figcaption></figcaption></figure>

### SmartLink - Drone Datalink & Onboard Mission Computer

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ4vmMTOirQcZELeDo%2F-MTQ4xTa7nDLXUAefLgA%2Fsmartlink-index.jpg?alt=media\&token=7b230666-9a86-4bf1-9c3c-36a8dcbfa02a)

Broadband Digital Datalink with Integrated Onboard Computer and LTE connectivity. Two HD video channels, telemetry and control with ultra-low latency and a range of up to 20 km.

### SmartAP MAX and SmartAP PRO - Legacy Drone Autopilots

![Legacy Sky-Drones flight controllers - SmartAP PRO and SmartAP MAX](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPy6SZYbfFcNnMgw_n%2F-MTPzDtYNA8Cfl-IA4df%2Fpro-max.jpg?alt=media\&token=3f47b059-a408-4b54-9f27-249be86c7e0f)

### Navigation and Power Distribution

![SmartAP GNSS, SmartAP RTK, SmartAP PDB](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPy6SZYbfFcNnMgw_n%2F-MTQ-6KZIMezcR393bNU%2Fsmartap-gnss-rtk-pdb.jpg?alt=media\&token=b458f077-61fb-438c-aded-e0d0a1055361)

Hardware can be purchased in the official [Sky-Drones Store](https://sky-drones.com/store).

## Software Products

### SmartAP GCS

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FB60vYPvj6mFvgtXSSl8b%2Fimage.png?alt=media&amp;token=a8a68e34-5b01-47bd-af4a-1d44e4e85821" alt=""><figcaption><p>SmartAP GCS running on multiple platforms</p></figcaption></figure>

Configure, plan missions, and operate multiple drones with our cross platform ground control station software. The LTE connectivity allows users to sync their data pre, post, or during flights, and the HD video streaming gives a clearer and wider image than ever before. Furthermore, our most recent advancements have made it possible to alter the quality and latency optimisation mid-flight, just another customisable feature we provide our users with.&#x20;

[Learn more about SmartAP GCS](/flight-operations/smartap-gcs)

### Sky-Drones Cloud

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTMsnUqY9p8XptOepPg%2F-MTMszpVyPP8yWadPSND%2Findex-sky-drones-cloud.jpg?alt=media\&token=b86b515b-2eaa-4129-b8c8-a7f738ccd60f)

Cloud-based web application for drone fleet management, performance monitoring, mission planning, real-time control and post-flight AI analytics.&#x20;

[Sign up for our Cloud here!](https://cloud.sky-drones.com/accounts/login/?next=/)

{% hint style="success" %}
Need any help with the products? Just want some advice? Would like to have customized solution based on our core technology?

Feel free to get in touch with us using the [Contact Form](http://sky-drones.com/contact-us).
{% endhint %}


# The Platform

The most advanced hardware and software ecosystem for enterprise drones

Sky-Drones provides avionics hardware and software solutions for drone manufacturers and drone service providers.

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FHBOEANWkpxv6IIxMPCVA%2Fwiring-low-res.jpg?alt=media&amp;token=747357cb-7dcf-4dfc-8dfa-defb88584560" alt=""><figcaption></figcaption></figure>

The Sky-Drones Platform helps to integrate drones in custom end-to-end workflows with an abundance of advanced features that are essential to enterprise customers including:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYVjr6eeQ_AQ2iEQvJz%2F-MYVmXcbPwkBVkJTigre%2FConnected%20drones.png?alt=media\&token=3f83710c-ee10-4138-bab2-fe03d358b7ce)

* Real-time digital HD video streaming;
* Real-time payload data processing (e.g. computer vision);
* Real-time flight control (e.g. target tracking, collision prevention and obstacle avoidance);
* In-flight telemetry and payload data streaming directly to customer’s cloud;
* Drone-to-drone communications;
* Running custom apps directly on the drone (edge computing);
* Safely performing autonomous BVLOS missions with real-time control.

## Sky-Drones Platform Structure

### Software

* [Advanced drone software](broken://pages/-MYW2AnJBL5uBq79HNNn) powered by [SmartAP AIRLink](/avionics/airlink).
* [SmartAP GCS](/flight-operations/smartap-gcs) - super easy and intuitive 3D mission planning and remote flight control applications for Windows, macOS, Linux, iOS, Android + web application in the [Sky-Drones Cloud](/flight-operations/cloud).&#x20;
* [Sky-Drones Cloud](/flight-operations/cloud):&#x20;
  * 3D mission planning & control web application;
  * Drone fleet management, performance monitoring, post-flight AI-analytics;
  * Integration services, the “glue” that connects drones, apps, partners and customers' software (see how [Sky-Drones API](/flight-operations/cloud/api) was designed for customers).
* Tightly integrated partner software such as UTM services, fleet management solutions, flight logs, etc.

{% hint style="success" %}
**All Sky-Drones software is free to use!** Software **integrations** from our partners (e.g. UTM) cost according to partners pricing model.
{% endhint %}

### Hardware

Sky-Drones provides its users with a comprehensive set of leading drone avionics, entirely designed and manufactured in the UK:

* [SmartAP AIRLink](/avionics/airlink) - the most advanced AI drone flight controller;
* [AIRLink Telemetry System](/avionics/airlink-telemetry) - broadband AES-256 encrypted digital datalink for 20km.
* [SmartLink](/avionics/smartlink) - broadband digital datalink with an onboard computer and LTE option for third-party autopilots;
* [SmartAP PDB](/avionics/smartap-pdb) - power distribution board with the voltage / current sensor and power supply;
* [SmartAP GNSS](/avionics/smartap-gnss) - high-precision GNSS, barometer and magnetometer module.

Sky-Drones ships its partner drones and accessory equipment (for instance, [uAvionix pingRX](https://uavionix.com/products/pingrx/) ADS-B receiver). We are listed sellers for our partners so make sure you [get in touch](https://sky-drones.com/contact-us) to find out more!

## Sky-Drones Platform Options

Sky-Drones Platform is fully compatible with different types of aircraft. Sky-Drones customers have been using the platform for years in BVLOS and EVLOS flights, alongside fully autonomous and GNSS-assisted manual missions.&#x20;

Sky-Drones offers two major purchasing options:

* Quick-start using comprehensive ready-made hardware and free software sets;
* Attractive terms for bulk purchasing customers and customization requirements:
  * on-site production;&#x20;
  * deep hardware and software customization;
  * integration with customer's infrastructure.

For further information please see:

{% content-ref url="/pages/-MYWIRO\_1p1kKKr4TQKa" %}
[Hardware procurement and licensing](/general/sky-drones-platform/procurement-and-licensing-options)
{% endcontent-ref %}

{% content-ref url="/pages/-MYWE49VgVeYHu8lDVOf" %}
[Software distribution and deployment](/general/sky-drones-platform/software-distribution-and-deployment)
{% endcontent-ref %}


# Hardware procurement and licensing

Learn more about the different option for getting Sky-Drones Hardware

## Purchasing Hardware from Sky-Drones

We appreciate the different integration levels required by the drone manufacturers. Therefore we offer two slightly different editions of AIRLink - the most advanced drone avionics: **Enterprise** and **Core**. **AIRLink Enterprise** is ideal for a quick start, evaluation and prototyping while **Core** is optimised for deep integration and mid-high volume manufacturing.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MbXCKcHVi2BDwSxqp_j%2F-MbXH8LrGXaFHYZme0-F%2Fimage.png?alt=media\&token=b03fc689-6278-4c4f-b93b-5adfd8cc8f80)

| Parameter             | AIRLink Enterprise                                          | AIRLink Core                                                                        |
| --------------------- | ----------------------------------------------------------- | ----------------------------------------------------------------------------------- |
| Enclosure             | Aluminum, with integrated heatsink and fan mounting option. | External heatsink or reasonable power dissipation should be provided by the design. |
| Dimensions            | L103 x W61 x H37 mm                                         | L100 x W57 x H22 mm                                                                 |
| Weight                | 198 g                                                       | 89 g                                                                                |
| Operating temperature | -40°C-..+50°C                                               | -40°C-..+50°C                                                                       |
| Production volume     | Low to Medium                                               | Medium to High                                                                      |

SmartAP AIRLink Core edition is intended for medium to high volume production and deep integration with customer's hardware. The weight of electronics is only 80g and can be tightly integrated in the airframe design. However, heat dissipation requirements (provided by Sky-Drones) should be met for proper system operation.

## Hardware licensing

### Licensed Production

Sky-Drones team is glad to help mid to large size manufacturers to set up their local production of the hardware. This option is recommended for the customers who are scaling up and aim to optimise the logistics.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYWTIcWQUIrYxiX_js-%2F-MYWVZHXlrPGtawF45qp%2Freference%20design.png?alt=media\&token=8fc6ac82-4003-4dfb-a826-161536a2e60f)

This option is intended for:

* Drone manufacturers;
* Mid to High-volume production;
* Deep integrations.

Customer can:

* Manufacture at their own factory;
* Control the volume;
* Modify schematics and layout to suit the needs.


# Software distribution and deployment

Learn more about different options of running Sky-Drones software

## Quick start&#x20;

Sky-Drones software comes free with the hardware. Customers can use the most advanced hardware along with a free software suite of SmartAP GCS + Sky-Drones Cloud.

## Private deployment

Sky-Drones software can be deployed on a custom third party server and used securely and privately.&#x20;

## Software customisation and integrations

Sky-Drones team implements software customisations according to customer requirements and custom integrations with customer's IT systems.


# Revision History

| Version | Date       | Description                                                          |
| ------- | ---------- | -------------------------------------------------------------------- |
| 2.1.3   | 09.03.2023 | - Added ecosystem wiring diagram                                     |
| 2.1.2   | 22.09.2022 | - Added RNDIS drivers information                                    |
| 2.1.1   | 10.09.2022 | - Added information about new ground module                          |
| 2.1.0   | 18.07.2022 | - Added information on AIRLink                                       |
| 2.0.9   | 25.08.2021 | - Added serial devices mapping table                                 |
| 2.0.8   | 15.08.2021 | - Added Software development tutorial and examples                   |
| 2.0.7   | 10.08.2021 | - Added ground module driver instructions                            |
| 2.0.6   | 05.08.2021 | - Added Autopilot Bootloader update instructions                     |
| 2.0.5   | 28.07.2021 | - Added SmartAP PDB high voltage recommendations                     |
| 2.0.4   | 28.06.2021 | - Added SmartLink and AIRLink unboxing video                         |
| 2.0.3   | 06.06.2021 | - Added more information about SmartAP AIRLink configuration         |
| 2.0.2   | 25.05.2021 | - Added Mission Planner connection instructions                      |
| 2.0.1   | 15.04.2021 | - Added AIRLink main page and CAD model                              |
| 2.0.0   | 12.02.2021 | - Major refactor and update                                          |
| 1.4.2   | 29.01.2021 | - Added SmartLink update instructions                                |
| 1.4.1   | 20.01.2021 | - Some images updated                                                |
| 1.4.0   | 28.12.2019 | - Added on simulatenous internet connection and SmartLink connection |
| 1.3.9   | 10.09.2019 | - Added info on SmartLink direct connection with IP instead DNS      |
| 1.3.8   | 21.08.2019 | - Structure reorganized, more SmartLink info                         |
| 1.3.7   | 19.08.2019 | - Added SmartLink quick start guide                                  |
| 1.3.6   | 05.07.2019 | - Added SmartLink firmware update tutorial                           |
| 1.3.5   | 12.02.2019 | - Added SmartLink documentation                                      |
| 1.3.4   | 15.08.2018 | - Bootloader flashing information added                              |
| 1.3.3   | 03.06.2018 | - Added info about relay camera trigger and feedback                 |
| 1.3.2   | 16.05.2018 | - Creating new mission and flying with SmartAP GCS                   |
| 1.3.1   | 06.05.2018 | - Added information about the latest SmartAP GCS                     |
| 1.3.0   | 05.03.2018 | - Updated SmartAP GNSS module information                            |
| 1.2.9   | 03.01.2018 | - Added OSD Layout image                                             |
| 1.2.8   | 01.11.2017 | - Added camera settings to Configurator                              |
| 1.2.7   | 28.08.2017 | - SmartAP MAX Added                                                  |
| 1.2.6   | 20.08.2017 | - Added RSSI section                                                 |
| 1.2.5   | 08.08.2017 | - Added logs processing info                                         |
| 1.2.4   | 21.06.2017 | - Added standard PID presets section                                 |
| 1.2.3   | 09.06.2017 | - Info about the foam for pressure sensor updated                    |
| 1.2.2   | 06.06.2017 | - Added more information on SmartAP 3.2                              |
| 1.2.1   | 02.06.2017 | - Minor updates on index page                                        |
| 1.1.9   | 24.05.2017 | - Added section about creating Region based waypoints                |
| 1.1.8   | 21.05.2017 | - OSD information updated                                            |
| 1.1.7   | 15.05.2017 | - Added SmartAP 3.2 pinout                                           |
| 1.1.6   | 12.04.2017 | - Minor updates and support of offline PDF version                   |
| 1.1.5   | 06.04.2017 | - SmartAP GNSS v2 and v3 dimensions added                            |
| 1.1.4   | 04.04.2017 | - SmartAP 3.x dimensions image added                                 |
| 1.1.3   | 30.03.2017 | - SmartAP Autopilot drivers installation section added               |
| 1.1.2   | 18.02.2017 | - SmartAP 3.x PDB connections scheme added                           |
| 1.1.1   | 17.02.2017 | - SmartAP OSD extended documentation                                 |
| 1.1.0   | 12.02.2017 | - SmartAP RTK GNSS information added                                 |
| 1.0.9   | 28.01.2017 | - SmartAP OSD configuration info added                               |
| 1.0.8   | 15.01.2017 | - SmartAP PDB specifications added                                   |
| 1.0.7   | 02.10.2016 | - SmartAP GCS for autonomous flight section added                    |
| 1.0.6   | 29.03.2016 | - Firmware update, GPS module update instructions                    |
| 1.0.5   | 15.12.2015 | - DFU generation section removed                                     |
| 1.0.4   | 13.12.2015 | - GPS firmware update description                                    |
| 1.0.3   | 01.10.2015 | - External GPS / Magnetometer connections                            |
| 1.0.2   | 03.08.2015 | - Added pinout description, PID tuning hints                         |
| 1.0.1   | 09.12.2014 | - Minor fixes in all sections                                        |
| 1.0.0   | 06.12.2014 | - Initial release of the Guide                                       |


# SmartAP AIRLink

The most Advanced AI Drone Flight Controller

[AIRLink](https://sky-drones.com/airlink) stands for Artificial Intelligence & Remote Link. The unit includes a cutting-edge drone autopilot, AI mission computer and LTE / 5G connectivity unit. Start your enterprise drone operations with AIRLink and reduce the time to market from years and months down to weeks.

### SmartAP AIRLink launch video

{% embed url="<https://www.youtube.com/watch?v=VcBx9DLPN54>" %}
AIRLink product launch video (< 2 min)
{% endembed %}

### SmartAP AIRLink Launch Webinar (LIVE)

On April 14th, 2021 Kirill Shilov, Founder & CEO Sky-Drones held a live launch webinar where he presented the three-in-one revolutionary product to the drone industry.

Watch the full webinar recording on YouTube if you missed the live event.

{% embed url="<https://www.youtube.com/watch?v=_d3SZ3LBoeU>" %}
AIRLink launch webinar
{% endembed %}

### SmartAP AIRLink - How it's made

Take a look at AIRLink manufacturing process.&#x20;

{% embed url="<https://www.youtube.com/watch?v=2gg9Ne488KQ>" %}
SmartAP AIRLink - How it's made
{% endembed %}

### Datasheet

Please refer to the PDF datasheet below for the detailed technical specifications.&#x20;

{% file src="/files/vkYimy7c8trUd7QF1ohq" %}
SmartAP AIRLink Datasheet
{% endfile %}

### Useful resources

{% content-ref url="/pages/-MYW7JCXQHwfc4R2LCQS" %}
[Hardware](/avionics/airlink/hardware)
{% endcontent-ref %}

{% content-ref url="/pages/-MYWIRO\_1p1kKKr4TQKa" %}
[Hardware procurement and licensing](/general/sky-drones-platform/procurement-and-licensing-options)
{% endcontent-ref %}


# Hardware

SmartAP AIRLink hardware architecture overview

## General specifications

[SmartAP AIRLink](https://sky-drones.com/airlink) has two computers and integrated LTE / 5G  Module:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MbXLnk8YyjeoxtpTs9M%2F-MbXPBK-gi5Htv9HyNr5%2Fimage.png?alt=media\&token=30dbe8b3-f58f-4062-ba23-0603a05181d5)

* The flight control computer (autopilot) has a triple-redundant vibration-dampened and temperature-stabilized IMU.&#x20;
* The powerful AI mission computer enables [advanced drone software features](broken://pages/-MYW2AnJBL5uBq79HNNn) like computer vision and obstacle avoidance, digital HD video streaming, and payload data streaming.
* LTE / 5G and WiFi connectivity modules provide permanent broadband internet connection which is enabler for remote workflows.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYWWEAuQgtJu3dQiGpV%2F-MYWWLPumCIrEaIYSecO%2F3in1.png?alt=media\&token=80ae1ba7-2a27-4ff3-895f-d40586678922)

### System specifications

<table><thead><tr><th width="150">Parameter</th><th>Value</th></tr></thead><tbody><tr><td>Navigation</td><td>Accelerometers, Gyroscopes, Magnetometer, GNSS, Rangefinders, Lidars, Optical Flow, Visual</td></tr><tr><td>IMU</td><td><p>3x-Redundant </p><p>Vibration dampened<br>Temperature stabilized</p></td></tr><tr><td>GNSS</td><td>GPS, GLONASS, Galileo, BeiDou,<br>RTK (option)</td></tr><tr><td>Flight Modes</td><td>Manual, Stabilize, GNSS-Assisted, Autonomous Waypoints, Guided, Terrain Following</td></tr><tr><td>Flight Logs</td><td>SD Card, up to 256GB</td></tr><tr><td>Ambient temperature</td><td>from -40°C up to +50°C</td></tr><tr><td>Power consumption</td><td>0.6A@12 Volts, 8W (with WiFi, 2 cameras, LTE)</td></tr><tr><td>ECCN</td><td>7E994</td></tr></tbody></table>

### Flight Controller specifications

<table><thead><tr><th width="150">Parameter</th><th>Value</th></tr></thead><tbody><tr><td>Frequency</td><td>216 MHz</td></tr><tr><td>Flash</td><td>2MB</td></tr><tr><td>RAM</td><td>512 kB</td></tr><tr><td>IMU</td><td>3 Accelerometers, 3 Gyroscopes, 3 Magnetometers, 2 Barometers</td></tr><tr><td>Ethernet                                 </td><td>10/100 Mbps<br>LAN with Mission AI Computer</td></tr><tr><td>UARTs</td><td>Telemetry 1, Telemetry 2 (AI Mission Computer), Telemetry 3, GPS 1, GPS 2, Extra UART, Serial Debug Console</td></tr><tr><td>CAN</td><td>CAN 1, CAN 2</td></tr><tr><td>USB</td><td>MAVLink<br>Serial Console</td></tr><tr><td>RC Input</td><td>SBUS, RSSI, PPM, Spektrum</td></tr></tbody></table>

### AI Mission Computer specifications

<table><thead><tr><th width="150">Parameter</th><th>Value</th></tr></thead><tbody><tr><td>CPU</td><td>6-Core: Dual-Core Cortex-A72<br>Quad-Core Cortex-A53</td></tr><tr><td>GPU</td><td>Mali-T864, OpenGL ES1.1/2.0/3.0/3.1</td></tr><tr><td>VPU</td><td>4K VP8/9<br>4K 10bits H265/H264 60fps Decoding</td></tr><tr><td>Power</td><td>Software Reset<br>Power Down<br>RTC Wake-Up<br>Sleep Mode</td></tr><tr><td>RAM</td><td>Dual-Channel 4GB LPDDR4</td></tr><tr><td>Storage</td><td>16GB eMMC 5.1 Flash<br>MicroSD up to 256GB</td></tr><tr><td>Ethernet</td><td>10/100/1000 Native Gigabit</td></tr><tr><td>Wireless (WiFi/BT)</td><td>802.11a/b/g/n/ac<br>Bluetooth<br>2x2 MIMO</td></tr><tr><td>USB</td><td>USB 3.0 Type C</td></tr><tr><td>Video</td><td>4-Lane MIPI CSI (FPV Camera)<br>4-Lane MIPI CSI with HMDI Input (Payload Camera)</td></tr></tbody></table>

### LTE / 5G Connectivity specifications

<table><thead><tr><th width="150">Parameter</th><th>Value</th></tr></thead><tbody><tr><td>LTE                        </td><td>UMTS/HSPA(+), GSM/GPRS/EDGE</td></tr><tr><td>SIM Cards</td><td>Integrated eSIM<br>External MicroSIM card slot</td></tr><tr><td>Antenna</td><td>4G: 2x2 MIMO<br>5G: 4x4 MIMO </td></tr><tr><td>Throughput</td><td>3G: up to 42 DL/11 UL Mbps<br>4G: up to 2 Gbps DL/211 Mbps UL<br>5G: up to 5.5 DL/1.5 UL Gbps</td></tr><tr><td>LTE Bands</td><td>1, 2, 3, 4, 5, 7, 8, 12, 13, 14, 17, 18, 19, 20, 25, 26, 28, 29DL, 30, 32, 34, 38, 39, 40, 41, 42, 43*, 46(LAA), 48(CRS), 66, 71</td></tr><tr><td>5G Bands </td><td>n1, n2, n3, n5, n7, n8, n12*, n20, n25, n28, n38, n40, n41, n48, n66, n71, n77, n78, n79</td></tr><tr><td>Locations</td><td>4G: EMEA, North America, Australia, Japan, other<br>5G:  Global</td></tr></tbody></table>

{% hint style="info" %}
Please refer to the datasheet below for full specs.
{% endhint %}

{% file src="/files/vkYimy7c8trUd7QF1ohq" %}
SmartAP AIRLink Datasheet
{% endfile %}

## SmartAP AIRLink Enterprise and Core

We appreciate the different integration levels required by the drone manufacturers. Therefore we offer two slightly different editions of AIRLink - the most advanced drone avionics: **Enterprise** and **Core**. **AIRLink Enterprise** is ideal for a quick start, evaluation and prototyping while **Core** is optimised for deep integration and mid-high volume manufacturing.&#x20;

<table><thead><tr><th width="150">Parameter</th><th width="150">AIRLink Enterprise</th><th>AIRLink Core</th></tr></thead><tbody><tr><td>Enclosure</td><td>Aluminum, with integrated heatsink and fan mounting option.</td><td>External heatsink or reasonable power dissipation should be provided by the design.</td></tr><tr><td>Dimensions</td><td>L103 x W61 x H37 mm</td><td>L100 x W57 x H22 mm</td></tr><tr><td>Weight</td><td>198 g</td><td>89 g</td></tr><tr><td>Ambient temperature</td><td>-40°C-..+50°C</td><td>-40°C-..+50°C</td></tr><tr><td>Production volume</td><td>Low to Medium</td><td>Medium to High</td></tr></tbody></table>

### Enterprise

[SmartAP AIRLink](https://sky-drones.com/airlink)'s Enterprise edition is intended for prototyping and low to medium volume drone production. Quick and easy installation thanks to the dedicated mounting holes and integrated heatsink for power dissipation.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MbY9jhqxneTtAOOx-pI%2F-MbYH6Yl2qly5V6faPzc%2Fimage.png?alt=media\&token=487f13ef-7cad-4133-be5f-34c1ac34081b)

### Core

[SmartAP AIRLink](https://sky-drones.com/airlink)'s Core edition is intended for medium to high volume production and deep integration with customer's hardware. It weighs only 89 g and can be attached to a metal frame for optimum cooling.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MbXLnk8YyjeoxtpTs9M%2F-MbXSFUxviONxDVgn5at%2Fimage.png?alt=media\&token=0615185e-23a8-47b9-9ff8-b73a5fc040aa)

{% hint style="info" %}
Looking for CAD model? It's available [here](/avionics/airlink/cad-model).
{% endhint %}

## Hardware feature highlights

### Easy to mount

![4xM3 mounting holes](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MbXSaMXhuoPOJOEI1oP%2F-MbXUzxOSFRtzZxF2GDC%2Fimage.png?alt=media\&token=ea91daee-bb57-457b-a31b-c3fbbf149554)

### Front-facing FPV Camera&#x20;

![Front-facing FPV camera included in the set](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MbXSaMXhuoPOJOEI1oP%2F-MbXVNodCzPNSz6J9D7C%2Fimage.png?alt=media\&token=712636b1-1357-47f4-a6e7-6287d208deb3)


# Interfaces

This page describes general information and interface location of SmartAP AIRLink.

## Connectors pinout

### Left side

![Left side](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYqDej7fatrKvb-A3b2%2F-MYqFW-WLv1qeoTOsIHj%2Fairlink-left.jpg?alt=media\&token=85f52c44-2c28-43dc-bb50-75fb1ecf7884)

* Power input with voltage & current monitoring
* AI Mission Computer micro SD card
* Flight Controller micro SD card
* AI Mission Computer USB Type-C
* PPM input, SBUS output, RSSI monitor

#### POWER - JST GH SM10B-GHS-TB

<table><thead><tr><th width="150">Pin</th><th width="150">Name</th><th width="150">Voltage level</th><th>Function</th></tr></thead><tbody><tr><td>1</td><td>12V</td><td>+12V</td><td>Main power input</td></tr><tr><td>2</td><td>12V</td><td>+12V</td><td>Main power input</td></tr><tr><td>3</td><td>12V</td><td>+12V</td><td>Main power input</td></tr><tr><td>4</td><td>BAT_CURRENT</td><td>+3.3V</td><td>Battery current monitoring</td></tr><tr><td>5</td><td>BAT_VOLTAGE</td><td>+3.3V</td><td>Battery voltage monitoring</td></tr><tr><td>6</td><td>3V3</td><td>+3.3V</td><td>3.3V output</td></tr><tr><td>7</td><td>PWR_KEY</td><td>+3.3V</td><td>Power key input</td></tr><tr><td>8</td><td>GND</td><td></td><td>Ground</td></tr><tr><td>9</td><td>GND</td><td></td><td>Ground</td></tr><tr><td>10</td><td>GND</td><td></td><td>Ground</td></tr></tbody></table>

#### CPU SD card - microSD

#### CPU USB - USB Type C

#### RC Connector - JST GH SM06B-GHS-TB

<table><thead><tr><th width="150">Pin</th><th width="150">Name</th><th width="150">Voltage level</th><th>Function</th></tr></thead><tbody><tr><td>1</td><td>5V</td><td>+5V</td><td>5V output</td></tr><tr><td>2</td><td>PPM_IN</td><td>+3.3V</td><td>PPM input</td></tr><tr><td>3</td><td>RSSI_IN</td><td>+3.3V</td><td>RSSI input</td></tr><tr><td>4</td><td>FAN_OUT</td><td>+5V</td><td>Fan output</td></tr><tr><td>5</td><td>SBUS_OUT</td><td>+3.3V</td><td>SBUS output</td></tr><tr><td>6</td><td>GND</td><td></td><td>Ground</td></tr></tbody></table>

#### FMU SD card - microSD

### Right side

![Right side](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYqDej7fatrKvb-A3b2%2F-MYqFjJRFveEjZ8z8-2N%2Fairlink-right.jpg?alt=media\&token=a648ae0d-7add-45cb-8a35-29e49399ae65)

* Ethernet port with power output
* Telemetry port
* Second GPS port
* Spare I2C / UART port
* Flight controller USB Type-C
* Micro SIM Card
* HDMI input port (payload camera)

#### ETHERNET - JST GH SM08B-GHS-TB

<table><thead><tr><th width="150">Pin</th><th width="150">Name</th><th width="150">Voltage level</th><th>Function</th></tr></thead><tbody><tr><td>1</td><td>5V</td><td>+5V</td><td>Radio module power supply</td></tr><tr><td>2</td><td>5V</td><td>+5V</td><td>Radio module power supply</td></tr><tr><td>3</td><td>ETH_TXP</td><td>+3.3V</td><td>Ethernet transmit positive</td></tr><tr><td>4</td><td>ETH_TXN</td><td>+3.3V</td><td>Ethernet transmit negative</td></tr><tr><td>5</td><td>ETH_RXP</td><td>+3.3V</td><td>Ethernet receive positive</td></tr><tr><td>6</td><td>ETH_RXN</td><td>+3.3V</td><td>Ethernet receive negative</td></tr><tr><td>7</td><td>GND</td><td></td><td>Ground</td></tr><tr><td>8</td><td>GND</td><td></td><td>Ground</td></tr></tbody></table>

{% hint style="info" %}
Ethernet interface is decoupled with capacitors. Ethernet cable should be twisted to reduce EMI noise. Shorter cables are recommended for increased performance and higher bandwidth of the interface.
{% endhint %}

#### TEL3 - JST GH SM06B-GHS-TB

<table><thead><tr><th width="150">Pin</th><th width="150">Name</th><th width="150">Voltage level</th><th>Function</th></tr></thead><tbody><tr><td>1</td><td>5V</td><td>+5V</td><td>Power supply output</td></tr><tr><td>2</td><td>USART2_TX</td><td>+3.3V</td><td>Telemetry 3 TX</td></tr><tr><td>3</td><td>USART2_RX</td><td>+3.3V</td><td>Telemetry 3 RX</td></tr><tr><td>4</td><td>USART2_CTS</td><td>+3.3V</td><td>Telemetry 3 CTS</td></tr><tr><td>5</td><td>USART2_RTS</td><td>+3.3V</td><td>Telemetry 3 RTS</td></tr><tr><td>6</td><td>GND</td><td></td><td>Ground</td></tr></tbody></table>

#### I2C3 / UART4 - JST GH SM06B-GHS-TB

<table><thead><tr><th width="150">Pin</th><th width="150">Name</th><th width="150">Voltage level</th><th>Function</th></tr></thead><tbody><tr><td>1</td><td>5V</td><td>+5V</td><td>Power supply output</td></tr><tr><td>2</td><td>USART4_TX</td><td>+3.3V</td><td>UART 4 TX</td></tr><tr><td>3</td><td>USART4_RX</td><td>+3.3V</td><td>UART 4 RX</td></tr><tr><td>4</td><td>I2C3_SCL</td><td>+3.3V</td><td>I2C3 Clock</td></tr><tr><td>5</td><td>I2C3_SDA</td><td>+3.3V</td><td>I2C3 Data</td></tr><tr><td>6</td><td>GND</td><td></td><td>Ground</td></tr></tbody></table>

#### GPS2 - JST GH SM06B-GHS-TB

<table><thead><tr><th width="150">Pin</th><th width="150">Name</th><th width="150">Voltage level</th><th>Function</th></tr></thead><tbody><tr><td>1</td><td>5V</td><td>+5V</td><td>Power supply output</td></tr><tr><td>2</td><td>USART8_TX</td><td>+3.3V</td><td>UART 8 TX GPS2</td></tr><tr><td>3</td><td>USART8_RX</td><td>+3.3V</td><td>UART 8 RX GPS2</td></tr><tr><td>4</td><td>I2C2_SCL</td><td>+3.3V</td><td>I2C2 Clock</td></tr><tr><td>5</td><td>I2C2_SDA</td><td>+3.3V</td><td>I2C2 Data</td></tr><tr><td>6</td><td>GND</td><td></td><td>Ground</td></tr></tbody></table>

{% hint style="info" %}
AIRLink has integrated 1.5KΩ pull-up resistors for all I2C lines. No external pull-up resistors required.&#x20;
{% endhint %}

#### FMU USB - USB Type C

#### SIM Card - micro SIM

#### HDMI - mini HDMI

### Front side

![Front side](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYqDej7fatrKvb-A3b2%2F-MYqGKNnAYTS7yJWVgux%2Fairlink-front.jpg?alt=media\&token=291194ec-8dd5-4b67-904e-6441b431368c)

* Main GNSS and compass port
* Main telemetry port
* CSI camera input
* CAN 1
* CAN 2

#### TEL1 - JST GH SM06B-GHS-TB

<table><thead><tr><th width="150">Pin</th><th width="150">Name</th><th width="150">Voltage level</th><th>Function</th></tr></thead><tbody><tr><td>1</td><td>5V</td><td>+5V</td><td>Power supply output</td></tr><tr><td>2</td><td>USART7_TX</td><td>+3.3V</td><td>Telemetry 1 TX</td></tr><tr><td>3</td><td>USART7_RX</td><td>+3.3V</td><td>Telemetry 1 RX</td></tr><tr><td>4</td><td>USART7_CTS</td><td>+3.3V</td><td>Telemetry 1 CTS</td></tr><tr><td>5</td><td>USART7_RTS</td><td>+3.3V</td><td>Telemetry 1 RTS</td></tr><tr><td>6</td><td>GND</td><td></td><td>Ground</td></tr></tbody></table>

#### GPS1 - JST GH SM10B-GHS-TB

<table><thead><tr><th width="150">Pin</th><th width="150">Name</th><th width="150">Voltage level</th><th>Function</th></tr></thead><tbody><tr><td>1</td><td>5V</td><td>+5V</td><td>Power supply output</td></tr><tr><td>2</td><td>USART1_TX</td><td>+3.3V</td><td>GPS 1 TX</td></tr><tr><td>3</td><td>USART1_RX</td><td>+3.3V</td><td>GPS 1 RX</td></tr><tr><td>4</td><td>I2C1_SCL</td><td>+3.3V</td><td>MAG 1 Clock</td></tr><tr><td>5</td><td>I2C1_SDA</td><td>+3.3V</td><td>MAG 1 Data</td></tr><tr><td>6</td><td>SAFETY_BTN</td><td>+3.3V</td><td>Safety button</td></tr><tr><td>7</td><td>SAFETY_LED</td><td>+3.3V</td><td>Safety LED</td></tr><tr><td>8</td><td>+3V3</td><td>+3.3V</td><td>3.3V output</td></tr><tr><td>9</td><td>BUZZER</td><td>+5V</td><td>Buzzer output</td></tr><tr><td>10</td><td>GND</td><td></td><td>Ground</td></tr></tbody></table>

#### CAN1 - JST GH SM04B-GHS-TB

<table><thead><tr><th width="150">Pin</th><th width="150">Name</th><th width="150">Voltage level</th><th>Function</th></tr></thead><tbody><tr><td>1</td><td>5V</td><td>+5V</td><td>Power supply output</td></tr><tr><td>2</td><td>CAN1_H</td><td>+5V</td><td>CAN 1 High (120Ω)</td></tr><tr><td>3</td><td>CAN1_L</td><td>+5V</td><td>CAN 1 Low (120Ω)</td></tr><tr><td>4</td><td>GND</td><td></td><td>Ground</td></tr></tbody></table>

#### CAN2 - JST GH SM04B-GHS-TB

<table><thead><tr><th width="150">Pin</th><th width="150">Name</th><th width="150">Voltage level</th><th>Function</th></tr></thead><tbody><tr><td>1</td><td>5V</td><td>+5V</td><td>Power supply output</td></tr><tr><td>2</td><td>CAN2_H</td><td>+5V</td><td>CAN 2 High (120Ω)</td></tr><tr><td>3</td><td>CAN2_L</td><td>+5V</td><td>CAN 2 Low (120Ω)</td></tr><tr><td>4</td><td>GND</td><td></td><td>Ground</td></tr></tbody></table>

{% hint style="info" %}
AIRLink has integrated 120Ω CAN bus termination resistor. To comply with ISO 11898 user the second 120Ω resistor at the other end of the bus.
{% endhint %}

#### CAMERA - FPC 30 pin, 0.5mm pitch

### Rear side

{% tabs %}
{% tab title="4G / LTE Edition" %}

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FyZdl0h2ammFpMBsFKBYm%2Fimage.png?alt=media&amp;token=ed62327f-83fd-498f-8f31-78af2ef80ec0" alt=""><figcaption></figcaption></figure>
{% endtab %}

{% tab title="5G Edition" %}

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FENlFahZzuEiuCuapBGhc%2F5g.jpg?alt=media&amp;token=858b9768-b908-41c6-93fb-0bd86bd13f83" alt=""><figcaption></figcaption></figure>
{% endtab %}
{% endtabs %}

* SBUS input
* 16 PWM output channels
* 2x LTE antenna sockets in 4G, 4x LTE antenna sockets in 5G  &#x20;
* WiFi antenna socket (AP & Station modes)

## Serial ports mapping

SmartAP AIRLink has a large number of serial ports with the following pinout:

<table><thead><tr><th width="150">UART Port</th><th width="150">Path</th><th>Description</th></tr></thead><tbody><tr><td>UART1</td><td>/dev/ttyS0</td><td>GPS 1</td></tr><tr><td>UART2</td><td>/dev/ttyS1</td><td>Telemetry 3</td></tr><tr><td>UART3</td><td>/dev/ttyS2</td><td>Debug console (internal connector)</td></tr><tr><td>UART4</td><td>/dev/ttyS3</td><td>Telemetry 4</td></tr><tr><td>UART5</td><td>/dev/ttyS4</td><td>Telemetry 2 (used internally with Mission Computer)</td></tr><tr><td>UART6</td><td>/dev/ttyS5</td><td>PWM IO Module (used internally)</td></tr><tr><td>UART7</td><td>/dev/ttyS6</td><td>Telemetry 1</td></tr><tr><td>UART8</td><td>/dev/ttyS7</td><td>GPS 2</td></tr></tbody></table>

{% hint style="info" %}
Looking for CAD files? Here they are:
{% endhint %}

{% content-ref url="/pages/-MYKLv4jimCoiD2J-6WM" %}
[CAD Model](/avionics/airlink/cad-model)
{% endcontent-ref %}

{% hint style="info" %}
Want to see the detailed full specifications? Here is the PDF datasheet:&#x20;
{% endhint %}

{% file src="/files/vkYimy7c8trUd7QF1ohq" %}
SmartAP AIRLink Datasheet
{% endfile %}


# Set content

Everything you need to setup and start using SmartAP AIRLink

## Unboxing Video

{% embed url="<https://www.youtube.com/watch?v=lex7axW8WQg>" %}
SmartAP AIRLink unboxing video
{% endembed %}

## AIRLink Set content

![SmarAP AIRLink set](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MbXgkwCxhNq8pwVOvqx%2F-MbXjWzQjhtweuH2T7Zt%2Fimage.png?alt=media\&token=951b019c-f7f0-464a-9de6-af23943d7067)

SmartAP AIRLink set includes everything needed to setup the system and get prepared for the flight. Standard set contains:

* 1x AIRLink Enterprise unit
* 1x FPV camera with CSI cable
* 1x WiFi antenna with MMCX connector
* 2x LTE antenna with MMCX connector
* 1x HDMI to mini HDMI cable
* 1x set of cables (7 cables for all connectors)

## AIRLink Telemetry set content

AIRLink Telemetry provides broadband AES-256 encrypted private channel for 20km. If LTE connectivity is sufficient for your applications then you don't need AIRLink Telemetry set. &#x20;

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2F7Opo7tUpolujgGqt4iL9%2F1.jpg?alt=media&amp;token=6c9f66e7-aa5d-469d-93c7-e190dddf613f" alt=""><figcaption></figcaption></figure>

* 1x Ground module
* 1x Air module
* 2x Ground module antennas&#x20;
* 2x Air module antennas
* 1x Telemetry cable
* 1x Ground module power cable


# Installation

Let's install and setup SmartAP AIRLink

## Minimum Installation Setup

### 1. Connect WiFi and LTE antennas

Take SmartAP AIRLink Enterprise and connect WiFi and LTE antennas.

![SmartAP AIRLink with antennas from the set](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYqLE8j2-Xkn358PJMn%2F-MYqQLNumUfzDNfQ0Qcx%2F1.jpg?alt=media\&token=23aca0c8-f379-4f4c-bd56-6b73dad3c037)

{% hint style="danger" %}
**WARNING**: DO NOT power the AIRLink without antennas! Powering up the system without antennas may cause malfunction of the radio modules and permanent damage. Powering up without antennas voids warranty.
{% endhint %}

Connect the WiFi antenna to the WiFi socket (middle) by gently pushing on the antenna connector:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYqLE8j2-Xkn358PJMn%2F-MYqR0rv3LVyvqi4n3PM%2F2.jpg?alt=media\&token=a42d36ea-c737-44b2-a62d-3b39d6b3d32a)

AIRLink with WiFi antenna connected:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYqLE8j2-Xkn358PJMn%2F-MYqRi_yZRkzcAth2SwC%2F3.jpg?alt=media\&token=fd6da87c-7ea9-4aae-b831-6449bb406de5)

Connect LTE antennas to LTE1 and LTE2 sockets (sides):

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYqLE8j2-Xkn358PJMn%2F-MYqSZ2ERrW_x6CjZxwc%2F4.jpg?alt=media\&token=3f30ea1f-6085-4d40-94ac-7215ecf1ef27)

{% hint style="warning" %}
If it is not necessary, do not remove the antennas from the connector. The connectors are quite fragile and are rated for only a limited number of matching cycles. Bad connection can result in reduced RF communication performance.&#x20;
{% endhint %}

AIRLink 5G Edition has 5 antennas on the rear side - 1x WiFi and 4x 5G. It's recommended to connect all 4 antennas to achieve the highest possible throughput:

&#x20;         &#x20;

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2Ft7W83u4OFCvfHj3mtp31%2FIMG_0667.JPG?alt=media&amp;token=8e0db27f-830b-4850-9e17-75c470da4d4f" alt=""><figcaption></figcaption></figure>

{% hint style="info" %}
If you have 4G LTE version of AIRLink with 5 antenna sockets then use only two leftmost LTE1 and LTE2 ports for LTE antennas.     &#x20;
{% endhint %}

### 2. Connect FPV camera

Camera connection is not necessary but recommended. This will allow you to test your setup and video streaming after the initial software setup described in the following sections.&#x20;

First of all, take something sharp and unlock the CSI camera port connector by pulling it a bit at each side:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYqLE8j2-Xkn358PJMn%2F-MYqWhXBJ7cV493hjaDQ%2Fimage.png?alt=media\&token=0bd36008-d0d6-4111-aff8-655bed9499ff)

Then insert the FPC cable from the camera and gently push back the black part of the connector mechanism until it locks itself tightly:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYqLE8j2-Xkn358PJMn%2F-MYqXvwvVj5IPDCChAr6%2Fimage.png?alt=media\&token=1dd67319-81fe-490a-9a60-ce327fdf21b1)

Repeat the same procedure with the camera socket. Once done you should have the camera connected to AIRLink.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYqLE8j2-Xkn358PJMn%2F-MYqVXtZIrH8ITSKeBbA%2Fimage.png?alt=media\&token=ff38e167-75bb-44ae-a9dc-ed936be4684c)

### 3. Connect power supply

Take the main power supply cable and connect this to the power source.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYusP4orN426ANESksj%2F-MYusV0xl0Lj1AGeSXoO%2F8.jpg?alt=media\&token=f0596b19-45a4-46ea-8136-601db6cd8aeb)

{% hint style="info" %}
We recommend to use [SmartAP PDB](/avionics/legacy-autopilots/pro) for the power distribution. It has a current sensor and DC-DC converters for 5V and 12V to power [SmartAP AIRLink](https://sky-drones.com/airlink) and other peripherals.&#x20;
{% endhint %}

* Connect power cable to 12V output of [SmartAP PDB](/avionics/smartap-pdb).
* Connect power monitor cable (voltage and current) to the dedicated pins on [SmartAP PDB](/avionics/smartap-pdb).&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FUEWcQtMym3IEWhi5J8A0%2FIMG_6952.jpg?alt=media\&token=5a088b58-054a-4d50-ad4e-d1ed0322be39)

{% hint style="danger" %}
**DANGER:** Make sure to connect the cable with the right polarity. Reversing polarity may damage the equipment permanently and will void warranty.&#x20;

The recommended power supply voltage is 12V. The acceptable input voltage limits are 10V - 20V.
{% endhint %}

Next, connect the power cable to [AIRLink](https://sky-drones.com/airlink) as shown on the image below:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FUFaLJpJRMjyqxy42SUHA%2FIMG_6953.jpg?alt=media\&token=c8a03159-0dd0-4177-a04c-4667c9b31ac5)

{% hint style="info" %}
Minimum installation setup is complete. If you would like to test the system you can refer to the next section and power it up for the initial configuration. If you would like to connect the other peripherals, please refer to the Full Installation Setup below.&#x20;
{% endhint %}

Proceed to the initial power up or set up the other peripherals.

{% hint style="warning" %}
It's recommended to start with the Minimum Installation Setup for the very first power up.
{% endhint %}

{% content-ref url="/pages/-MYw-9kBRhJROv0Pb\_U3" %}
[Initial Power Up](/avionics/airlink/initial-power-up)
{% endcontent-ref %}

## Full installation setup

### 1. Connect GNSS Receiver

Take SmartAP GNSS Module with GNSS cable:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MbXsFEBDObgB4CA6ZGR%2F-MbXw1m8Pg100qIlH9WL%2Fimage.png?alt=media\&token=0b5d6028-bb73-45fa-b406-63b7362459ce)

Connect it to the **GPS 1** port on the front side of AIRLink:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlD4fLliNi3ndmNpEC%2F-MdlDEpp2AmzyJ5LwSVw%2FIMG_3115.jpg?alt=media\&token=bbb7e158-dcc6-411a-b2f3-4a3d8cb10c86)

Assembled component will look as follows:

![SmartAP AIRLink with SmartAP GNSS](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlD4fLliNi3ndmNpEC%2F-MdlDhaATh6wxSg5ovPP%2FIMG_3116.jpg?alt=media\&token=0c64bdf5-321d-48ef-bd1c-9239f6366c71)

### 2. Connect RC Receiver

Install RC receiver and connect it to the SBUS port of AIRLink on the rear side:&#x20;

![RC Receiver output goes to SBUS port of SmartAP AIRLink](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MbXsFEBDObgB4CA6ZGR%2F-MbXvdYbcsso07BxSoDr%2FIMG_2398.jpg?alt=media\&token=bc98b1d2-f536-4570-9312-30c26807ecb4)

Fully assembled component will look as follows:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlD4fLliNi3ndmNpEC%2F-MdlF1O9XFpStqx1KwnI%2FIMG_3128.jpg?alt=media\&token=23beb285-7199-401e-aeba-ed0c1a8bb6cd)

{% hint style="info" %}
If you're using any other than SBUS type of the receiver, please refer to the [Interfaces](/avionics/airlink/interfaces#left-side) section for more info.&#x20;
{% endhint %}

### 3. Connect Telemetry Radio Module

Connect AIRLink telemetry module to **Ethernet** port of SmartAP AIRLink as shown on the image below:

![SmartAP AIRLink with Telemetry air module](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdO6g43JAme6t44Pamr%2F-MdOJe_ECBbqpwx_1lCU%2FIMG_2918.jpg?alt=media\&token=47d429be-4b35-4761-9879-ab279bffc95c)

Please refer to the dedicated page for more detailed instructions regarding Air module connection:

{% content-ref url="/pages/-MdODIiFhR6u4Qn8n-cQ" %}
[Installation](/avionics/airlink-telemetry/installation)
{% endcontent-ref %}

### 4. Connect HDMI Payload Camera&#x20;

Take HDMI cable, HDMI-in capable video camera and SmartAP AIRLink.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlD4fLliNi3ndmNpEC%2F-MdlG2xOD04HfUT-joUu%2FIMG_3117.jpg?alt=media\&token=835bcb95-d36e-409c-91c2-ff9e8e8b251e)

Connect HDMI cable to AIRLink input port:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlD4fLliNi3ndmNpEC%2F-MdlGW7rmHBjKsQpK1oB%2FIMG_3118.jpg?alt=media\&token=3c603ef7-4a6c-4cf6-be96-75ce3455d0b7)

Fully assembled component will look as follows:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlD4fLliNi3ndmNpEC%2F-MdlHPA7bY6kcuMao1HZ%2FIMG_3120.jpg?alt=media\&token=65c7176f-a184-47a8-985d-4bde47d56f88)

### 5. Insert microSD card

Insert microSD card into FMU SD slot. This SD card is needed for flight logging.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlD4fLliNi3ndmNpEC%2F-MdlIep71mOv2Mt0ybgf%2FIMG_3124.jpg?alt=media\&token=0e237c3d-aaaf-4ce1-86ec-5058ec0425eb)

Inserted microSD card will looks as follows:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlD4fLliNi3ndmNpEC%2F-MdlJufPT5_o0TcIdCYC%2FIMG_3126.jpg?alt=media\&token=a70ec5a6-5887-4eaa-942c-496f1dc06dc1)

### 6. Insert SIM Card

Insert SIM Card into **SIM Card** slot as shown on the image below:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlD4fLliNi3ndmNpEC%2F-MdlLEKSWq8A8GYgFjrI%2FIMG_3121.jpg?alt=media\&token=ec4c03ca-a09c-4acd-a308-b4aab34b09c0)

Inserted SIM Card will looks as follows:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlD4fLliNi3ndmNpEC%2F-MdlLC348L15_W48gL6k%2FIMG_3123.jpg?alt=media\&token=4a6e537b-53a8-4020-9db1-76d504a28aa8)


# Initial Power Up

Powering up SmartAP AIRLink for the first time after wiring the peripherals

{% hint style="warning" %}
Make sure you have completed all [Installation](/avionics/airlink/installation) steps and connected antennas before proceeding with the power up.
{% endhint %}

### 1. Power up the AIRLink

You will see that various LEDs will turn on and some of them will start blinking. This means that the AIRLink is live and booting up. In particular, make sure that the PWR green LED is solid. This means that the AIRLink is powered up and running properly.

![PWR green LED is solid meaning that the unit is powered up properly](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYvxMXTyqbm4qX5XEDg%2F-MYw17HXPdsrYG5LzYH3%2F11.jpg?alt=media\&token=6ce5d51d-b2a8-4508-9ef0-674dc16402f4)

### 2. Connect to AIRLink WiFi

Check available WiFi networks on your computer or tablet and connect to AIRLink network to set up the initial WiFi connection of the AIRLink. Find **AirLinkConfig\_XXXXX** network and connect to i&#x74;**:**

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlLJNpSSQNQzGSnIKr%2F-Mdlba7nNasavKDkzciK%2FUntitled-1.jpg?alt=media\&token=519493da-2766-4cd0-8aeb-d4b0619a9dbc)

{% hint style="info" %}
The name of the network is unique for each AIRLink and starts with **AirLinkConfig\_** and ends with a collection of unrelated symbols.
{% endhint %}

Default password: **airlink1**

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlLJNpSSQNQzGSnIKr%2F-MdlbzMbH7vSabLSXISq%2FUntitled-2.jpg?alt=media\&token=3f5d16fb-f3d7-4141-b41f-b73f8374662b)

### 3. Open web browser

Once you're connected to the AIRLink network, open the web browser and proceed with the initial configuration. Click the following link to open [AIRLink Configuration Page](http://airlink.local/).

{% hint style="info" %}
In case the link above doesn't work - then go to [airlink.local/](http://airlink.local/). In case [airlink.local/](http://airlink.local/) doesn't work either - then go to [10.42.0.1](http://10.42.0.1/). In some cases you might need to manually type this into browser address network. This is browser-dependent, we recommend to use Google Chrome or Safari. &#x20;
{% endhint %}

You will see the following welcome page:

![SmartAP AIRLink Dashboard](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlLJNpSSQNQzGSnIKr%2F-Mdleho8FMaeQVKgEF-2%2F1.jpg?alt=media\&token=dc07a2d2-b553-47bc-91af-98b549d07fb6)

This page displays the generic information about the system including its status, system ID and current software version. You can see the current WiFi network status by clicking **WiFi Settings:**

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlLJNpSSQNQzGSnIKr%2F-Mdley3NtLc0Tl7mXXV5%2F2.jpg?alt=media\&token=fea4ee14-393b-4aaa-bd89-2672e4d31488)

By default, AIRLink is configured as the access point. If you would like to connect AIRLink to your home or office WiFi network then click the **Connect to another WiFi network** button.&#x20;

### 4. Connect to WiFi

You will see the discovered WiFi networks list:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlLJNpSSQNQzGSnIKr%2F-MdlfANigeagB-_qzy3w%2F3.jpg?alt=media\&token=15ea402b-5c82-4c3e-9583-98490c60309f)

Select the network you would like to connect to and click on its name. You will be asked to enter the WiFi network password:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlLJNpSSQNQzGSnIKr%2F-MdlfI0OLd7wfFUNkj87%2F4.jpg?alt=media\&token=dfe2bad9-b10c-4b9c-bc3e-eadaa442bb96)

After you have typed the password please click **Connect**.

{% hint style="info" %}
After pressing the button, AIRLink will attempt to connect. This may take a few minutes. AirLinkConfig network will be disabled and most likely your computer will connect to the other known network. However, if you entered the wrong password or the access point rejects the connection for other reasons, turn on the AirLinkConfig access point again. Your computer is unlikely to automatically connect to it and you may have to do this manually.

After pressing the button, the device will be expected to appear at the address [airlink.local/](http://airlink.local/), if it is supported by your router / computer, and will automatically redirect there.
{% endhint %}

Connect your computer to the same WiFi network which you have just connected the AIRLink to and go to [airlink.local/](http://airlink.local/). If you are able to see the main dashboard - you have successfully connected AIRLink to WiFi network:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlLJNpSSQNQzGSnIKr%2F-MdljVmV48_ribC_5FVq%2Fimage.png?alt=media\&token=1d0d9df4-1263-4059-bc91-78a417f7a891)

{% hint style="info" %}
If you have troubles accessing AIRLink dashboard - please view [this guide](/avionics/airlink/troubleshooting#unable-to-access-airlink-local).
{% endhint %}

{% hint style="success" %}
**CONGRATULATIONS! Now your AIRLink is connected to Internet.**
{% endhint %}

### 5. Claim AIRLink ownership

By default, your AIRLink is owned by the manufacturer (Sky-Drones) or other licensed manufacturer. You can claim ownership of the AIRLink and assign it to your account.&#x20;

{% hint style="info" %}
AIRLink ownership is required to use Sky-Drones Cloud services. Therefore, we highly recommend to claim your AIRLink ownership at this step.  Make sure you have the following:

* Sky-Drones Cloud account. If not - create [here](https://cloud.sky-drones.com).
* AIRLink is connected to WiFi and has internet access.
  {% endhint %}

Go to the AIRLink dashboard at [airlink.local/](http://airlink.local/) and scroll down until you see **Ownership Transfer** section, click **Claim Ownership:**

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdljucxuMh-mYZLn9x8%2F-MdmITuRAoLpkMz7u-dM%2F7.jpg?alt=media\&token=e06e9d51-fe4c-4058-8f46-af62d228c5ab)

Enter your Sky-Drones Cloud email and password to authenticate. Click Authenticate:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdljucxuMh-mYZLn9x8%2F-MdmIbv49MsJwCe0foll%2F8.jpg?alt=media\&token=44418fb2-070c-4033-a3fa-bb607ae85f79)

If the authentication was successful you will see the following message confirming that your identity was successfully verified.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdljucxuMh-mYZLn9x8%2F-MdmIldjho1-ojhbDlHZ%2F9.jpg?alt=media\&token=d65e970a-3859-4ce9-a3ea-f44d71c00478)

{% hint style="info" %}
If you have any troubles at this step - make sure you have your [Sky-Drones Cloud](https://cloud.sky-drones.com) and your email and password are correct.
{% endhint %}

Click **Claim Ownership of this AIRLink.** If successful – you should see the following confirmation message:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdljucxuMh-mYZLn9x8%2F-MdmIttmZvCXSdzALi9f%2F10.jpg?alt=media\&token=3a7cc7ed-2696-4c37-909a-38666d797c37)

You can click the button to return to the main dashboard.&#x20;

{% hint style="success" %}
**CONGRATULATIONS!** Your AIRLink has been successfully set up and now you can proceed to its configuration for your vehicle. We recommend to use SmartAP GCS for the initial vehicle configuration setup. Later you can use Sky-Drones Cloud web services for real time flight monitoring and control. Your AIRLink is already available in your **Sky-Drones Cloud** account.
{% endhint %}


# Connect via SmartAP GCS

### 1. Open SmartAP GCS app

Open [SmartAP GCS](https://sky-drones.com/smartap-gcs) application and set up the new connection.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYw652GlmjTsTZl0N86%2F-MYwBYmoZHRpCzyQHHQa%2F21.jpg?alt=media\&token=861db3d2-941e-4efc-b887-1e1cbc0d221e)

### 2. Add new connection

Click the WiFi icon in the top right corner to set up the new connection. You should enter the same IP address as you discovered in the previous steps during the initial power up. The port name is **14555.** Click **open**.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYw652GlmjTsTZl0N86%2F-MYwB3R3tXFicIGetXRq%2Fimage.png?alt=media\&token=eea9a261-ee51-40e8-bdca-de40a1fdf4bb)

You should see the telemetry updates and hear the voice notification that indicated the connection was successfully established.&#x20;

### 3. Open autopilot configuration settings

Click on the Gear icon on the top toolbar to open the settings for the autopilot configuration.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYw652GlmjTsTZl0N86%2F-MYwCYLvNg0TRylLP7Oz%2F22.jpg?alt=media\&token=bfc3af11-1462-49f5-b67d-24a6f4dc86a0)

Please refer to your specific drone configuration steps for more detailed information.&#x20;

### 4. Set up video streaming

Click on the Gear icon in the bottom left corner and set up the video source. Select **RTSP** video source and type the RTSP address. In our case, this is **rtsp\://192.168.1.157:8554/camera/0**

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYw652GlmjTsTZl0N86%2F-MYwD5SbVKwGq845hecQ%2Fimage.png?alt=media\&token=0be2b788-9f6c-448f-b2dd-0216cfd60552)

Click **Start** and then you should be able to see the real time video feed:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MYw652GlmjTsTZl0N86%2F-MYwFa6BoXm_8PrF2FOF%2F24.jpg?alt=media\&token=fe1578fb-d79b-4299-b418-dd042c8812b6)


# Software development

Learn more about developing the software with AIRLink and running your own custom apps.

The Sky-Drones Platform helps to integrate drones in custom end-to-end workflows with lots of enhanced features for advancing our enterprise customers:

* Real-time digital HD video streaming
* Real-time payload data processing (e.g. computer vision)
* Real-time flight control (e.g. target tracking, collision prevention, and obstacle avoidance)
* In-flight telemetry and payload data streaming directly to customer’s cloud
* Drone-to-drone communications
* Running custom apps directly on the drone (edge computing)
* Safely performing autonomous BVLOS missions with real-time control

You have all the necessary infrastructure to develop your own drone software as well as use advanced software from Sky-Drones partners.

## Accessing AIRLink Mission Computer with SSH

Open Terminal and access AIRLink Mission Computer with SSH using the following command:

```bash
ssh smartap@airlink.local
```

You will be asked for the password, the default credentials are:

* Login: **smartap**
* Password: **smartap**

If you log in successfully you will see the following welcome page:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdmL5f7YAdsqQAtmmL8%2F-MdmM9BjtQI2Hy9_c2Gn%2F11.jpg?alt=media\&token=de213895-908e-4d33-8b0d-4d0d817a6819)

{% hint style="info" %}
If you are connected to AIRLink using WiFi Access Point mode and your computer doesn't support local DNS, you would need to use IP address **10.42.0.1** instead of **airlink.local.**
{% endhint %}

That's all you need for the development and we assume now you know what to do :)

#### Root access

{% hint style="info" %}
SSH root access is not available as standard for security and safety reasons. However, this can be provided by Sky-Drones upon request. Please [contact us](https://sky-drones.com/contact-us) to get an access.&#x20;
{% endhint %}

## Read / Write MAVLink Telemetry data

SmartAP AIRLink provides user access for MAVLink telemetry stream which is useful for 3rd party applications development where you need to have access to the data from / to Autopilot and to / from Ground Control Station.&#x20;

AIRLink supports 3 ports for user applications: 2 absolutely independent UDP ports and 1 TCP port for third party apps access:

| # | Type | Host      | Port  | Protocol |
| - | ---- | --------- | ----- | -------- |
| 1 | UDP  | 127.0.0.1 | 14560 | MAVLink  |
| 2 | UDP  | 127.0.0.1 | 14561 | MAVLink  |
| 3 | TCP  | 127.0.0.1 | 14556 | MAVLink  |

For developer's convenience we offer code samples for reading and writing MAVLink messages. This example displays how to read HEARTBEAT message from the other MAVLink nodes and send HEARTBEAT from our example.

### UDP Example

Read / write MAVLink using UDP connection:

```python
#!/usr/bin/python3
# Usage example of MAVLink UDP port for user applications
# To execute:
#     python3 heartbeat_example_udp.py
# or
#     python3 heartbeat_example.py 127.0.0.1:14560 35
#     in this case: 127.0.0.1:14560 - address and port of mavlink source,
#                                     now available 14560 and 14561 udp ports 
#                                     for user applications
#                   35 - system-id for signature
#

import pymavlink.mavutil as mavutil
from pymavlink.dialects.v20 import common as mavlink
import sys
import time
from threading import Thread


if len(sys.argv) != 3:
    # use default arguments if no arguments given from command line
    srcSystem = mavlink.MAV_COMP_ID_USER1
    remote_address = "127.0.0.1:14560"
else:
    # use arguments from command line
    srcSystem = int(sys.argv[2])
    remote_address = sys.argv[1]

# create connection
mav = mavutil.mavlink_connection(
    'udpout:' + remote_address, source_system=srcSystem)


def sender_loop():
    while True:
        mav.mav.heartbeat_send(mavlink.MAV_TYPE_GENERIC,
                               mavlink.MAV_AUTOPILOT_INVALID,
                               mavlink.MAV_MODE_FLAG_CUSTOM_MODE_ENABLED,
                               0,
                               mavlink.MAV_STATE_STANDBY)
        time.sleep(2)


send_thread = Thread(target=sender_loop)
send_thread.daemon = True
send_thread.start()

while True:
    msg = mav.recv_match(blocking=True)
    if msg.get_type() == 'HEARTBEAT':
        print("HEARTBEAT from %d: %s" % (msg.get_srcSystem(), msg))


```

Run this example with:&#x20;

```python
python3 heartbeat_example_udp.py
```

### TCP Example

Read / write MAVLink using TCP connection:

```python
#!/usr/bin/python3
# Usage example of MAVLink TCP port for user applications
# To execute:
#     python3 heartbeat_example_tcp.py
# or
#     python3 heartbeat_example.py 127.0.0.1:14556 35
#     in this case: 127.0.0.1:14560 - address and port of mavlink source,
#                                     now available 14556 tcp port
#                   35 - system-id for signature
#

import pymavlink.mavutil as mavutil
from pymavlink.dialects.v20 import common as mavlink
import sys
import time
from threading import Thread


if len(sys.argv) != 3:
    srcSystem = mavlink.MAV_COMP_ID_USER2
    remote_address = "127.0.0.1:14556"
else:
    srcSystem = int(sys.argv[2])
    remote_address = sys.argv[1]

mav = mavutil.mavlink_connection(
    'tcp:' + remote_address, source_system=srcSystem)


def sender_loop():
    while True:
        mav.mav.heartbeat_send(mavlink.MAV_TYPE_GENERIC,
                               mavlink.MAV_AUTOPILOT_INVALID,
                               mavlink.MAV_MODE_FLAG_CUSTOM_MODE_ENABLED,
                               0,
                               mavlink.MAV_STATE_STANDBY)
        time.sleep(2)


send_thread = Thread(target=sender_loop)
send_thread.daemon = True
send_thread.start()

while True:
    msg = mav.recv_match(blocking=True)
    if msg.get_type() == 'HEARTBEAT':
        print("HEARTBEAT from %d: %s" % (msg.get_srcSystem(), msg))


```

### Run the example

Run the example with the following commands:&#x20;

```bash
# Login via SSH
ssh smartap@airlink.local

# Make sure that you have the example 
# file in your home directory and run it with
python3 heartbeat_example_udp.py
```

Once you run the example above you should expect the following output. This is the Heartbeat message coming from the Flight Controller:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-Mhwn8HFFoMhP8y-aQq-%2F-Mhwouet-hQb0udYJmXu%2Fimage.png?alt=media\&token=9899b8d8-14e6-405c-9ff9-111fdc3a694f)

If you connect with the Ground Control Station software you will also see the heartbeat coming from the GCS:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-Mhwn8HFFoMhP8y-aQq-%2F-MhwpE8dWCKvhmG3_Tba%2Fimage.png?alt=media\&token=88d591e9-a188-4b1c-80f5-5c6acbe0cbc0)

Feel free to use these code samples for your custom apps development using SmartAP AIRLink and MAVLink communication protocol.&#x20;

## Get Video feed

AIRLink provides video feed access via RTSP either locally (127.0.0.1) or remotely (airlink.local). Currently, we support integrated CSI camera and HDMI input as well as [NextVision](https://www.nextvision-sys.com/) cameras over Ethernet:&#x20;

| # | Video feed        | Type | Host                       | Port | Address                             |
| - | ----------------- | ---- | -------------------------- | ---- | ----------------------------------- |
| 1 | CSI Camera        | RTSP | 127.0.0.1 or airlink.local | 8554 | rtsp\://airlink.local:8554/camera/0 |
| 2 | HDMI Input        | RTSP | 127.0.0.1 or airlink.local | 8554 | rtsp\://airlink.local:8554/camera/1 |
| 3 | NextVision Camera | RTSP | 127.0.0.1 or airlink.local | 8554 | rtsp\://airlink.local:8554/camera/2 |

To check the video stream using a standard GStreamer pipeline use the following command:

```bash
gst-launch-1.0 rtspsrc location=rtsp://airlink.local:8554/camera/0 ! rtph264depay ! avdec_h264 ! autovideosink sync=false
```

{% hint style="success" %}
If you have any other questions related to the software development with AIRLink please get in touch with our support team [here.](https://sky-drones.com/contact-us)
{% endhint %}


# Troubleshooting

## Unable to access airlink.local

Usually AIRLink dashboard is available at [airlink.local/](http://airlink.local/) address, however, this is browser and router dependent and not all routers support the technology needed for this (local DNS). If your router does not support the Local DNS technology, then you can find the assigned address on the settings page of your router and access AIRLink with the IP address (this is usually 192.168.1.X).&#x20;

To identify the IP address you will need to go to your router dashboard, login and find the connected devices list. Usually, it looks as follows:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlLJNpSSQNQzGSnIKr%2F-MdliHdBY19fKE9i7xbL%2F5.jpg?alt=media\&token=a6706ef3-fe30-499a-8037-c4a16eb00996)

In our case we found our that the IP address of the AIRLink in the home / office network is **192.168.0.19**

Therefore, if we go to **192.168.0.19** in the web browser we will see the same welcome page.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdlLJNpSSQNQzGSnIKr%2F-MdlicMcPy417Lflskzz%2F6.jpg?alt=media\&token=292d5726-5622-4dc1-8e24-3a619e8484a0)

## AIRLink is not accessible over Wi-Fi

1\. Connect the ethernet JST connector cable to the AIRLink port labelled *ETHERNET* (The same cable that is used for connecting AIRLink Telemetry system air unit)

2\. Attach the Sky-Drones ethernet adapter to the other end of JST ethernet cable.

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FVGGMn4OeHi4vxR7RtQLU%2Fethernetdongle2.jpg?alt=media&amp;token=250cad5f-6bd8-46ee-89c9-1225cf90bbad" alt=""><figcaption><p>RJ45 dongle connected to AIRLink's ethernet port</p></figcaption></figure>

3\. Plug in ethernet cable into the Sky-Drones ethernet adapter and connect the other end to your network router, power up AIRLink unit.&#x20;

{% hint style="info" %}
**NOTE:** This must be a regular ethernet cable and not a 'crossover' cable.
{% endhint %}

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FvRLOIq6xJZ7qX19e3ic1%2Fethernetdonglecropped.jpg?alt=media&amp;token=ad634645-dee4-46a4-9e4f-368c5428dbde" alt=""><figcaption><p>Ethernet cable connected from router to the AIRLink's RJ45 dongle</p></figcaption></figure>

4\. On a PC connected to the network: open the browser and go to: *airlink.local* or the IP address assigned to the AIRLink's ethernet port by your router. You may need to login to the router to check the IP address of connected devices or use a network scanning program such as *nmap* or mobile app such as *Fing* to find the wired IP address of the AIRLink unit.

5\. Click *WiFi Settings* button in *Menu* and take care to enter the correct SSID and passphrase.

6\. Click *Apply* button and your airlink will connect over WIFI. (if you are accessing the AIRLink interface via IP address and not the airlink.local address, keep in mind the wireless IP address will be different from the ethernet adapter address so be sure to confirm the new address using methods described in step 4. You can now disconnect the Sky-Drones ethernet adapter.

7\. On a PC connected to the same network, open the browser and enter the address *airlink.local* or the IP address of the AIRLink's wireless connection.

## Mission computer firmware recovery

### Get the firmware

Contact Sky-Drones Technologies using this [contact form ](https://sky-drones.com/contact-us)to get the firmware.

### Prepare microSD card

You will need an empty micro SD card with at least 32GB capacity to flash the firmware image onto it.&#x20;

### Download and install the flashing tool

Download [Balena Etcher](https://www.balena.io/etcher/) software, this will help to prepare the bootable SD card and flash an image onto it. After the download is completed, install the software and open it.&#x20;

### Flash the image onto SD card

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-McOXrNBTErGNTgLanl-%2F-McO_mNjwIxtNcJVCZxE%2Fimage.png?alt=media\&token=31e2e1af-9f57-4093-8560-f4054f54d088)

* Select an **image file** you have just downloaded
* Select the **Target (**&#x79;our 32 GB SD car&#x64;**)**

{% hint style="danger" %}
Make sure that you have selected the correct target which corresponds to the microSD card. Selecting the wrong target will result in the target being overwritten and lost data. &#x20;
{% endhint %}

* Click **Flash!**

The process will take approximately 20 minutes. Make sure to safely unmount SD card before unplugging it from the card reader.

### &#x20;Flash image in AIRLink

1. Insert the SD card into CPU SD card slot
2. Connect the main Power supply to the AIRLink, the system is powered on.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-McOXrNBTErGNTgLanl-%2F-McOqBQ8RQYouA-03JiS%2FIMG_2395.jpg?alt=media\&token=7b650832-4937-4b45-b24f-18c2c668a959)

Firmware upgrade process will be started and will include the following key milestones:&#x20;

1. In approximately 5 minutes, the blue CAM LED will light up. This means that the start of the firmware upgrade process has been successfully initiated.&#x20;
2. In approximately 15-20 minutes CAM LED will start flashing slowly. This means that the firmware process has been completed and the verification stage is in progress.&#x20;
3. In approximately 2-5 minutes after the start of CAM LED flashing, the AIRLink will turn itself off automatically. This means that the firmware upgrade process has been successfully completed.

![CAM LED Status light (Blue)](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-McOXrNBTErGNTgLanl-%2F-McOu7WGAnK2uYVhJ83j%2FIMG_2761.jpg?alt=media\&token=5e2eac50-41ff-4b17-92b6-701015ec46f4)

After that, you need to turn off the power and remove the microSD card. On the next power up the AIRLink will boot in standard operating mode.&#x20;

{% hint style="danger" %}
**WARNING:** DO NOT DISCONNECT THE POWER SUPPLY OF AIRLINK DURING THE UPGRADE PROCESS
{% endhint %}

{% hint style="info" %}
Don't forget to remove the microSD card from the slot. Otherwise, the firmware update process will be started again on the next power up.&#x20;
{% endhint %}

## Autopilot bootloader update

In some cases you might need to update the autopilot bootloader to get it to the latest version or to recover the unit.

### Download Bootloader file

First of all, you would need to download the bootloader file and save it on your computer. You can get the most recent bootloader file with the link below:

{% file src="/files/-MgaGdna\_MIRHG9CYVpc" %}
SmartAP AIRLink Bootloader
{% endfile %}

### Copy bootloader file on a microSD card of the autopilot

Take the microSD card from your autopilot, plug it into your computer and copy **smartap\_airlink\_bootloader.bin** into the foot folder. After that, plug in the microSD card back into the AIRLink FMU microSD card slot.&#x20;

### Run update procedure

Connect SmartAP AIRLink to your computer using FMU USB port and open Terminal in QGC.&#x20;

Locate the microsd card folder:

```
cd fs/microsd
```

List the files to make sure that there is a required bootloader file:

```
ls
```

You would see the following output:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MgaFxqloKVPjNUiS6GT%2F-MgaIOfgw9u7xzNIIX7W%2Fimage.png?alt=media\&token=1fb82e55-1229-42cc-b7eb-35ebba97e70e)

Run bootloader update procedure:

```
bl_update smartap_airlink_bl.bin
```

You should expect the following output:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MgaFxqloKVPjNUiS6GT%2F-MgaIjbxUflsrCVdLYCd%2Fimage.png?alt=media\&token=7a21f42d-48bb-4821-bcfe-3f53d2b9b49f)

Autopilot bootloader update has been successfully completed.&#x20;


# CAD Model

Download STEP files of SmartAP AIRLink for integrating into your own design:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MbY3nO-JjGY47cknzp4%2F-MbY4vMilkDBgQ2nu6rl%2Fimage.png?alt=media\&token=d50bfac6-ab55-407b-a5e1-0beb6efb08ae)

{% file src="/files/-MYKMM5-lk5UwYoJf2Co" %}
SmartAP AIRLink STEP File
{% endfile %}

{% file src="/files/9g3pOYrwjJnzqtlZpR8P" %}
SmartAP AIRLink Core STEP File
{% endfile %}

{% hint style="info" %}
SmartAP AIRLink Core edition (without the enclosure) CAD file password is available upon request.&#x20;

Please get in touch with us [here.](https://sky-drones.com/contact-us)
{% endhint %}

{% hint style="success" %}
Would you like to manufacture your own SmartAP AIRLink? Would you like to license the hardware design?&#x20;

Please get in touch with us [here](https://sky-drones.com/contact-us).
{% endhint %}


# Certification

SmartAP AIRLink has the required RF compliance certificates.

{% hint style="success" %}
Please contact us [here](https://sky-drones.com/contact-us) for certificates pack.
{% endhint %}

## Redundancy

* 3x redundant IMU (accelerometers, gyroscopes, magnetometers)&#x20;
* 3x redundant pressure sensors&#x20;
* 2x redundant GNSS&#x20;
* 3x redundant power supply input&#x20;
* Low battery failsafe&#x20;
* GNSS loss failsafe&#x20;
* Radio link loss failsafe&#x20;
* Manual control loss failsafe
* IMU health checker


# FAQ

A selection of questions put forward by our consumers. If you require any more information, do not hesitate to contact us today!

## When is AIRLink available to purchase?

Right now! We have ramped up production of AIRLink units and it's easy to order one from our sales team by completing our [contact form](https://sky-drones.com/contact-us) on the [Sky-Drones website](https://sky-drones.com/)

## Where can I find detailed specifications for AIRLink?

Slightly more generic information is available on our website on the [AIRLink product page](https://sky-drones.com/airlink), and we have our detailed [online documentation here](/avionics/airlink) that has a more in-depth collection of data on AIRLink

## Where can I find the setup and installation information for AIRLink?

Via our [online documentation available here](/avionics/airlink), or follow docs.sky-drones.com - this is our online documentation portal and contains all the detailed information for all our hardware and software products

## Does AIRLink support payload connections? How can I connect my payload to AIRLink?

AIRLink has two camera ports. One is a CSI and the other is HDMI. We include a CSI camera in every AIRLink set, alongside a mini-HMDI to micro-HDMI cable for connecting your payload camera immediately. USB cameras or IP-based cameras are also attachable, just [get in touch](https://sky-drones.com/contact-us) and we can talk you through it!

## Can I run my own software on AIRLink?

Yes! We can give you full access to the mission computer and autopilot so you can deploy your own applications through AIRLink. This is something we can work on with you, so make sure to [enquire now](https://sky-drones.com/contact-us)

## Is AIRLink open source?

AIRLink uses widely adopted drone industry standards so modifying the software is doable. The hardware is not open source but for our large volume manufacturers we can provide you with the reference design and help you set up your own production process. This will allow you to control your own volume of AIRLink sets

## Is AIRLink powerful enough to run AI algorithms and machine learning?

Yes! AIRLink quite literally stands for 'Artificial Intelligence and Remote Link'. This means that you have the computing power to run complex algorithms onboard

## How can I connect AIRLink to my computer?

AIRLink has both integrated WiFi and LTE connectivity. WiFi can be used as the access point to connect AIRLink to your router, and LTE connectivity means that AIRLink comes to you with the internet already enabled. You need only set up or log into your[ Sky-Drones Cloud](https://sky-drones.com/sky-drones-cloud) account and enable the data plan. \
\
Alternatively, use your own carrier and data plan and manage this yourself if you'd prefer.\
\
Finally, AIRLink has an ethernet port for IP datalink integration. Stay up to date with Sky-Drones for more information!

## What is your manufacturing capability?

AIRLink is manufactured in the hundreds per month, but if required we can manufacture thousands per month with a prior requirement notification. AIRLink is manufactured in the United Kingdom using genuine and quality-assured materials. All units are tested before being shipped to customers &#x20;


# ATLAS Handheld

Handheld ground control station unit for robotics application

ATLAS Handheld is a compact and lightweight IP-rated mobile industrial handheld ground station unit. It includes a powerful computer, broadband datalink, HD Video transmission, LTE connectivity, touchscreen and much more.

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FuN8EeQ2gUBOkJfuAp4YU%2Fatlas-controller-index.jpg?alt=media&amp;token=16255248-2c0d-4c1e-b18c-954754808674" alt=""><figcaption></figcaption></figure>

### Supported Software

ATLAS Handheld supports various control software including SmartAP GCS, QGroundControl, Mission Planner and any other of your choice.

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FcOyn4D3FI5pNhfA9C2YP%2F3.jpg?alt=media&amp;token=a3e8607e-e9fa-4776-af87-fdc9ecd2ac20" alt=""><figcaption></figcaption></figure>

### NDAA Compliance

ATLAS Handheld is fully compliant with the 2020 National Defense Authorization Act, Sec 848


# Feature Highlights

Key features of ATLAS Handheld

### Overview

ATLAS Handheld provides real-time video feed from multiple cameras as well as a map with detailed telemetry information. Easily switch between a map and video feeds with a simple tap of the screen.

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FckzeTg4QLyW0h76HKEAa%2F8.jpg?alt=media&amp;token=2da441be-956a-4c40-a827-eacafd0548e8" alt=""><figcaption></figcaption></figure>

Control any type of vehicles, including:

* Quadcopters
* Multicopters
* VTOLs
* Fixed wings
* Rotary wings
* Ground robots

### Controls assignment

ATLAS Handheld has 4 high-accuracy Hall-effect joysticks. Functions assignment can be easily done in the software. Upper joysticks are recommended for UAS control (roll, pitch, yaw, thrust) and lower joysticks for payload control - gimbal orientation and camera controls. The controller is designed for operators as a primary user.

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FJnPCHPJzRuFLm3oVweiG%2Fimage.png?alt=media&amp;token=4d10f68a-817a-474a-898c-bc087d72a68a" alt=""><figcaption></figcaption></figure>

### Long-range Connectivity

ATLAS Controller has integrated long raange telemetry module with high bandwidth allowing to transmit high resolution video, telemetry data, manual control and payload data. Key features include:

* 2.4 GHz&#x20;
* up to 30 dBm output power&#x20;
* FCC / CE compliant
* AES-256 encryption&#x20;
* Ultra low latency

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FgJocPy3zdphRdreuNHGe%2F7.jpg?alt=media&amp;token=6a259352-e905-4b9e-b9c1-f4fe181bb3de" alt=""><figcaption></figcaption></figure>

{% hint style="info" %}
Radio module can be disabled when it's not needed, e.g. when operating over LTE.
{% endhint %}

### Paired with AIRLink Telemetry

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2Fzt4aTyENkqC8KT2EhcQZ%2F11.jpg?alt=media&amp;token=a6771a4c-0645-4327-815d-5f133e9a2002" alt=""><figcaption></figcaption></figure>

### Ergonomic Design

ATLAS Handheld's ergonomic design perfectly fits in the operator's hands and allows continuous work. Additionally, it's IP68 rated with dust protection and water resistance.


# Detailed Specifications

Full system specifications list

#### Processor and Memory

| Parameter | Value               |
| --------- | ------------------- |
| CPU       | Octa Core, 2.7GHz   |
| RAM       | 4GB                 |
| ROM       | 64GB                |
| External  | MicroSD (Up to 1TB) |

#### Radio

| Parameter  | Value             |
| ---------- | ----------------- |
| Technology | 2x2 MIMO          |
| Frequency  | 2402 - 2482 MHz   |
| Power      | up to 30 dBm / 1W |
| Bandwidth  | 4 / 8 MHz         |
| Encryption | AES-256           |
| Data rate  | 25 Mbps           |

#### Environment

| Parameter           | Value       |
| ------------------- | ----------- |
| Resistance          | IP-68       |
| Ambient temperature | -40...+50°C |

#### Screen

| Parameter  | Value               |
| ---------- | ------------------- |
| Size       | 8"                  |
| Resolution | 1920 x 1200 (WUXGA) |

#### Size & Weight

| Parameter  | Value         |
| ---------- | ------------- |
| Dimensions | 286x166x57 mm |
| Weight     | 1140 g        |

#### Battery

| Parameter        | Value                    |
| ---------------- | ------------------------ |
| Type             | Li-Ion, fully integrated |
| Capacity         | 5050 mAh                 |
| Charge current   | 4A                       |
| Charge interface | USB Type C               |


# Initial setup

This page will help you to set up your ATLAS Handheld

## Power up ATLAS Controller

* Open the Pelican case and remove ATLAS Controller
* Make sure that the antennas are mounted properly

{% hint style="danger" %}
**WARNING**

Do not power on the radio module without antennas. It may significantly reduce the quality of the radio or damage the radio module permanently.
{% endhint %}

* Press Power button for a second until the unit starts to power up. The boot up process usually takes 15 seconds.

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2Fo5844YGo1LCDyjlQUbOJ%2FIMG_1956.JPG?alt=media&amp;token=ceb06984-1316-4bf5-9ffc-b49fe5ec0249" alt=""><figcaption></figcaption></figure>

* After ATLAS is loaded up make sure the WiFi is disabled in order for Ethernet to work properly.
* If you wish to use radio connectivity please press the power button on the radio module:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FREbdGZ9KvSVYBdPKS5rw%2F6.jpg?alt=media&amp;token=e8732949-2a4c-40a5-96c2-b8a0be4a2ce1" alt=""><figcaption></figcaption></figure>

* Make sure that radio module status LEDs are blinking / solid:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FsISmcwWR3q2dVj8e1VSz%2FIMG_1956.JPG?alt=media&amp;token=9d091077-9ab6-47ef-933c-2fa35b5124ca" alt=""><figcaption></figcaption></figure>

## Start the Application

Once ATLAS Handheld is loaded you can start the ground control station app. Simply click on the desired app on the main screen or apps menu.

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FVZfIBDSFzenrpinENBOl%2FPicture%201.png?alt=media&amp;token=e0b8e580-2717-4829-9b6d-85d2e92a2868" alt=""><figcaption></figcaption></figure>

After the app has started you will see its main screen:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FktlYSr5Vqv9UW4ctjtDQ%2FPicture%202.png?alt=media&amp;token=52671265-b578-4985-963e-4dd6c5b836fc" alt=""><figcaption></figcaption></figure>

You can also install any other apps of your choice. We recommend installing the apps via Google Play Store. You can install .apk too.

## Power Off

* Close the ground control station app by returning to the main screen or pressing the home button.
* Press the Power button on the radio module to turn off the radio:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FrSNjduNTr0LRbJjNnlEJ%2FIMG_1957.JPG?alt=media&amp;token=f8561736-b48e-4691-9891-03d158d421fc" alt=""><figcaption></figcaption></figure>

* On the controller’s homepage, use the drop down menu on the top right of the screen to select the “Power Off” button or press VOLUME DOWN and POWER buttons for the power off menu.

## Charging

Plug in the USB Type C cable to the USB charging port as shown on the image below:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2F7GzqtWQVUYjV15DJ4SeM%2FIMG_1959.JPG?alt=media&amp;token=917aa854-557b-406d-aa64-3d259a34738f" alt=""><figcaption></figcaption></figure>

ATLAS Handheld can be charged while also being operated. This allows an operator to use ATLAS Handheld regardless of the battery charge level.


# Troubleshooting

Some troubleshooting guidance which will help to resolve the questions quickly.

| Problem                             | Solution                                                                                                                                             |
| ----------------------------------- | ---------------------------------------------------------------------------------------------------------------------------------------------------- |
| Unit doesn't turn on                | Make sure that the unit is charged. Connect the charger and try to power up the unit again.                                                          |
| Drone telemetry is not connecting   | Make sure that your radio module is turned on the modules are paired.                                                                                |
| Air module is not paired with ATLAS | Press and hold ATLAS reset button for 6 seconds. Press and hold Air module reset button for 11 seconds. After 30 seconds the modules will be paired. |
| I can't download the maps           | Internet connection is required to download the maps. Make sure that you have active WiFi or LTE connection on ATLAS.                                |

{% hint style="info" %}
If you can’t find the answers in the troubleshooting section above or in the user manual, please contact us here: <https://sky-drones.com/contact-us>​
{% endhint %}


# AIRLink Telemetry

AIRLink Telemetry provides broadband AES-256 encrypted private channel for 20km.

### Set content

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FXuVVUgF0E9Ec3a0jmPvx%2Fairlink-telemetry.jpg?alt=media&amp;token=b6165b98-0bfd-4027-9681-e18c8766998e" alt=""><figcaption></figcaption></figure>

* 1x Ground module
* 1x Air module
* 2x Ground module antennas&#x20;
* 2x Air module antennas
* 1x Telemetry cable
* 1x Ground module power cable

### General specifications

#### Radio

| Parameter  | Value             |
| ---------- | ----------------- |
| Technology | 2x2 MIMO          |
| Frequency  | 2402 - 2477 MHz   |
| Power      | up to 30 dBm / 1W |
| Bandwidth  | 4 / 8 MHz         |
| Encryption | AES-256           |
| Data rate  | 25 Mbps           |
| Latency    | < 100 ms          |
| Range      | 20 km             |

#### Environmental

| Parameter           | Value                 |
| ------------------- | --------------------- |
| Visibility          | Direct, line of sight |
| Ambient temperature | -40...+50°C           |

### Air module specifications

![AIRLink Telemetry Air module](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdNqNF5-SDcjPSVIgwj%2F-MdNyc0b5ZBDCn3hKygj%2FIMG_2878.jpg?alt=media\&token=7c25e8ab-d2bd-4d23-963d-c9313846627a)

| Parameter   | Value                         |
| ----------- | ----------------------------- |
| Power input | 5V DC, 2A min                 |
| Antennas    | x2 SMA Omni 3dBi, 50 cm cable |
| Interfaces  | Ethernet, cooling fan output  |
| Dimensions  | 50x50x30 mm                   |
| Weight      | 50 g                          |

### Ground module specifications

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FA0gwLC04caSzwpG0liQm%2F2.jpg?alt=media&amp;token=e11e99d7-59ce-44f8-88a7-fb006d9e10a6" alt=""><figcaption><p>AIRLink Telemetry Ground module</p></figcaption></figure>

| Parameter   | Value                             |
| ----------- | --------------------------------- |
| Power input | 7-40V DC, 1A min                  |
| Antennas    | x2 RP-SMA 5dBi                    |
| Interfaces  | Ethernet, USB, UART, power supply |
| Dimensions  | 82x71x21 mm                       |
| Weight      | 137 g                             |

### Throughput and signal strength

<table><thead><tr><th width="150">Range, km</th><th width="150">Modulation</th><th width="150">Throughput, Mbps</th><th>Sensitivity, dBm</th></tr></thead><tbody><tr><td>0 - 0.3 km</td><td>64QAM_5/6</td><td>27.8</td><td>-81</td></tr><tr><td>0.3 - 1 km</td><td>64QAM_3/4</td><td>25.5</td><td>-83.5</td></tr><tr><td>1 - 2 km</td><td>64QAM_2/3</td><td>22.8</td><td>-85</td></tr><tr><td>2 - 4 km</td><td>16QAM_3/4</td><td>17.1</td><td>-90</td></tr><tr><td>4 - 8 km</td><td>16QAM_1/2</td><td>11.6</td><td>-92</td></tr><tr><td>8 - 12 km</td><td>QPSK_3/4</td><td>8.8</td><td>-96</td></tr><tr><td>12 - 15 km</td><td>QPSK_1/2</td><td>5.9</td><td>-98</td></tr><tr><td>15 - 20 km</td><td>BPSK_1/2</td><td>3</td><td>-99.5</td></tr></tbody></table>


# Interfaces

This page describes the general information and interfaces location of AIRLink Telemetry Module.

### Front side

![Front side](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdJwtY4K6hSTPCuNuFH%2F-MdK-y17WYW4x7yRzHig%2Ffront.jpg?alt=media\&token=45cad0c7-0bfe-4e1a-8a5e-0ba4c320a858)

#### ETHERNET - JST GH SM08B-GHS-TB

| Pin number | Pin name | Direction | Voltage level | Function                   |
| ---------- | -------- | --------- | ------------- | -------------------------- |
| 1          | 5V       | IN        | +5V           | Radio module power supply  |
| 2          | 5V       | IN        | +5V           | Radio module power supply  |
| 3          | ETH\_TXP | OUT       | +3.3V         | Ethernet transmit positive |
| 4          | ETH\_TXN | OUT       | +3.3V         | Ethernet transmit negative |
| 5          | ETH\_RXP | IN        | +3.3V         | Ethernet receive positive  |
| 6          | ETH\_RXN | IN        | +3.3V         | Ethernet receive negative  |
| 7          | GND      |           |               | Ground                     |
| 8          | GND      |           |               | Ground                     |

{% hint style="info" %}
The ethernet interface is decoupled with capacitors. Ethernet cable should be twisted to reduce EMI noise. Shorter cables are recommended for increased performance and higher bandwidth of the interface.
{% endhint %}

#### FAN - JST GH SM06B-GHS-TB

| Pin number | Pin name | Direction | Voltage level | Function   |
| ---------- | -------- | --------- | ------------- | ---------- |
| 1          | 5V       | OUT       | +5V           | Fan output |
| 2          | Reserved |           |               |            |
| 3          | Reserved |           |               |            |
| 4          | Reserved |           |               |            |
| 5          | Reserved |           |               |            |
| 6          | GND      |           |               | Ground     |

### Left side

![Left siide](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdJwtY4K6hSTPCuNuFH%2F-MdK0SUWvxK9SrEdWlUo%2Fleft.jpg?alt=media\&token=d7a31084-602e-46d5-b1be-52a652ec0b1e)

* SMA Antenna connector

### Right side

![Right side](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdJwtY4K6hSTPCuNuFH%2F-MdK0bEIimpZuqHIvz6S%2Fright.jpg?alt=media\&token=9720fb61-569f-49ba-81ab-573b5bb2ee6e)

* SMA Antenna connector
* Reset button

### Read side

![Rear side](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdJwtY4K6hSTPCuNuFH%2F-MdK0phKRfYSB7BRKLPZ%2Frear.jpg?alt=media\&token=9c6310ee-1f58-42a4-9ae7-b3367d8e2055)

* TX LED - Transmission activity
* RX LED - Receiving activity
* LINK LED - Link activity
* CPU LED - CPU activity
* PWR LED - Power enabled
* RSSI LEDs - Received signal strength indication

RSSI LEDs status:&#x20;

* Blinking in turn: **searching for pair**
* Blinking all at once: **RF disabled**
* Solid: **RF connection established, pair found**

### Top side

![Top side](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdJwtY4K6hSTPCuNuFH%2F-MdK1OGU2gsYL5buKczt%2Ftop.jpg?alt=media\&token=f1f36bc9-a075-4f8b-bc34-47a88d4043f2)

The top side has an enclosure-integrated heatsink.&#x20;

{% hint style="info" %}
AIRLink telemetry module is designed to work standalone (no cooling fan) without overheating at maximum output power with ambient temperatures of up to 50° C.&#x20;

In case there is a chance of overheating in your application - the module has 4x M3 mounting holes for the cooling fan.&#x20;
{% endhint %}

### Bottom side

![Bottom side](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdJwtY4K6hSTPCuNuFH%2F-MdK2fhJCM-DInHRo34z%2Fbottom.jpg?alt=media\&token=368d229a-418d-488c-afe0-00afff1e8f4e)

## Ground Module

### Top

The top side has an a heatsink and mounting holes for an optional fan. It's important to have a clear space to allow for airflow circulation in front of this side.&#x20;

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FGdlUTUb5XnltmV4kgKka%2F3.jpg?alt=media&amp;token=5b0441f3-6934-4e11-847b-9f9b1657716e" alt=""><figcaption></figcaption></figure>

### Left

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2F5XICqRNuCoRcQA983KBR%2F7.jpg?alt=media&amp;token=eb2b8f25-ad4b-45db-bbb4-1e5920625e82" alt=""><figcaption></figcaption></figure>

### Front

SMA antenna connectors for antennas

Status LEDs:

* TX: blinking when packets are being transmitted
* RX: blinking when packets are being received
* CPU: module operating
* RSSI: signal quality

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FV4anJ7ndA3g674G026Co%2F6.jpg?alt=media&amp;token=6e2b3e82-e34f-4601-8409-09d6a4ef2ccc" alt=""><figcaption></figcaption></figure>

### Right

* Reset button
* Fan port

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FlmHdeCXZquTHsYWd2dAr%2F5.jpg?alt=media&amp;token=73142c0c-0eb1-418d-a710-008b57f1fd51" alt=""><figcaption></figcaption></figure>

### Rear

* USB to connect to computer / tablet
* Ethernet port (RJ45)
* Power supply, 7-35V DC
* Serial port

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FTNqld4JSOBZd0mFtpFDl%2F4.jpg?alt=media&amp;token=64ea14e2-5500-4986-8df8-ad603a8cf10d" alt=""><figcaption></figcaption></figure>

### Bottom

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FThg8I2DzU8Bv2tswOusy%2F8.jpg?alt=media&amp;token=7c88f45e-9ee5-44d9-b25d-09cdded824a6" alt=""><figcaption></figcaption></figure>

{% hint style="info" %}
Looking for CAD files? They are available [here.](/avionics/airlink-telemetry/cad-model-1)
{% endhint %}


# Installation

Let's wire up and connect AIRLink Telemetry

### Ground module

Take the ground module, antennas and power cable:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FQNuaPMBNgQRkAvB9yCwv%2F9.jpg?alt=media&amp;token=6086d58d-2637-4d96-a7c4-b5d665b97878" alt=""><figcaption></figcaption></figure>

Attach the antennas to the ground module. Connect the power cable.&#x20;

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FOX84CR8Pmm51gRJkCXDF%2F10.jpg?alt=media&amp;token=d55b2a3a-b50c-4b66-9753-44960bc53169" alt=""><figcaption></figcaption></figure>

{% hint style="danger" %}
**DANGER:** DO NOT POWER ON THE MODULE WITHOUT ANTENNAS, THIS WILL CAUSE PERMANENT DAMAGE AND IS NOT COVERED BY THE WARRANTY
{% endhint %}

### Air module

Take air module and air module antennas:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdO6g43JAme6t44Pamr%2F-MdOEhvy1M_7X7lcDHiW%2FIMG_2908.jpg?alt=media\&token=2a2eae9b-37a9-4f51-b0bc-62b29a129297)

Connect air module antennas:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdO6g43JAme6t44Pamr%2F-MdOF26bMwDkSdKaNW60%2FIMG_2909.jpg?alt=media\&token=4c76c4cb-1a37-46f9-a5c0-eb616ae94df4)

Take Ethernet telemetry cable and connect it to the Ethernet port of Air module:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdO6g43JAme6t44Pamr%2F-MdOFOOAv2pilKjDXIDI%2FIMG_2910.jpg?alt=media\&token=355ebacd-202c-41d9-83f9-2d9303c9378c)

Fully assembled Air module will looks as follows:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdO6g43JAme6t44Pamr%2F-MdOFgkzO5YBkw9zZ2US%2FIMG_2913.jpg?alt=media\&token=07f609c4-2db0-4f88-9349-ec56f9d8f7ce)

### Connecting to AIRLink

Connect Air module Ethernet cable to Ethernet port of AIRLink:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdO6g43JAme6t44Pamr%2F-MdOHlIInAgRb0AiNDNR%2FIMG_2915.jpg?alt=media\&token=236200c0-cc25-4bd6-9cca-6f309e81c2ef)

{% hint style="info" %}
It's recommended to twist Ethernet cable to increase the EMI sustainability.&#x20;
{% endhint %}

The assembled systems should looks as follows:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdO6g43JAme6t44Pamr%2F-MdOIiWwm5hYcDilL8kF%2FIMG_2918.jpg?alt=media\&token=75fad43e-7625-454c-96ac-48de30083348)


# Initial setup

## Power up

Ground module supports two different power options - via USB or via dedicated power socket from the external power source.&#x20;

### USB power

The module can be powered directly from the USB port which can also provide communication to computer. Simply plug USB Type C cable into the USB port:&#x20;

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2F2YC7WRavCi6K0wMqkKZ8%2FIMG_0668.JPG?alt=media&amp;token=23a0661e-adfe-4cc4-beac-a2cbc5bb1bc6" alt=""><figcaption></figcaption></figure>

### External power

The module can be powered with the dedicated power supply in the voltage range of 12-35V.

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2F7iZ0MLYKlCLi2vIpVxm0%2FIMG_0669.JPG?alt=media&amp;token=9bbfdd16-d29e-4d32-b87f-253b52598a87" alt=""><figcaption></figcaption></figure>

{% hint style="info" %}
For the maximum RF performance It's recommended to use external power supply rather than USB power supply.
{% endhint %}

## Ethernet

Connect Ethernet cable to RJ45 port as shown on the image below:&#x20;

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FM9BpUb43eEd2f3KhTnKZ%2FIMG_0660.JPG?alt=media&amp;token=3c78f030-8441-47bd-88c5-cd5b899cd462" alt=""><figcaption></figcaption></figure>

Connect the other side of the Ethernet cable to computer.&#x20;

## Verify the connection

It will take about 30 seconds until the module boots up. The computer will get an IP address in the range of 192.168.168.X. This can be verified in connectivity settings or in command line with **ifconfig** command (MacOS / Linux) or **ipconfig** (Windows):

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2F674PjmwpDWVy8ANrsFRY%2Fsmartlink-cmd.jpg?alt=media&amp;token=102da934-898b-40c9-a2f3-0d52122677e0" alt=""><figcaption></figcaption></figure>

Default IP addresses configuration:&#x20;

<table><thead><tr><th width="374">Module</th><th>IP Address</th></tr></thead><tbody><tr><td>Air module</td><td>192.168.168.1</td></tr><tr><td>Ground module</td><td>192.168.168.2</td></tr></tbody></table>

You can check the connection to Air module with **ping** command:&#x20;

```
ping 192.168.168.1
```

## Ethernet vs USB

It's recommended to use native Ethernet connection however you can also use Ethernet over USB connection (RNDIS). The computer will receive IP address similarly to the way where it's connected via Ethernet natively. Initial setup requires some drivers installation. Later the module can be used normally as plug-n-play. Refer to the next section for the initial drivers installation procedure:


# USB connection setup

To setup drivers for Ground module using USB connection please proceed with the following steps.

Download the required drivers and unpack them to local folder:

{% file src="/files/Bk4LPJkggxxBXIimF9TD" %}

Plug in Ground module to computer using USB Type C cable and open **Device Manager.** Locate Other Devices > RNDIS:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FIdIy7p4tAgoac8Ido0Qt%2FScreenshot%202022-09-21%20at%2012.15.38.png?alt=media&amp;token=07b8ad3d-6574-4487-ae1d-c64942ad0062" alt=""><figcaption></figcaption></figure>

Right click on **RNDIS** and select **Update Driver:**

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FwDIzyM013l3GlMDYhDNT%2FScreenshot%202022-09-21%20at%2012.15.51.png?alt=media&amp;token=2040f4e9-2800-4802-877d-58f6cff25622" alt=""><figcaption></figcaption></figure>

Select **Browse my computer for drivers:**

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FaetDbxiq1EDqg1TdxXLH%2FScreenshot%202022-09-21%20at%2012.16.02.png?alt=media&amp;token=7f286e70-385b-4e81-bcf3-ee2e53222566" alt=""><figcaption></figcaption></figure>

Select **Let me pick up from a list of available drivers on my computer**:&#x20;

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FNWHNyH6Yd5PvlI01H4zt%2FScreenshot%202022-09-21%20at%2012.16.17.png?alt=media&amp;token=37ccbf3d-bcdf-4c7c-97b5-318935d65232" alt=""><figcaption></figcaption></figure>

Click **Show all devices** and then **Next:**

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FpLzGetB3PeMbUukzW6Hn%2FScreenshot%202022-09-21%20at%2012.16.26.png?alt=media&amp;token=7d42c077-a40d-4576-9d7a-c75140113b44" alt=""><figcaption></figcaption></figure>

Select **Microhard Systems Inc**. > **Remote NDIS based device** and click **Next:**

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FF4u3Sp4pCzxs8hj947st%2FScreenshot%202022-09-21%20at%2012.16.53.png?alt=media&amp;token=2aefecd1-473e-498e-a55f-90df306988d3" alt=""><figcaption></figcaption></figure>

Click **Yes**:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2F57pSY7mRlLsLZXiLoUn9%2FScreenshot%202022-09-21%20at%2012.17.00.png?alt=media&amp;token=b5aa6ba8-22af-4d52-8e0d-31be3ee2424d" alt=""><figcaption></figcaption></figure>

Congratulations! The driver was successfully installed!

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FEAl7mNVbLSJq0gwX57ae%2FScreenshot%202022-09-21%20at%2012.17.08.png?alt=media&amp;token=e2f858e2-0492-470b-9346-58368e75d51f" alt=""><figcaption></figcaption></figure>

{% hint style="info" %}
If you have an issue with step above you may need to [disable driver signature](https://learn.sparkfun.com/tutorials/disabling-driver-signature-on-windows-8/disabling-signed-driver-enforcement-on-windows-8) in Windows:

Hold down the Windows key on your keyboard and press the letter C to open the Charm menu, then click the gear icon (Settings).&#x20;

* Click More PC Settings.&#x20;
* Click General
* Under Advanced Startup, click Restart Now
* After restarting, click Troubleshoot
* Click Advanced Options
* Click Windows Startup Settings
* Click Restart

After restarting your computer a second time, choose Disable driver signature enforcement from the list by typing the number 7 on your keyboard.

After restarting, you will be able to install the Arduino drivers normally.
{% endhint %}

Now you can see correctly recognised device in a device tree menu:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FMIQJKQsS3ho6EGObmnzj%2FScreenshot%202022-09-21%20at%2012.17.19.png?alt=media&amp;token=834f15a0-50c7-4b95-ad19-22428e71824c" alt=""><figcaption></figcaption></figure>

To confirm this you may open terminal and type **ipconfig:**

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FwyMLiG0ktJrlbqSmrCAg%2FScreenshot%202022-09-21%20at%2012.17.43.png?alt=media&amp;token=26f9e9f1-3c44-495a-b19d-2c62dd9486a1" alt=""><figcaption></figcaption></figure>

You will be able to locate the new Ethernet adapter with an assigned IP address in the range of 192.168.168.X.&#x20;

Now you can use ground module via USB the same as as it can be used with a native Ethernet based connection.


# CAD Model

For tight integration in your design

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MdO6g43JAme6t44Pamr%2F-MdOD6tYhUZtk_4HUczZ%2Fcad.jpg?alt=media\&token=b908b807-9640-4972-8be9-d2d49b2e389c)

Download STEP files of SmartAP AIRLink Telemetry for integrating into your own design:

{% file src="/files/-MdO5sDL7598Niy0TSXF" %}
AIRLink Telemetry Air Module
{% endfile %}

{% hint style="info" %}
AIRLink Telemetry ground module is the same as SmartLink ground module.
{% endhint %}

{% hint style="success" %}
Would you like to manufacture your own AIRLink Telemetry module? Would you like to license the hardware design?&#x20;

Please get in touch with us [here](https://sky-drones.com/contact-us).
{% endhint %}


# SmartLink

SmartLink is a broadband digital datalink with an integrated onboard computer. Two HD video channels, telemetry and control with ultra-low latency and a range of up to 20 km.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTMygopV7YI20_lpkXf%2F-MTN35bZGY7BhNHh39A_%2Fsmartlink-hardware-main.jpg?alt=media\&token=c411c102-f351-4e47-b8c6-706fc8f0e69d)

## SmartLink Launch Webinar

Recording of the LIVE webinar hosted by Sky-Drones Founder & CEO Kirill Shilov demonstrating the most advanced drone connectivity unit - SmartLink.

{% embed url="<https://www.youtube.com/watch?v=pOlX6_TUv1w>" %}

## Description

### Air module

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTMygopV7YI20_lpkXf%2F-MTN3PZmfg48Xu7q_jm3%2Fsmartlink-specs-air-module.jpg?alt=media\&token=be3e0123-0152-43d2-b320-4a99586b94de)

[SmartLink](https://sky-drones.com/smartlink) Air is based on a powerful quad-core ARM Cortex A53 SoC (system-on-chip) computer running Linux. The system is capable of handling two real time HD video streams from cameras (CSI and HDMI), autopilot telemetry and control. It has an abundant supply of resources for user applications with various interfaces including USB, UART, I2C, and SPI allowing users to connect their desired payloads and tightly integrate it with their flight controller and / or ground control station. LTE connection is also available and is operated by plug and play technology.

### Ground module

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTMygopV7YI20_lpkXf%2F-MTN3SsqdC-WNIGzi55G%2Fsmartlink-specs-ground-module.jpg?alt=media\&token=74d290b3-cb85-49fd-9a43-969983c59432)

Ground module is extremely compact and lightweight. It has a micro USB connector to interact with any kind of device - laptops, smartphones, tablets, and desktop computers are all supported. All you need to do is connect it and open the [SmartAP GCS](/flight-operations/smartap-gcs) application. Ground module features an active cooling system which allows the module to withstand high ambient temperatures making it even more reliable in harsher environments. 2x2 MIMO technology provides higher bandwidth, lower latency and longer range.

## How it works

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTMygopV7YI20_lpkXf%2F-MTN3hkAkb5VdIsjMIwk%2Fsmartlink-use-case.jpg?alt=media\&token=3a7b054e-ba52-4c3e-b1ec-b2616acd34fe)

## Included in your set

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTMygopV7YI20_lpkXf%2F-MTN3rjAwKdu19HmhJ6I%2Fsmartlink-set.jpg?alt=media\&token=880e994f-267c-40f2-94ce-ba24c38b0e26)

1. SmartLink Ground Module
2. SmartLink Air Module
3. 2x Air Module antennas
4. 2x Ground Module antennas
5. CSI Camera
6. Telemetry cable
7. HDMI cable
8. Air Module power cable
9. Ground Module power cable

## Interfaces

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTMygopV7YI20_lpkXf%2F-MTN3xMZXl6A911MXy5Z%2Fsmartlink-air-interfaces.jpg?alt=media\&token=cf59065b-ed6d-4479-b18f-b2908c9f23b8)

## Software

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FOp8JgTmna4dnTFh32WRq%2Fimage.png?alt=media&amp;token=c014becb-1279-4897-ad1f-3ac0d02a1615" alt=""><figcaption></figcaption></figure>

SmartLink was specifically designed to be used with [SmartAP GCS](/flight-operations/smartap-gcs) - our powerful cross-platform ground control station. [SmartAP GCS](/flight-operations/smartap-gcs) supports:

* 2x HD video streams display
* Full camera controls
* Video recording on microSD card
* Image capture on microSD card
* Radio settings configuration
* Drone control joystick
* Payload control joystick

[SmartAP GCS](/flight-operations/smartap-gcs) can be used on any platform and operating system including MacOS, Windows, iOS, Android and Linux. The software provides all status information on radio link including RSSI, SNR and allows you to dynamically change all major settings. For instance, operating frequency, bandwidth or power can be changed with one click. Remote module configuration is done automatically via the ground module.

## Throughput and signal strength

| Range, km  | Modulation | Throughput, Mbps | Sensitivity, dBm |
| ---------- | ---------- | ---------------- | ---------------- |
| 0 - 0.3 km | 64QAM\_5/6 | 27.8             | -81              |
| 0.3 - 1 km | 64QAM\_3/4 | 25.5             | -83.5            |
| 1 - 2 km   | 64QAM\_2/3 | 22.8             | -85              |
| 2 - 4 km   | 16QAM\_3/4 | 17.1             | -90              |
| 4 - 8 km   | 16QAM\_1/2 | 11.6             | -92              |
| 8 - 12 km  | QPSK\_3/4  | 8.8              | -96              |
| 12 - 15 km | QPSK\_1/2  | 5.9              | -98              |
| 15 - 20 km | BPSK\_1/2  | 3                | -99.5            |


# Interfaces

This page describes general information and interface location for SmartLink Air and Ground modules.

## Air Module

### Top

Antenna SMA connectors

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2Fsync%2Fbfb3d2aedd53de591a343e5d69caa3128b1818dc.jpg?generation=1613164694130792\&alt=media)

### Left

* 5V DC power input socket
* Reset button
* CSI camera Port
* USB for firmware upgrade
* SPI 0 / 1
* I2C 0 / 1
* UART 0 / 1 (console and autopilot telemetry)

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2Fsync%2F92484b315840b78248bbbee084d31376d5bba01d.jpg?generation=1613164696104674\&alt=media)

{% hint style="info" %}
Pin numbers are referenced to MOLEX 53261-0671 connector pinout.&#x20;
{% endhint %}

#### SPI1 Connector pinout - MOLEX 53261-0671

<table><thead><tr><th width="150">Pin</th><th>Name</th></tr></thead><tbody><tr><td>1</td><td>5V OUT</td></tr><tr><td>2</td><td>SPI1 SCLK</td></tr><tr><td>3</td><td>SPI1 MISO</td></tr><tr><td>4</td><td>SPI1 MOSI</td></tr><tr><td>5</td><td>SPI1 CS0</td></tr><tr><td>6</td><td>GND</td></tr></tbody></table>

#### I2C Connector pinout - MOLEX 53261-0671

<table><thead><tr><th width="150">Pin</th><th>Name</th></tr></thead><tbody><tr><td>1</td><td>5V OUT</td></tr><tr><td>2</td><td>I2C1 SCL</td></tr><tr><td>3</td><td>I2C1 SDA</td></tr><tr><td>4</td><td>I2C2 SCL</td></tr><tr><td>5</td><td>I2C2 SDA</td></tr><tr><td>6</td><td>GND</td></tr></tbody></table>

#### UART Connector pinout - MOLEX 53261-0671

<table><thead><tr><th width="150">Pin</th><th>Name</th></tr></thead><tbody><tr><td>1</td><td>5V OUT</td></tr><tr><td>2</td><td>DBG RX</td></tr><tr><td>3</td><td>DBG TX</td></tr><tr><td>4</td><td>TEL RX</td></tr><tr><td>5</td><td>TEL TX</td></tr><tr><td>6</td><td>GND</td></tr></tbody></table>

#### SPI0 Connector pinout - MOLEX 53261-0671

<table><thead><tr><th width="150">Pin</th><th>Name</th></tr></thead><tbody><tr><td>1</td><td>5V OUT</td></tr><tr><td>2</td><td>SPI0 SCLK</td></tr><tr><td>3</td><td>SPI0 MISO</td></tr><tr><td>4</td><td>SPI0 MOSI</td></tr><tr><td>5</td><td>SPI0 CS0</td></tr><tr><td>6</td><td>GND</td></tr></tbody></table>

**TEL (Telemetry) port:** TTL 3V3, Baudrate 57600

**DBG (Debug) port:** TTL 3V3, Baudrate 9600

### Front

Front side has an integrated fan. It is important to have a clear space to allow for air flow circulation in front of this side.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2Fsync%2F06098ff3d77dd7b2f6a6203e192f97706eb475db.jpg?generation=1613164692117360\&alt=media)

### Right

* Mini HDMI input
* Micro SD card slot
* Camera status LEDs

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2Fsync%2F50e880aff27864537e03bca15ea448318255ae7a.jpg?generation=1613164702200998\&alt=media)

### Rear

USB A connectors for peripherals connection, for instance:

* 4G / LTE modem
* Rockblock satellite communication system
* FLARM ADSB system

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MToXIb7kNu7wl4KdA-r%2F-MToYpgnETBHbmkM71gr%2Fsmartlink-air-rear-side.jpg?alt=media\&token=f676f24d-2527-4a35-ac66-8c2fa7219668)

### Bottom

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2Fsync%2Fc7605dbd44e9e60d0e15aaa7e6943e5383e2c34f.jpg?generation=1613164695766261\&alt=media)

## Ground Module

### Top

The top side has an a heatsink and mounting holes for an optional fan. It's important to have a clear space to allow for airflow circulation in front of this side.&#x20;

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FGdlUTUb5XnltmV4kgKka%2F3.jpg?alt=media&amp;token=5b0441f3-6934-4e11-847b-9f9b1657716e" alt=""><figcaption></figcaption></figure>

### Left

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2F5XICqRNuCoRcQA983KBR%2F7.jpg?alt=media&amp;token=eb2b8f25-ad4b-45db-bbb4-1e5920625e82" alt=""><figcaption></figcaption></figure>

### Front

SMA antenna connectors for antennas

Status LEDs:

* TX: blinking when packets are being transmitted
* RX: blinking when packets are being received
* CPU: module operating
* RSSI: signal quality

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FV4anJ7ndA3g674G026Co%2F6.jpg?alt=media&amp;token=6e2b3e82-e34f-4601-8409-09d6a4ef2ccc" alt=""><figcaption></figcaption></figure>

### Right

* Reset button
* Fan port

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FlmHdeCXZquTHsYWd2dAr%2F5.jpg?alt=media&amp;token=73142c0c-0eb1-418d-a710-008b57f1fd51" alt=""><figcaption></figcaption></figure>

### Rear

* USB to connect to computer / tablet
* Ethernet port (RJ45)
* Power supply, 7-35V DC
* Serial port

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FTNqld4JSOBZd0mFtpFDl%2F4.jpg?alt=media&amp;token=64ea14e2-5500-4986-8df8-ad603a8cf10d" alt=""><figcaption></figcaption></figure>

### Bottom

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FThg8I2DzU8Bv2tswOusy%2F8.jpg?alt=media&amp;token=7c88f45e-9ee5-44d9-b25d-09cdded824a6" alt=""><figcaption></figcaption></figure>

{% hint style="info" %}
Looking for CAD files? Here they are:
{% endhint %}

{% content-ref url="/pages/-MTQeiny65kIZfq2knvm" %}
[CAD Model](/avionics/smartlink/cad-model)
{% endcontent-ref %}


# Set content

Everything you need to setup and start using SmartLink

## Unboxing video

{% embed url="<https://www.youtube.com/watch?v=sGrz3jl88Uk>" %}
SmartLink unboxing video
{% endembed %}

## Set contents

SmartLink set includes everything needed to setup wireless communication for video, telemetry and control. A standard set contains:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0I8vs7-5ZLmiMHH%2Fsmartlink-set-includes.jpg?alt=media\&token=7ff0ecd0-3cad-4837-9540-938cbf600270)

* SmartLink Ground module
* SmartLink Air module
* 2x Air Module antennas
* 2x Ground Module antennas
* CSI camera
* Telemetry cable
* HDMI cable
* Air module power cable
* Ground module power cable

##


# Installation

## Preparing Air module

First of all, attach your antennas to the air module:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0I1wCgPhrmxt31Z%2Fsmartlink-mount-antennas.jpg?alt=media\&token=074d82c0-a413-4f21-a17a-d63456cfcb3d)

{% hint style="danger" %}
WARNING: DO NOT power up any of the modules without antennas! Powering up the modules without antennas may cause malfunction of the amplifier and permanent damage. Powering up without antennas voids warranty.
{% endhint %}

Then attach the power supply cable and autopilot telemetry cables:

* Power supply goes to 5V DC connector
* Autopilot telemetry cable goes to UART connector

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0I2JAHV3TToUzzO%2Fsmartlink-mount-power-autopilot-cable.jpg?alt=media\&token=e39857e1-dae5-4d6c-b0f3-24a0582af684)

What the air module should look like with power and telemetry cables connected:

{% hint style="info" %}
Red cable in the autopilot telemetry cable is 5V power supply from SmartLink to Autopilot. If your autopilot is powered from its own power supply then remove the red cable. In this case you should only used black (GND) and yellow / green (Data TX / RX). By default, the whole cable is supplied without the red cable.
{% endhint %}

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0I5fkcwj30qaemX%2Fsmartlink-mounted-power-autopilot-cables.jpg?alt=media\&token=92d1350f-c7ad-4030-bfd8-86d5269556b0)

Connect CSI camera to camera socket. Use a small sharp tool to unlock the crimp:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0I3UY-9qWQZTYYx%2Fsmartlink-mounted-csi-camera-1.jpg?alt=media\&token=9306670a-41f6-4be8-b87a-9fd41e898c72)

Put the FPC camera cable in and lock the crimp by pushing it. At this stage the setup should look as follows:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0I44Xh_itda5dOX%2Fsmartlink-mounted-csi-camera-2.jpg?alt=media\&token=1be79c02-30c1-429d-9e49-8fafab06dee8)

Connect HDMI camera if desired:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0HgdXJZkF02BD3o%2Fsmartlink-connect-hdmi-camera-1.jpg?alt=media\&token=a8046619-25d1-4b1a-b3da-85be6a8749ae)

The setup should look as follows:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0Hh10wj6QZfe688%2Fsmartlink-connect-hdmi-camera-2.jpg?alt=media\&token=f137e77d-6d1a-477f-b032-6d20be943134)

In this example we demonstrate with a GoPro Hero 6 video camera with 1080p\@60fps video output. [SmartLink](https://sky-drones.com/smartlink) is capable of capturing the following video source types:

* 1080p\@60fps
* 1080p\@30fps
* 720p\@60fps
* 720p\@30fps

## Preparing Ground module

Attach antennas to the ground module:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2Fu3NiY3Hy6ciTIHQqKf5M%2F9.jpg?alt=media&amp;token=6b84952c-b0fd-442f-83f2-cb629399e33d" alt=""><figcaption></figcaption></figure>

By default, 5 dBi antennas come included in the set. Depending on your specific applications you might choose to use alternative antennas designed for 2.4 GHz band.

Connect your micro USB cable and power cable to the ground module as shown below:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2F5eX9L6Hhhw5aRqctisQD%2F10.jpg?alt=media&amp;token=3de45584-b385-4474-9933-db455d82dc47" alt=""><figcaption></figcaption></figure>

{% hint style="info" %}
If you would like to use custom antennas, please contact us [here](https://sky-drones.com/contact-us)
{% endhint %}

## Power supply

Ground module supports any power supply source with a voltage ranging from 10V to 50V. We recommend to use 3S or 4S LiPo battery to power the ground module. The typical current for 3S battery power is around 1A at maximum power output.

Air module is 5V tolerant only. Peak current can be up to 3A, therefore make sure to provide a powerful, stable and reliable power supply to the air module. We highly recommend to use [SmartAP PDB](https://sky-drones.com/power/smartap-pdb.html) 5V output port to power [SmartLink](https://sky-drones.com/smartlink). [SmartAP PDB](https://sky-drones.com/power/smartap-pdb.html) has 5V at 5A max power output which powers [SmartLink](https://sky-drones.com/smartlink) perfectly.

{% hint style="danger" %}
DANGER: AIR MODULE IS 5V-ONLY TOLERANT. POWERING THE MODULE WITH HIGHER VOLTAGE MAY CAUSE PERMANENT DAMAGE TO THE SYSTEM. IT IS HIGHLY RECOMMENDED TO POWER FROM SMARTAP PDB 5V OUTPUT

Please note that warranty is void if air module is powered with a source above 5V.
{% endhint %}

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0HXSzOX4iNgqnt0%2Fsmartlink-air-pdb-connected.jpg?alt=media\&token=89865450-a165-4bdd-b421-2272a6c0ad75)

Connect two power leads to [SmartAP PDB](https://sky-drones.com/power/smartap-pdb.html) 5V output. [SmartAP PDB](https://sky-drones.com/power/smartap-pdb.html) can be powered from 3S-12S LiPo battery. We power it from laboratory power supply for this demonstration (15V).

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0HWgD_2wwLVlf73%2Fsmartlink-air-pdb-closeup.jpg?alt=media\&token=5c3089bf-1276-4a95-8517-dc6ef80ffe0e)

## Autopilot

[SmartLink](https://sky-drones.com/smartlink) system is compatible with any autopilot which has TTL UART telemetry port. For instance, it's compatible with:

* SmartAP Autopilot
* Pixhawk series Autopilot
* APM series Autopilot
* other TTL UART telemetry port autopilots

For this demonstration we use [SmartAP MAX](https://sky-drones.com/smartap-max) Autopilot from Sky-Drones:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0IFTUyisVr91yMa%2Fsmartlink-smartap-max.jpg?alt=media\&token=4aadb9f2-327d-4fee-915a-0d7dc76c88ed)

Connect telemetry cable to Radio port of the autopilot as shown below:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0IEyAFlLbN5PI6N%2Fsmartlink-smartap-max-connected.jpg?alt=media\&token=97935e3a-03c0-4e7d-9ebe-3e23b6fd4372)

After completing the steps above you will have fully assembled air module. Before the first power up, make sure you have assembled air module and ground module as shown below:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0HbS9Cz7P-pnmx2%2Fsmartlink-all-assembled.jpg?alt=media\&token=6fac1ddb-ba81-4a36-94eb-957109fb17b9)

## Initial power up

Power up both ground module and air module.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0HaiZrtenQ0dQSY%2Fsmartlink-all-after-power.jpg?alt=media\&token=32c937fc-f4e3-4eec-8995-0f213b5424a5)

{% hint style="info" %}
It might take up to 15 seconds for both modules to properly boot up and link to each other. By default, modules come pre-configured and paired. Transmission power is set to minimum.
{% endhint %}

Ground module has status LEDs which allows it to identify the current status of the system. The most important LEDs are RSSI:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FZCz6J3CHQcywaRKeA6pg%2F11.jpg?alt=media&amp;token=dc0b6a59-f5b0-4afc-86a6-9a18e88c5030" alt=""><figcaption></figcaption></figure>

* Three RSSI LEDs blinking altogether: RF off
* Three RSSI LEDs blinking in turn: Searching for pair
* One, two or three LEDs solid: RSSI status, more solid LEDs equals better signal

The expected LEDs pattern is as shown below - blinking in turn and then all three LEDs solid:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0HMTZdykOuAa99i%2Fsmartlink-rssi-pattern.gif?alt=media\&token=f11e5cdc-97d7-48b8-a7d8-30fa3170be18)

## Software

### Verify SmartLink was discovered

{% hint style="info" %}
Normally you don't need to run the steps in this section since SmartLink should be recognized automatically. But the steps in this section might be useful for establishing connection if this has not happened automatically.
{% endhint %}

First of all, check if SmartLink ground module has been recognized properly by your computer. You should be able to see it as Ethernet device. For instance, go to the command line and type `ifconfig`  for MacOS / Linux or `ipconfig`  for Windows:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0Hfj6-Ewr8jCBHH%2Fsmartlink-cmd.jpg?alt=media\&token=72d8bf3d-4325-4f15-bbcf-dfc43f28382b)

You should see that one of the network adapters has an IP address in the range of 192.168.168.xxx. This means that SmartLink has been successfully discovered by your computer. Alternatively, you can check the configuration with Network Manager and / or assign a static IP address:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0IIBSTXXERA1aXY%2Fsmartlink-static-ip.jpg?alt=media\&token=57e29ac2-c127-42e1-b53b-e24e1efc599d)

{% hint style="info" %}
Make sure you have configured your WiFi internet connection with the priority higher than the priority of SmartLink ethernet connection. Otherwise, your computer will loose internet connection while SmartLink ground module is connected.
{% endhint %}

Another method to check that SmartLink is properly recognized by your computer is to ping it. Open the command line and type  `ping smartlink.local`. If you are able to see the proper response in the command line then it means SmartLink has been discovered by your computer.

SmartLink is configured with static IP address **192.168.168.100**. For instance, if you're running SmartLink with Android which doesn't support Local DNS - please use static IP address for connecting.

In case you're unable to ping \`smartlink.local\` it might be a DNS problem. In other words, the operating system can't find the IP address' corresponding name. This might happen on some Windows platforms and is applied to all Android based platforms. Follow these steps to resolve it: [Use IP addressing instead of DNS](/avionics/smartlink/troubleshooting#unable-to-ping-smartlink-local-unknown-host)

### Run Ground Station Software

Once you have everything connected and powered up you may start the ground station software. SmartLink is compatible with various popular ground control stations. In this demonstration we use [SmartAP GCS](https://sky-drones.com/smartap-gcs) by Sky-Drones. SmartLink is fully supported by SmartAP GCS. Start SmartAP GCS and go to `Settings` in left hand side menu:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0He_ZqYSGiZzFRl%2Fsmartlink-autoconnect-gcs.jpg?alt=media\&token=180ad091-74fc-4661-95ce-ecd577dbe7da)

Enable the option `Autoconnect to SmartLink`as this will enable SmartLink to automatically connect.

After that, go back to the `World` pane and click the `Connections` button in the top right hand corner. You will see SmartLink connection added. If it's not added automatically, or it is missing completely, you may add it manually as shown below:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0I7BeVCgPHXoSqx%2Fsmartlink-port.jpg?alt=media\&token=72ceffb1-348a-4619-be50-5d087fd5cc6f)

Upon clicking `Open` connection will be established and you should be able to see telemetry information at this step.

To set up the video click on the `Settings` button of the one of the video widgets and select the desired source. For this demonstration we need to select `SmartLink Video 1` option:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0IMOrnutPL11TFj%2Fsmartlink-video-setup.jpg?alt=media\&token=b4efdd4a-2f85-4149-ac7e-ec4e04fe9e32)

After 1-2 seconds the video feed will appear and connection status will be set to `OK`:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0ILkpR1D_DQ_Lv3%2Fsmartlink-video-ready.jpg?alt=media\&token=4a81e8ba-3456-4300-a6e9-588b06222192)

You can easily switch between full map and full video simply by tapping on the video feed you'd like to see in full screen:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0HknlZfsZiXdb8x%2Fsmartlink-full-video.jpg?alt=media\&token=e28048c7-312c-4b83-9017-66770b324bb2)

Finally, the full setup looks as follows:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0Hdx2s-I3GmQnBL%2Fsmartlink-all-in-gcs.jpg?alt=media\&token=cc492a30-c8e9-44c9-82f3-93cbddd0578e)


# Manual Control

SmartLink allows users to transmit a manual control signal from any USB device (e.g. joystick, gamepad or RC radio with USB port) along with other messages when connected to ground control station.

In this demonstration we demonstrate how to setup manual control using FrSky Taranis radio in USB joystick mode. First of all, open [SmartAP GCS](/flight-operations/smartap-gcs) and go to `Settings`.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0Hz5sFbMeb10NHf%2Fsmartlink-manual-gotosettings.jpg?alt=media\&token=59a1e8ae-79d7-47fe-8a78-2e8b63945d95)

Then switch to the `Joystick` tab. Make sure your joystick is connected and selected from the dropdown menu.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0Hyp_-dNcWKGcni%2Fsmartlink-manual-before-set.jpg?alt=media\&token=131050a5-ce7b-4002-bb11-2cd335f49600)

Once you've selected the joystick you will be able to assign the channels according to your preferences. Make sure that `Enable pilot joystick for control` is checked, otherwise manual control messages will not be sent.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0HxMLBQCxTP1e_k%2Fsmartlink-manual-all-set.jpg?alt=media\&token=c293fad8-b4e7-4901-929e-f6ecf2ed26be)

Additionally, you can connect a second joystick which will be used for payload control.

After that, if you go back to the `World` pane you will see a green joystick icon on toolbar. This means that the joystick has been configured successfully and is emitting a manual control signal.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0I-v5mP-t0LgpQB%2Fsmartlink-manual-icon.jpg?alt=media\&token=52974e95-eb85-4abe-8241-fb2ea59cc785)


# Change Settings

## Accessing Settings Menu

SmartLink has various settings which you may change to optimize the performance. To get to [SmartLink](https://sky-drones.com/smartlink)'s settings menu click on the Wireless Connection icon on top toolbar:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0IBbW8VufEC3coa%2Fsmartlink-settings-icon.jpg?alt=media\&token=8205d50c-8bc6-439f-95fa-eabce3e85816)

## Changing Radio settings

Radio tab allows you to change radio settings as well as observe current RSSI and SNR values for connection.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0ICGkk1gI8Hd4Na%2Fsmartlink-settings-rf.jpg?alt=media\&token=5a8df5d9-4ec3-4369-8cae-15f225e7879b)

* SNR - Signal Noise Ratio, the ratio of signal power to the noise power, expressed in decibels.
* RSSI - Received Signal Strength Indication, a measure of the energy observed by an antenna when receiving a signal

{% hint style="info" %}
It's recommended to keep output TX power for both air and ground module at low values when working with the system on the ground. 7 dBm is the minimum and recommended value. Use higher values when flying. Using high values over long periods of time near the human body might cause health problems due to radiation.
{% endhint %}

After changing any parameter click `Save`. It might take a few seconds to save changes applied. The system may loose connection when changing any parameter.

## Changing Security settings

Security tab allows you to assign network name and encryption key. Connection is AES encrypted.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0IAOVpmFVSfo9RP%2Fsmartlink-settings-ap.jpg?alt=media\&token=8a37323e-81fa-4ccf-aa3d-25588adc08b6)

{% hint style="info" %}
Make sure that both air and ground modules have the same network name and encryption key. Otherwise, the modules are not considered to be paired and won't connect to each other.
{% endhint %}


# API and SDK

[SmartLink](https://sky-drones.com/smartlink) system allows real time HD video, telemetry and control from one unmanned system. [SmartLink](https://sky-drones.com/smartlink) features are fully integrated into [SmartAP GCS](/flight-operations/smartap-gcs) and are compatible with most of the popular ground control station software such as QGroundControl, Mission Planner, etc.

Find out more on using SmartLink with other GCS devices here: [SmartLink with other GCS](https://github.com/aviaks/Sky-Drones-Docs/tree/afc9473ad52bff56c4bd76b506f26e86b52cd0d9/smartlink/other-gcs/README.md)

Thanks to Sky-Drones' extensive API on the system, users can take advantage of its features in any third party software too!

## Telemetry

To access telemetry on the ground module use the following connection:

* Type: UDP&#x20;
* Host: smartlink.local&#x20;
* Port: 14555

[SmartLink](https://sky-drones.com/smartlink) will forward all autopilot telemetry to this port.

There are two other connections available for interacting with onboard computers, other peripherals and 3rd party applications:

First:

* Type: TCP&#x20;
* Host: smartlink.local&#x20;
* Port: 14556

Second:

* Type: UDP&#x20;
* Host: smartlink.local&#x20;
* Port: 14557

## Video

To access the video on the ground module use the following address:

* Type: RTSP&#x20;
* HDMI Input 1: rtsp\://smartlink.local:8554/camera/0&#x20;
* HDMI Input 2: rtsp\://smartlink.local:8554/camera/1

To check the video stream using a standard GStreamer pipeline use the following command:

```
gst-launch-1.0 rtspsrc location=rtsp://smartlink.local:8554/camera/0 ! rtph264depay ! avdec_h264 ! autovideosink sync=false
```

## Manual Control

Manual control comes as a part of other MAVLink telemetry messages. `MANUAL_CONTROL` message from MAVLink specification is recommended but not exclusive. You may use any manual control messages according to your specification. [SmartLink](https://sky-drones.com/smartlink) will act as a transparent transfer layer just like any other telemetry module.


# Other AP / GCS Support

## QGroundControl

Follow these next steps to configure QGroundControl for [SmartLink](https://sky-drones.com/smartlink):

{% embed url="<https://www.youtube.com/watch?v=nbthu_aaUGg&feature=emb_title>" %}

### Configuration settings

* Connection type: UDP
* Host: smartlink.local
* Port: 14555
* Autopilot UART: 57600 8N1 3V3 TTL

## Mission Planner

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0I0nGEF2fdOC-XF%2Fsmartlink-mission-planner.jpg?alt=media\&token=ff8f377c-4b9f-446d-b044-e6b2e1e5850d)

### Configuration settings

* Connection type: UDP
* Host: smartlink.local
* Port: 14555
* Autopilot UART: 57600 8N1 3V3 TTL

### Telemetry

Make sure to select UDPCI as the connection type and click Connect:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MaeWJvLIyV_KnHxgQEo%2F-MaeWX_ZzgOMh7GANUmc%2Fimage.png?alt=media\&token=d75673a5-b547-4f7c-be4c-938003ba8826)

Type in SmartLink IP address (192.168.168.100) or host name (smartlink.local) and click OK:

<div align="center"><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MaeWJvLIyV_KnHxgQEo%2F-MaeWvC-ElcL8ZyTlXS6%2Fimage.png?alt=media&amp;token=2a318c12-ae88-4ecc-83d1-3fa23788a1d2" alt=""></div>

Type in SmartLink port number (14555) and click OK:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MaeWJvLIyV_KnHxgQEo%2F-MaeX8ZHEEnMfLiEyuZh%2Fimage.png?alt=media\&token=90f1e018-eb4c-4ce0-836b-04ac957e8933)

The connection will be established and Mission Planner will start reading parameters:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MaeWJvLIyV_KnHxgQEo%2F-MaeXaAiNQD5p1RDZUZy%2Fimage.png?alt=media\&token=d8117db9-b50d-4bd2-a793-c9a75271dd99)

### Video

Right click on the primary flight display and select Video > Set GStreamer source:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MaeWJvLIyV_KnHxgQEo%2F-MaeYEkZjsnMjqtDC_vR%2Fimage.png?alt=media\&token=1c43e11a-bae4-4ebf-8510-85e91b551649)

Use the following GStreamer pipeline to start the real time video in Mission Planner:

```
rtspsrc location=rtsp://smartlink.local:8554/camera/0 ! rtph264depay ! avdec_h264 ! videoconvert ! video/x-raw,format=BGRA ! appsink name=outsink sync=false
```

{% hint style="warning" %}
In case your system doesn't support local DNS (smartlink.local addressing) you will need to change smatlink.local to the static IP address of SmartLink: 192.168.168.100
{% endhint %}

Click OK to start the video feed:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MaeWJvLIyV_KnHxgQEo%2F-MaeXnvmX1ByGQORyLBT%2Fimage.png?alt=media\&token=a0f2ad72-ef0c-459d-b967-07730146db4b)

After a few seconds the video feed will appear:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MaeWJvLIyV_KnHxgQEo%2F-MaeXzXd8jQU5r3wJwDW%2Fimage.png?alt=media\&token=988a399a-57d9-4454-b673-52439c575e5a)


# Firmware Update

## Using Ubuntu:

### Get USB Boot Utility (only needs to be done once)

First of all, you will need USB boot utility which will force the system transition into bootloader state.

Download the USBBoot tool here: [USBBootTool](https://github.com/aviaks/Sky-Drones-Docs/tree/afc9473ad52bff56c4bd76b506f26e86b52cd0d9/smartlink/downloads/smartlink-usbboot.zip)

{% file src="/files/-MZria9MfQ56S33NICYc" %}

### Force SmartLink Bootloader Mode

Once you have the boot tool, let's start it and flash the firmware.

* Open command line and locate USBBoot
* Start bootloader tool

  `sudo ./usbboot`
* Connect USB cable, turn on power supply (make sure to connect USB cable before providing power)
* After a few seconds the terminal will show that bootloader mode has been successfully enabled. Then you can proceed to flashing or saving the image file

### Flash SmartLink Image from File

* Enable bootloader mode as described in the steps above
* Use `lsblk` or `df -h` to find out the mounting point of the unit (look for 3.9GB unit since eMMC of SmartLink has this amount of flash memory)
* Locate the firmware file
* To flash image from file (make sure to set correct filename and sdX):

  `gunzip --stdout IMAGE_NAME.img.gz | sudo dd bs=4M of=/dev/sdX status=progress`

Upload process may take up to 15 minutes. Progress will be displayed on the screen.

{% hint style="info" %}
&#x20;After upload process is complete, power off SmartLink before disconnecting the USB cable.
{% endhint %}

### Save Current SmartLink as Image to File

You can save the entire eMMC of [SmartLink](https://sky-drones.com/smartlink) to image file and later flash this to another [SmartLink](https://sky-drones.com/smartlink) unit. Please follow these steps:

* Enable bootloader mode as described in the steps above
* Use `lsblk` or `df -h` to find out the mounting point of the unit (look for 3.9GB unit since eMMC of SmartLink has this amount of flash memory)
* To save currently installed image to file (make sure to set correct sdX):

  `sudo dd bs=4M if=/dev/sdX status=progress | gzip > smartlink.img.gz`

{% hint style="info" %}
&#x20;After download process is complete, power off SmartLink before disconnecting the USB cable.
{% endhint %}

## Using Windows / MacOS:

### Get Boot Tool utility for forcing the bootloader

Please ensure you are not writing to any USB devices whilst the installer is running.

1. Download and run the [Windows installer](https://github.com/raspberrypi/usbboot/raw/master/win32/rpiboot_setup.exe) to install the drivers and boot tool.
2. Once the driver installation is complete, run the exe tool that was previously installed.
3. Plug micro USB cable into the micro USB socket marked `USB` on SmartLink.&#x20;
4. Plug the other side of the USB cable in your computer.&#x20;
5. Power up SmartLink. It's important to plug in the USB cable first and only then power up SmartLink.
6. After a few seconds, the SmartLink eMMC will pop up under Windows as a disk (USB mass storage device).

### Get balenaEtcher for flashing the image

1. Download the Windows installer from [balena.io](https://www.balena.io/etcher/)
2. Run balenaEtcher and select the SmartLink OS image file
3. Select the correct storage drive (SmartLink)
4. Finally, click **Burn** to write the SmartLink OS image
5. You'll see a progress bar. Once complete, power down SmartLink first and only then unplug the USB cable.

### Recovery procedure

If your [SmartLink](https://sky-drones.com/smartlink) unit is not responding and you think eMMC might be corrupted / the device seems to be bricked, you will need to re-flash the image to eMMC. Please contact us [here](https://sky-drones.com/contact-us) and we'll provide you with the link to the latest SmartLink image file.

### Recovery images

Click below to download the recovery image. Make sure to the select the one which suits your SmartLink version:

* [SmartLink with CSI and HDMI](http://sky-drones.com/downloads/smartlink-csi.img.gz)
* [SmartLink with HDMI and HDMI](http://sky-drones.com/downloads/smartlink-hdmi.img.gz)


# Troubleshooting

## Unable to detect LAN network from ground module

In case you can't see that the LAN network from ground module was detected and established, then you would need to install the driver:&#x20;

{% file src="/files/-Mgu9AjnxhSX52AhxL3w" %}
LAN Driver - Windows 8.1
{% endfile %}

{% file src="/files/-Mgu96e6ohtUxKNXBs2L" %}
LAN Driver - Windows 10
{% endfile %}

{% file src="/files/-Mgu8MJ7KKYkGRSQNKUH" %}
LAN Driver - Linux
{% endfile %}

{% file src="/files/-Mgu8G0mbx8Uz0ThjkOm" %}
LAN Driver - Mac OS
{% endfile %}

You can find the latest drivers from Realtek available [here](https://www.realtek.com/en/component/zoo/category/network-interface-controllers-10-100m-fast-ethernet-usb-2-0-software).

{% hint style="info" %}
In some cases you might need to disable ’system integrity protection’ and then instal the driver For instance, [here](https://www.youtube.com/watch?v=Je7Byy7lYrs) is the demo video on how to disable SIP on Mac OS.
{% endhint %}

## Unable to Ping smartlink.local - Unknown Host

Some operating systems might not have local DNS, resulting in the inability to access the system using the name (`smartlink.local`). This is known for all Android platforms and some Windows platforms. In case you can't ping `smartlink.local` or similar:

> ping: cannot resolve smartlink.local: Unknown host

You'll need to find out the IP address for SmartLink. There are numerous ways to do this, we'll use the NMAP tool in this example. First of all, download and install NMAP tool using the relevant links below:

### Linux

```
sudo apt-get install nmap
```

### Mac OS

```
brew install nmap
```

### Windows

Go to the official website for NMAP tool: [Nmap web page](https://nmap.org/download.html)&#x20;

Select `Latest stable release self-installer: nmap-7.80-setup.exe` or similar. Download and install it.

Make sure to select `Install Npcap in WinPcap API-compatible mode` during the installation.

After installation is complete, open command line and go to NMAP folder:

```
cd "C:\Program Files (x86)\Nmap"
```

### Looking up SmartLink's IP Address

Execute IP addresses scan within the required range, in our case it will be:

```
nmap 192.168.168.*
```

As a result of this command you'll see IP addresses in this range. You'll have 192.168.168.1 which is, as a rule, configured as air module, 192.168.168.2 which is usually configured as ground module and 192.168.168.x (x: 0-255) which is the IP address for SmartLink. You should use this IP address - 192.168.168.x for direct connection instead of smartlink.local.

## No Internet Connection when SmartLink is Plugged into USB Port

Sometimes you might not be connected to the internet after SmartLink is plugged into the USB port and detected. SmartLink is identified as LAN connection and sometimes the operating system expects this to be a primary connection for accessing the internet. It is in fact not. You still have to use your LAN / WLAN for internet access and this has to be set in the operating system.

Do the following actions to enable internet access while SmartLink is connected:

### Windows

Follow the steps from this tutorial to change the MTU value for network connections:

<https://www.windowscentral.com/how-change-priority-order-network-adapters-windows-10>

A lower MTU value means higher priority for the interface. Therefore, you need to have the MTU value set lower for your LAN / WLAN network than for SmartLink networks

### Linux

Open command line and execute the following command:

```
sudo ip route del default
```

### Mac OS

Go to network connections menu and make sure that the Service Order is set higher for your LAN / WLAN connection but not SmartLink:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0IJkcZL3m0bB1iF%2Fsmartlink-troubleshooting-no-internet-mac.jpg?alt=media\&token=c30a408d-2efb-45d6-9378-c56393739f9e)


# Installation hints

## Antenna Orientation

Orientation of the antennas is vital. Ground module has high gain 5 dBi antennas with a vertical plain radiation pattern is \~40 degrees. Therefore, antennas on the ground module should be placed vertically. If you want the system to be less reliant on antenna orientation then antennas should be changed to lower gain antennas (2-5 dBi). They will yield a lower range but will be less dependent on the orientation of antennas.&#x20;

The image below demonstrates the relation between antenna gain, radiation pattern and range:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQnXKgRGL8mlJDTh-v%2F-MTQoCnVffXYJhUL6Fl9%2Fsmartlink-antennas.png?alt=media\&token=ad538cc9-2a9c-4916-8188-cb92a1d79582)

For a solid connection the copter should stay in the blue area. In this example, the range is anywhere in the 2 dB antenna blue circle. 9 dB antenna has a reduced area but a longer range for certain directions. Same rules are applied to antennas on copters, whose antennas are 3 dBi by default and should be placed vertically down (cable from antenna facing up to the sky). Another thing to consider for longer range - ground module should be placed higher off the ground. At least one meter is required but there is a significant difference between 1 meter and 2 meters off the ground; the higher the better! 1.50 - 2.00 meters is recommended.

## Frequencies

The system operates at 2.4 GHz, therefore, it's recommended to keep 2.4 GHz band free from other devices.&#x20;


# CAD Model

Download STEP files of [SmartLink](https://sky-drones.com/smartlink) for integrating into your own design:

{% file src="/files/-MTQhganulk8DxKWwrgS" %}
SmartLink Air Module STEP
{% endfile %}

{% file src="/files/-MTQhsx7YJQA7LnK1O8W" %}
SmartLink Ground Module STEP
{% endfile %}

{% hint style="success" %}
Would you like to manufacture your own SmartLink? Would you like to license the hardware design?&#x20;

Please get in touch with us [here](https://sky-drones.com/contact-us).
{% endhint %}


# Certificates

SmartLink has the required RF compliance certificates.

{% hint style="success" %}
Please contact us [here](https://sky-drones.com/contact-us) for certificates pack.
{% endhint %}


# FAQ

A selection of FAQs asked by our customers.

## When will SmartLink be available to purchase?

SmartLink is already available! Just go to the [Sky-Drones website](https://sky-drones.com/) and head to the [online store](https://sky-drones.com/sets) section where you can find the full range of Sky-Drones products, including the SmartLink set.

## Where can I find the product description?

This can be found on our website. For a generic product description, head to the [SmartLink product page](https://sky-drones.com/smartlink). If you cannot find what you are looking for, we have a detailed description and setup instructions in our [online documentation](https://docs.sky-drones.com/)**.**

## Is there PDF documentation available for SmartLink?

Whilst we do not have a dedicated PDF document, we do have the online portal that holds all the detailed documentation for the entire range of Sky-Drones products. All this documentation can he found [here](https://docs.sky-drones.com/)**.**&#x20;

## How can I connect cameras to SmartLink?

SmartLink has 2 camera ports, 1 is CSI and 1 is HDMI. The CSI camera is included in the SmartLink set for your convenience, so camera connections are initiated by simple plug-and-play technology.&#x20;

## What about the software? How can I use the mission computer?

Our software is easy to access, set up, and configure. However we are more than happy to work with our partners and customers to provide a full step-by-step system setup. You can count on the support of the development team if you have any questions regarding software use, just drop us an email and we'll get back to you or schedule a call to talk you through it: **<info@sky-drones.com>.**&#x20;

## **What is the achievable range with SmartLink?**

It is possible to achieve an unlimited flight range with SmartLink. This depends on a variety of independent variables such as the antennas, instillation, environmental conditions, etc. but for example:

* When using CE regulations which are 20dBm/100mW, the range would be between 4km and 6km
* When using FCC which assumes 20dBm, you can reach up to 20km in range

## How do I achieve an unlimited flight range?

For a range beyond 20km, we recommend using LTE connectivity as this has an unlimited range providing the drone remains in the LTE coverage area. If there is no 4G coverage you can use higher range antennas which will aid in extending the range for up to several dozen kilometres. These can be purchased from our [online store](https://sky-drones.com/telemetry).

## What is Sky-Drones' manufacturing capability?

This is completely dependant on your requirements, but as a base point we can easily manufacture SmartLink units in the hundreds per month. Is it possible for us to manufacture the units in the thousands per month with prior notification from our clients. [Get in touch](https://sky-drones.com/contact-us) to find out more.

## Where is SmartLink manufactured?

SmartLink, and all hardware product in the Sky-Drones product range, are manufactured in a UK factory to ensure a high-quality product and production process throughout. Our materials come from specialised and certified vendors that we are proud to be doing business with.

## Is it possible for clients to manufacture their own SmartLink units?

In short, yes. If you are a large volume manufacturer, Sky-Drones can help you with setting up licensing, materials, and the production processes to manufacture SmartLink yourself inhouse. It could save you time, resources, and money to do this so if it is something you are interested in, [get in touch](https://sky-drones.com/contact-us) with us to discuss your needs.


# SmartAP PDB

## Introduction

SmartAP PDB (Power Distribution Board) allows users to transfer power from the battery to ESCs / motors, and generate a power supply for the flight controller and other peripherals with different voltage levels.&#x20;

PDB provides the functionality for battery voltage / current measurements. SmartAP PDB makes high-power line connections easier and much more reliable.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPuokbc4dJogcyVlyG%2F-MTPvkkNDL5CE3ih6esF%2Fsmartap-pdb-header.jpg?alt=media\&token=2d34be9c-5ec5-4ab1-aae9-55a168afadfe)

## Features

* Size: 65x65 mm, 4no. 3mm mounting holes&#x20;
* Input voltage up to 60 Volts (14S)
* Capability to handle extremely high currents (peak current up to 400A)
* Power input from the main battery, possibility to connect up to 4 independent batteries
* 12 pairs of pads (6 top, 6 bottom) for powering up to 12 motors (all possible airframe configurations supported)
* Integrated voltage and current sensors
* Integrated DC-DC converter from 10-60 V input (up to 14S battery) to 5V output to power peripherals, max output current 5A&#x20;
* Integrated DC-DC converter from 10-60 V input (up to 14S battery) to 12V output to power peripherals, max output current 5A
* 5V and 12V power output terminals (standard 2.54mm/0.1" connectors)
* Integrated loud electromagnetic sounder (buzzer)
* Power output for the flight controller (both 5V and battery VIN)
* Fully compatible with all [SmartAP Autopilots](/avionics/legacy-autopilots)

For further information, please refer to the [installation](/avionics/smartap-pdb/installation) section.

## Manufacturing process

At Sky-Drones, we pay extremely high attention to the design of our hardware including manufacturing, inspection and quality control. The reliability of your drone is directly affected by the quality and reliability of the hardware inside, so it's our responsibility to you to take extra are. Take a look at the video below: it demonstrates the essential steps in our hardware production process in our UK factory before being shipped worldwide to our customers.

{% embed url="<https://www.youtube.com/watch?v=oP77vW-1cWs&t=14s>" %}


# Installation

SmartAP PDB (Power Distribution Board) is used for batteries and ESC connection. The board has integrated voltage and current sensors, buzzers, and 5V and 12V outputs.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPuokbc4dJogcyVlyG%2F-MTPvu37yN1CvU7JEow9%2Fsmartap-pdb.jpg?alt=media\&token=e56d4235-12d9-4da1-bd9d-52d06ae9a538)

## High input voltage recommendations

{% hint style="warning" %}
**WARNING:** When input voltage is higher than +35V (8S+ battery) then it's strongly required to attach Aluminum Electrolytic Capacitor to the power input pads with the rating of at least 100 uF / 100V.&#x20;

Recommended part number: B41851A9227M000 or similar specs
{% endhint %}

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FMEKMLNJszLr8D17BwCPo%2FIMG_0505.JPG?alt=media&amp;token=4fa4146a-8c77-49d9-89eb-4872d6e5692f" alt=""><figcaption><p>Input capacitor in parallel to the main power input</p></figcaption></figure>

## Pinout

The SmartAP PDB pinout diagram is shown below. The larger pads in the rear side are intended for the main battery connection. Up to 4 independent batteries can be connected using the thick wires (e.g. 8-10 AWG). The thick wires are essential to be able to handle high current loads. Both top and bottom, and left and right sides have pads for a ESC power supply connection. Therefore, up to 12 ESCs can be connected.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPq3By6MenBW7BTo12%2F-MTPsbdOA5BWrIVS7V7h%2Fsmartap-pdb-v1-pinout.png?alt=media\&token=37ab18e4-8cb9-484c-b3c9-0a49d36c5601)

## Soldering

{% hint style="info" %}
**NOTE:** It's strongly recommended to use a powerful solder iron (at least 80W). A weaker soldering iron produces a high chance of a cold joint which can significantly reduce the reliability of the elements.
{% endhint %}

Soldered Power Distribution Board should look as follows:

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPq3By6MenBW7BTo12%2F-MTPsbdLt7JOinxzT505%2Fpdb-escs-supply.png?alt=media&amp;token=f375b78b-8dd2-4c2a-a075-0b26d945f33d" alt=""><figcaption></figcaption></figure>

## Powering the autopilot

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPq3By6MenBW7BTo12%2F-MTPsbdJPVUEiIQtV3Yn%2Fpdb-connections.png?alt=media\&token=e581652a-9ea9-44b1-a360-0b12efc9fda0)

#### SmartAP PRO

[SmartAP PRO](https://sky-drones.com/smartap-pro) autopilot is capable of receiving power directly from the main battery, therefore, specially dedicated solder terminals can be used. If you require the autopilot to receive the current sensor (integrated in PDB) readings, simply connect the `GND`, `5V`, `CURRENT` signals of the PDB using a standard cable to the flight controller.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPq3By6MenBW7BTo12%2F-MTPsbdNbiCIzxk8THWy%2Fpdb-smartap-v3-connections.png?alt=media\&token=02d20f2d-9d2d-4769-b900-93aa769487c8)

{% hint style="warning" %}
**WARNING:** SmartAP gets power directly from the PDB which is connected to the main battery, therefore, supply voltage is the same as your battery voltage. This means that it can be up to:

* 36V (8S) for SmartAP 3.0
* 36V (8S) for SmartAP 3.1
  {% endhint %}

#### SmartAP MAX

SmartAP MAX gets its power and voltage / current readings from the PDB using a standard 6-pin cable with Molex PicoBlade connectors. Simply connect the cable to the `PWR` connector of the autopilot.

### Buzzer support

SmartAP PDB has an integrated electromagnetic buzzer (sounder) which is used for audio notifications, alerting users to the system status. Simply connect the `BUZZER` and `GND` signals of the flight controller to `BUZZER` and `GND` signals of the PDB.

### Voltage and current sensors

SmartAP PDB has integrated voltage and current sensors. The current sensor is located on the bottom side of the PDB. For the correct scale / offset configuration, please [contact us ](https://sky-drones.com/contact-us)now and we'd be happy to help!

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPq3By6MenBW7BTo12%2F-MTPsbdKRgLbrgaXypfi%2Fpdb-current-sensor.png?alt=media\&token=e20f483a-33ee-4843-acc3-53ad29d9c583)


# SmartAP GNSS

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPq3By6MenBW7BTo12%2F-MTPsXEg0EF8KbPLCowX%2Fgnss-top-slider.jpg?alt=media\&token=f90e2593-d722-4fd3-8f5d-493ab5c3f7ba)

{% content-ref url="/pages/-MTPsFsW0j8zT21rqoY7" %}
[Standard GNSS](/avionics/smartap-gnss/standard-gnss)
{% endcontent-ref %}

{% content-ref url="/pages/-MTPsBDOSHEhV3QWFIfh" %}
[RTK GNSS](/avionics/smartap-gnss/rtk-gnss)
{% endcontent-ref %}


# Standard GNSS

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPq3By6MenBW7BTo12%2F-MTPsXEg0EF8KbPLCowX%2Fgnss-top-slider.jpg?alt=media\&token=f90e2593-d722-4fd3-8f5d-493ab5c3f7ba)

## Specifications

SmartAP GNSS is a compact GPS/GLONASS module with an integrated active antenna, UBlox Neo-M8N chipset and 3-axis magnetometer (compass). Fully compatible with [SmartAP Autopilots](/avionics/legacy-autopilots).

## Features

* UBlox NEO M8N chipset based
* Integrated SAW and LNA
* 25mm ceramic patch antenna
* GPS / GLONASS support
* Up to 24 satellites
* 18 / 10 Hz update rate (GPS / GPS + GLONASS)
* Rechargeable 3V lithium backup battery
* Ultra-Low noise 3.3V regulator
* Power and fix indicator LEDs
* Exposed RX, TX, 5V and GND pads
* Integrated magnetometer - HMC5883L
* Footprint for pressure sensor - MS5611-01BA03
* UART port for GPS interface
* Diameter 75 mm
* Weight 18g
* Fully compatible with [SmartAP Autopilots](/avionics/legacy-autopilots)

## Package includes

* GNSS module
* Connection cable

## Dimensions

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPq3By6MenBW7BTo12%2F-MTPsXEkSZRyhltoiDik%2Fsmartap-gps-v2-dimensions.png?alt=media\&token=323eac73-d55f-4fd5-a769-9f34d73583ec)


# RTK GNSS

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPuokbc4dJogcyVlyG%2F-MTPwILQ3XEywiOFHEJc%2Frtk.jpg?alt=media\&token=86ec1b3a-a58b-44ef-a72e-004780d4f5a5)

## Specifications

This GNSS (GPS + GLONASS) module is base on RTK technology and was specially developed for [SmartAP Autopilot](/avionics/legacy-autopilots) and is intended to be used in applications where precise positioning really matters. It's based on the latest and most precise UBlox Neo M8P chipset which provides outstanding position accuracy. The set includes a base station module with external active patch antenna, an airborne module with integrated patch antenna, and a set of cables.

{% hint style="info" %}
Real Time Kinematic (RTK) satellite navigation is a technique used to enhance the precision of position data derived from satellite-based positioning systems (global navigation satellite systems, GNSS). It uses measurements from a phase of the signal carrier waves, rather than the information content of the signal, and relies on a single reference station or interpolated virtual station to provide real-time corrections, providing up to centimetre-level accuracy.
{% endhint %}

## Features

* Centimeter‑level GNSS positioning
* Integrated Real Time Kinematics (RTK)
* Smallest, lightest, and energy‑efficient RTK module
* Complete and versatile solution due to base and rover variants
* World‑leading GNSS positioning technology
* UBlox NEO M8P chipset based
* 25mm ceramic patch antenna
* GPS / GLONASS support
* Up to 24 satellites
* 18 / 10 Hz update rate (GPS / GPS + GLONASS)
* Rechargeable 3V lithium backup battery
* Ultra-Low noise 3.3V regulator
* Power and fix indicator LEDs
* Exposed RX, TX, 5V and GND pads
* Integrated magnetometer on airborne module - HMC5883L
* UART port for GPS interface
* USB for base station module
* Airborne module cable length 30cm
* Fully compatible with [SmartAP Autopilots](/avionics/legacy-autopilots)

## Package includes

* Base station module
* Active patch antenna for base station module
* Airborne module with integrated patch antenna
* Connection cable


# Updating GNSS Module

In the event there is a need to update the configuration of GNSS receiver, this can be done for both airborne and ground module (RTK GNS). The latest configuration files, as well as the configuration tool, can be found in the downloads section on the Sky-Drones website <http://sky-drones.com/dload>

## Getting U-Center

First of all you need to download and install UBlox U-Center utility. After completing the installation, run the program.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndChVrYWU9hjkMFj%2Fsmartap-gps-ucenter1.png?alt=media\&token=b08f7af5-f55f-40bd-82a6-f9d5e0ae160e)

## RTK GNSS Configuration update

Plug in RTK GNSS Module to the USB port of your computer and make sure that the green LED is solid (NOT flashing).

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2Fsync%2Fdbd96eae6dba859187289c3f37e64d868131f873.png?generation=1613210598659268\&alt=media)

Go to U-Center utility and set up the connection in the top-left corner: choose the right COM port and set the baud rate to 115200.

Then go to `Tools` > `GNSS Configuration` and select the configuration file. Set`Store configuration into BBR / Flash` checked.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCiEZEnfihf2hfI%2Fsmartap-gps-ucenter2.png?alt=media\&token=d24459bb-d084-4579-afa6-b7adfbaaaa06)

Press `File > GNSS` button, the update process should start.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCjuBqRyRgnA4mI%2Fsmartap-gps-ucenter3.png?alt=media\&token=e0ddd186-3a50-49e3-b699-80790bd71296)

If the messages dialog closes itself and you cannot see any error messages or reports, this means that the configuration of the GPS receiver has been successfully updated.

## SmartAP PRO Onboard GNSS module update

Connect your FTDI cable to the GPS port of the flight controller as follows:

* `GND` <-> `GND`
* `TX` <-> `RX`
* `RX` <-> `TX`

Do NOT connect 5V and/or power supply pin from FTDI cable to the flight controller! Flight controller will get the power from the USB cable. Set the boot switch in UPD (“Update”) mode, connect your USB cable to the flight controller and connect the FTDI cable to your computer. Your setup should look as follows: !\[]\(../.gitbook/assets/smartap-gps-ftdi.png)&#x20;

Once connected, proceed with the update steps described above.&#x20;

Troubleshooting: if it seems that there is no connection to the GPS module, try changing the TX and RX pins of the FTDI cable connected to your flight controller. Note that sometimes the colours changing means the elements have been swapped.

Do not forget to put the switch back to the RUN position!


# CAD Model

Download the STEP files of SmartAP GNSS to integrate it into your own design:

{% file src="/files/-MTQj\_wpPFzTKsqjwvNm" %}
SmartAP GNSS
{% endfile %}

{% file src="/files/-M\_5U4FlvZY8EAi55\_sm" %}
SmartAP GNSS Internals (no enclosure)
{% endfile %}


# Legacy autopilots

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPy6SZYbfFcNnMgw_n%2F-MTPzDtYNA8Cfl-IA4df%2Fpro-max.jpg?alt=media\&token=3f47b059-a408-4b54-9f27-249be86c7e0f)

SmartAP PRO and SmartAP MAX are Sky-Drones' flagship flight controllers.&#x20;

{% content-ref url="/pages/-MTQ6P2\_0jyilt-2q6zj" %}
[SmartAP PRO](/avionics/legacy-autopilots/pro)
{% endcontent-ref %}

{% content-ref url="/pages/-MTQ5se3ThdAHHyhdMwy" %}
[SmartAP MAX](/avionics/legacy-autopilots/max)
{% endcontent-ref %}


# SmartAP MAX

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ9gzbV3YGK7fZXBuj%2F-MTQA2tUUyIWvcqK5kxA%2Fsmartap-max-intro.jpg?alt=media\&token=3712b3df-0fc7-4d74-9e9d-9e31e2772fba)

SmartAP MAX Autopilot is the latest generation flight control system for multirotor Unmanned Aerial Vehicles of various configurations and sizes aimed at a wide range of applications.&#x20;

The main feature of the system is its capability of fully autonomous flight including take off, waypoints flight, landing and much more. The core is based on a powerful 32-bit microcontroller ST Microelectronics® STM32F4 and 9-axis Inertial Measurement Unit. The latest UBlox® GPS module with integrated 3-axis magnetometer and pressure sensor can be connected externally for autonomous flight capabilities as well as possessing a wireless telemetry module for system configuration, mission planning and control, and in-flight monitoring via the purpose-designed SmartAP Ground Control Station and Configuration Tool.&#x20;

SmartAP MAX supports any type of multirotor UAV with outstanding flight performance, reliability, navigation and control precision. Its compact size and weight makes integration of the system fast and easy, and its various I/O interfaces allows the creation of applications for interaction with 3rd party electronics and payloads.

## Included in your Set

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hY3Us85Up4Y1d-%2Fsmartap-max-set-content.jpg?alt=media\&token=4f0eae11-7e53-44c9-8a75-1c6098fc5743)

1. SmartAP MAX flight controller
2. GPS / GLONASS satellite navigation module with integrated 3-axis magnetometer
3. Telemetry kit (air and ground module with antennas and connection cable)
4. DC-DC Power module and current / voltage sensor
5. MicroSD card with adapter
6. Electromagnetic sounder

## Description

### Flight performance

* Extremely stable flight in stabilize (user control), position hold (semi-autonomous control) and autonomous (navigation and control) modes&#x20;
* Vibration dampened multiple redundant temperature stabilized IMU
* Aluminium case for EMI protection
* Native support of SmartAP Ground Control Station and Configuration Tool&#x20;
* Accurate GPS position hold (up to 40cm), accurate altitude hold (up to 10 cm)
* Fully autonomous waypoints flight&#x20;
* Return to home mode&#x20;
* Failsafe detection and event triggering&#x20;
* Plus much more...

### General

* Powerful microcontroller 32 bit 168 MHz STM32F4 ARM Cortex M4&#x20;
* Compatible with GPS/GLONASS receiver (UBlox® NEO8, GPS/GLONASS, up to 24 sats, 10 Hz) active antenna&#x20;
* Integrate OSD (On-Screen Display)
* Up to 12 PWM I/O support (5V out)&#x20;
* USB interface for configuration / firmware update&#x20;
* Various communication lines (UART, I2C, SPI)&#x20;
* MicroSD, 4-bit SDIO interface for data-logging / parameters storage&#x20;
* Backup battery for RTC&#x20;
* 2x ADC inputs for battery voltage / current monitoring&#x20;
* Electromagnetic sound audio indicator&#x20;
* 3-channels LED support (up to 500mA / ch)&#x20;
* 2-channels solid state relay&#x20;

### Processor

* ST Microelectronics STM32F427VI&#x20;
* 32 bit 168 MHz ARM Cortex M4&#x20;
* Hardware FPU
* 2 MB Flash
* 192 kB RAM    &#x20;

### Sensors

* Vibration dampened multiple redundant temperature stabilized IMU
* 2x 9-axis IMU InvenSense MPU-9250 (accelerometer, gyroscope, magnetometer)&#x20;
* 2x Pressure sensor MS5611 (integrated and external)&#x20;
* 1x 3-axis magnetometer HMC5883 (external)&#x20;
* 1x UBlox® M8N GPS module (external)&#x20;

### Flight Modes

* Stabilization
* Altitude hold
* GPS position hold
* Loiter
* Return to home
* Autonomous waypoints flight
* Guided / follow me
* Take off
* Landing

### Interfaces

* 12x PWM I/O&#x20;
* 1x PPM / SBUS input&#x20;
* 1x SBUS output&#x20;
* 1x power input port&#x20;
* 1x LED output port&#x20;
* 3x UART&#x20;
* 2x I2C&#x20;
* 1x SPI&#x20;
* 2x CAN
* 1x camera input
* 1x camera output
* 1x USB Mini-B    &#x20;

### Size and Weight

* Length: 63mm&#x20;
* Width: 43mm&#x20;
* Height: 16mm&#x20;
* Weight: 21g &#x20;


# Installation

{% embed url="<https://www.youtube.com/watch?v=pfHjs5ZuGpk&feature=emb_title>" %}

## Autopilot

The underneath of the autopilot has double-sided foam anti-vibration tape. Remove the protection layer of the anti-vibration tape and mount the autopilot in any direction you like, the actual direction can be selected during configuration procedures later. It’s recommended to mount the autopilot as close to the centre of gravity as possible.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hgq169Co1PetHs%2Fsmartap-v4-mounting.jpg?alt=media\&token=14db401f-fe61-4b1b-bea4-9feeed2993db)

{% hint style="info" %}
&#x20;"FRONT" arrow indicates the original flight direction. This can be changed in the settings later.
{% endhint %}

## GNSS / MAG

[GNSS Module](/avionics/smartap-gnss) provides positioning information to the system and is sensitive to EMI noise. Make sure to place the GNSS module as far away as possible from:

* Main body of the airframe
* RF emitting devices, such as video transmitters
* High-current cables (ESC / motors power supply)

It’s recommended to use GPS mast for GNSS positioning. Connect the cable and put the GPS on the mast.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4he4alhT-B1tKTN%2Fsmartap-v4-gps.png?alt=media\&token=76c05e6f-c851-4b6a-ae38-e143003c25b0)

## Connecting Peripherals

### Metal case version

Ports pinout for the front and rear panels&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hXsj8nD5QfumyI%2Fsmartap-max-connections.jpg?alt=media\&token=2d6ad4ce-3ab0-407e-a3de-3d2aeae58250)

Front panel connectors pinout:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hVG3ypd2BF7_HJ%2Fsmartap-max-connections-front.png?alt=media\&token=4d746f68-6ce2-4de9-b205-b4d983e40261)

Rear panel connectors pinout:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hW2GPhjRnEA6Zq%2Fsmartap-max-connections-rear.png?alt=media\&token=29faddbe-a8e0-4c9f-ba91-4a0751625f95)

### Plastic case version

Front panel connectors pinout:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4haWxcnONDexzCx%2Fsmartap-v4-connections-front.png?alt=media\&token=46a4e990-2edb-44a2-a837-565e3c92500f)

Rear panel connectors pinout:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hb5BoTUu6lW_Z3%2Fsmartap-v4-connections-rear.png?alt=media\&token=9287b976-e752-4457-ab3d-ffb657e8d5f3)

{% hint style="warning" %}
Make sure NOT to mix up polarity. GND line (black) is always nearer the edge (bottom)
{% endhint %}

## RC Receiver

Connect PPM / SBUS output on the RC receiver to PPM / SBUS input port on SmartAP.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hjxQ2Ux8Hxhg8-%2Fsmartap-v4-receiver.png?alt=media\&token=6b088e70-c3a0-43fc-9adb-6cddab40a32f)

## ESC / Motors PWM

Connect ESC cables to SmartAP PWM outputs 1-12 depending on the number of motors your airframe has. The first motor is always front or front-right, and its spinning direction is CCW. Supported airframe types and motor numbers / spinning direction are shown below.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hiKTDgxP7lUkrO%2Fsmartap-v4-pwm.png?alt=media\&token=c35c2d11-2589-4d0c-9a9c-013d2772de9a)

&#x20;PWM signals is the top wire, GND is the bottom one.

{% hint style="info" %}
If you can’t find your airframe in the list above, please, let us know and we’ll add your airframe! Contact us [here](https://sky-drones.com/contact-us).
{% endhint %}

## GNSS / MAG

Connect the one side of the cable to the GNSS module and the other one to the GPS / MAG port on the autopilot as shown in the images below:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hdkjcBjXc0_cAZ%2Fsmartap-v4-gps-connection.png?alt=media\&token=a01ee989-67f2-4e95-8ce1-ddf125ca5251)

## Telemetry Module

Connect the one side of the cable to the air telemetry module and the other one to the RADIO port of the autopilot as shown in the images below:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hk1IDNteLChBDm%2Fsmartap-v4-telemetry-connection.png?alt=media\&token=67c1445b-39c1-4c9d-aeb7-ecf71aa22062)

## Power Module

Connect the power supply cable (10-36 V, 3S – 8S) to the main power distribution board of the UAV.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hhRKUMiA34FCn4%2Fsmartap-v4-power-connection.png?alt=media\&token=ba551007-5554-44b7-8192-dfe6a88008cd)

## Electromagnetic sounder

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4h_50iTDbP3QS4r%2Fsmartap-v4-buzzer-connection.png?alt=media\&token=30f4ba13-aca5-4bf0-8c5b-aa62c8c7448b)

## Camera trigger

SmartAP MAX supports automated camera triggering interface:

* PWM output - if you want to use PWM output, simply connect the camera trigger activator into any free PWM channel and configure the port number later in the settings.
* Relay commutation - if you want to use relay, connect the pins (these should be shorted / unshorted depending on activation) to relay pins `RCOM` and `ROUT` (marked yellow):

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hUY3i3IGz8IxxT%2Fsmartap-max-connections-front-relay.png?alt=media\&token=d7c0b7e8-0805-4746-bad6-882a84aec35f)

If you would like to use camera feedback at the exact moment the photo was taken (for log file and precise geotagging later), then you need to connect `CS` and `GND` pins marked above to the signal and ground of the interface, thus providing camera feedback.

## Assembled System

Fully assembled and mounted system should look as follows:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPiEGlOhSEx1Str4HU%2F-MTPj4hZzbZtvNYE5uRr%2Fsmartap-v4-assembled.png?alt=media\&token=110d78b1-705d-48c3-90a0-5d98d0cb0f01)


# CAD Model

Download STEP files of [SmartAP MAX](https://sky-drones.com/smartap-max) for integrating into your own design:

{% file src="/files/-MTQkSVwNNQ0h4C8TWPS" %}
SmartAP MAX
{% endfile %}


# SmartAP PRO

## Introduction

[SmartAP PRO](https://sky-drones.com/smartap-pro) Autopilot is the latest generation of professional flight control systems for multirotor Unmanned Aerial Vehicles, capable of fully autonomous flight.&#x20;

The system has a powerful microcontroller, multiple redundant 9-axis Inertial Measurement Unit (IMU) (Gyroscopes, Accelerometers, Magnetometer) with temperature stabilization, integrated telemetry module, and an external [GNSS](/avionics/smartap-gnss) module with an integrated magnetometer. SmartAP supports any type of multirotor UAV with outstanding navigation and precision control.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuV3fpT0Z3mVz82%2Fsmartap-v32-features.png?alt=media\&token=eef5bd9e-a289-42c0-9f80-70762868a1c6)

## Set Includes

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuY9fJqpu2hiNKP%2Fsmartap-v32-kit-content.png?alt=media\&token=2429ba15-e8f4-40d6-8ac4-161b07f4dda7)

1. SmartAP PRO Flight Controller main board
2. External GNSS / Magnetometer module
3. Ground telemetry module
4. Onboard telemetry antenna
5. High-gain ground telemetry antenna
6. Power input cable
7. MicroSD card with SD card adapter

## Description

### Capabilities

* Outstanding flight stability in all modes - manual (user control), position hold (semi-autonomous control) and auto (fully autonomous navigation and control)
* Temperature-stabilized IMU
* Fully compatible with [SmartAP GCS](/flight-operations/smartap-gcs) Ground Control Station for configuration and mission planning
* Integrated OSD (On-Screen Display for FPV)
* Accurate GPS position hold (up to 40cm with good GNSS reception quality)
* Accurate altitude hold (up to 10 cm), manual altitude override option
* Return to home flight mode
* Fully autonomous waypoints flight mode
* Guided flight mode
* Various failsafe events configuration and triggering
* Operating temperature -40...+85C

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuXrh6VEcQWXZkx%2Fsmartap-v32-heating.png?alt=media\&token=86ec2905-e222-4cbf-8c92-d651dd16a0ba)

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8Lu_gkExIIhVcSuN%2Fsmartap-v32-power-supply.png?alt=media\&token=16e63010-904e-4647-b24f-803cd9343cac)

### General

* Powerful microcontroller 32 bit 168 MHz STM32F4 ARM Cortex M4
* Compact board size of 8x8 cm (3.15"x3.15"), weight 60g, 6 layers PCB design
* Power supply from the main LiPO battery (3S - 14S) support, up to 60 volts
* Power supply from BEC 5V support
* 12V, 5V, 3.3V generated onboard
* Integrated GNSS receiver UBlox NEO M8N, GPS/GLONASS, up to 24 sats, 10 Hz), active antenna
* Exnternal GNSS module support (primary configuration)
* Integrated 500 mW telemetry module (primary configuration)
* External telemetry module support&#x20;
* Integrated OSD module
* Up to 24 PWM I/O support (5V out, high-power)
* SBUS input support
* FrSky S.Port output support
* USB interface for configuration / firmware update
* Various communication lines (UART/USART, RS232, I2C, SPI)
* 6-pin JTAG port for programming / debugging
* MicroSD card driven by 4-bit SDIO interface for data-logging / parameters
* Backup battery for real-time clock and GNSS receiver
* Integrated main LiPo battery voltage monitoring
* 4 ADC inputs, battery voltage / current monitoring
* Electromagnetic sounder
* 3-channels bright LED support (up to 300mA/ch)
* RGB LED support
* 2-channel solid state relay

### Sensors

* IMU: InvenSense MPU-9150
* Magnetometer: Honeywell HMC5983L
* Pressure sensors: MS5611

### Flight Modes

* Stabilization
* Altitude hold
* Position hold
* Return to home
* Autonomous waypoints flight
* Guided
* Follow me
* Take off
* Landing

### Size and Weight

* Length: 80mm
* Width: 80mm
* Height: 17mm
* Weight: 39g


# Installation

{% hint style="warning" %}
**WARNING**!&#x20;

1\. Do not power on the board without GPS and wireless telemetry module antennas connected!\
2\. Do not disconnect antennas when the board is powered on!

Both of the above can void warranty on the device,
{% endhint %}

## Mounting the board

Mount your board on your copter airframe. It's highly recommended to mount the board as close to the geometrical centre of the copter as possible. Mounting should be done with four 3 mm nylon screws. Add rubber spacers to reduce motor vibration noise.

{% hint style="info" %}
Note the "FWD" arrow during instillation - FWD = Forward
{% endhint %}

## Connections

Connect the general peripherals as shown on the diagram below:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuPlxa1FpxglGqg%2Fsmartap-v3-connections.png?alt=media\&token=32652942-f630-4eab-ba67-0eb620d64b96)

![YOUTUBE](https://github.com/aviaks/Sky-Drones-Docs/tree/6f6ff0864814a7c3457ca64251342a996ffd515d/smartap-autopilots/iW9y64u4aB0)

### External GNSS / MAG

If you’re using external GNSS / Magnetometer module board, the connection should be as following:

#### SmartAP PRO 0.2 and later

The GNSS / Magnetometer cable goes to its dedicated GNSS / MAG port with 6 wires (`GND`, `SDA`, `SCL`, `RX`, `TX`, `5V`).

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuWb7AjKNXIw6vu%2Fsmartap-v32-gnss-connection.png?alt=media\&token=774b89c2-cbbd-4eac-99a8-cb516e8d9104)

#### SmartAP PRO 0.1 and Earlier

The GPS cable (4 wires: `GND`, `5V`, `RX`, `TX`) goes to its dedicated GPS port, whilst the magnetometer cable (I2C: `SCL`, `SDA`) goes to the dedicated magnetometer port as shown in the picture above.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuRrjCnvVuHV7MA%2Fsmartap-v3-gps-mag.png?alt=media\&token=fa7b6466-5ce7-45c5-a76c-cfb508c657e2)

Make sure to place the GPS module as far as possible from:

* Main body of the airframe
* RF emitting devices such as transmitters
* High-current cables (ESC / motors power supply)

### GPS Receiver

Connect the GPS antenna to its designated GPS antenna port. Note: this is only for versions with the integrated GNSS module.

### RC Receiver

After mounting the board you need to connect the cables from the RC receiver to SmartAP PPM / SBUS input.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuaXZBbEYpb_CI1%2Fsmartap-v32-sport.png?alt=media\&token=13a78202-41be-40f8-9206-8fde1048fd14)

You can also connect FrSky S.Port from FrSky receiver and get real-time telemetry on your FrSky transmitter (e.g. Taranis) screen. Simply connect the S.Port wire from the receiver to the `Tel` pin next to SBus input.

Channel assignments should normally be as follows:

* Input channel 1 – Roll
* Input channel 2 – Pitch
* Input channel 3 – Throttle   &#x20;
* Input channel 4 – Yaw
* Input channel 5 – Mode selection
* Input channel 6 – RTH Mode
* Input channel 7 – Auto Mode

Modes can be remapped in the configuration software later.

### RSSI Monitoring

If you want the flight controller to read the information about RSSI (Received Signal Strength Indicator) from RC receiver - simply connect the `RSSI` output and `GND` from your RC receiver to `PWM I/0 #13` for the flight controller. RSSI information will appear in the [GCS](/flight-operations/smartap-gcs) and also on the OSD screen.

### Motors ESC

Connect ESC inputs to SmartAP PWM outputs 1-12. The first motor is always front or front-right, its spinning direction is CCW.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuOv9cDRwJo51ex%2Fsmartap-v3-airframes.png?alt=media\&token=865862c8-be99-473f-8b3f-714e01042fb2)

{% hint style="warning" %}
Be sure NOT to mix up polarity!\
GND line (black) is near the edge, +5V line (red) in the middle, signal line (yellow) is on the upper row.
{% endhint %}

### Telemetry Module

Connect the telemetry antenna to the telemetry antenna port. If you would like to use a external telemetry module, connect `GND`, `5V`, `RX`, `TX` pins of the telemetry port to your external telemetry module. Later, you will need to disable the onboard telemetry module within [SmartAP GCS](/flight-operations/smartap-gcs) configurator software.

### OSD Video

SmartAP has a integrated OSD (On-Screen display) module. This means that you can connect your camera output to the autopilot (instead of directly connecting to the video transmitter) and then connect the video output from the flight controller to the video transmitter. In this case, the autopilot will relay the flight information (mode, altitude, speed, battery status, etc.) on the screen. Connect the video camera to the video IN port on the autopilot (`GND`, `12V`, `VIN`). Connect the video transmitter to the video OUT port on the autopilot (`GND`, `12V`, `VOUT`).

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuZCYFrc5j74zri%2Fsmartap-v32-osd.png?alt=media\&token=df19f81b-3e25-4047-aa2e-17712f8cdcca)

SmartAP OSD supports both PAL and NTSC video standards with automatic detection and configuration.&#x20;

{% hint style="warning" %}
Check the voltage ratings for your video camera and video transmitter! SmartAP outputs 12V and normally camera and video TX require a 12V power supply, however, some of the cameras / transmitters need 5V or other specific voltage levels. Check this carefully and provide the required voltage level. Otherwise, it can damage your camera / video TX!
{% endhint %}

### Electromagnetic ounder

Connect your electromagnetic sounder to the BUZ port of SmartAP.

### Power Supply

Connect the power supply cable from your main power distribution board on the UAV:

* SmartAP PRO 0.1 and earlier: 10-36 V, 3S – 8S
* SmartAP PRO 0.2 and later: 10-60 V, 3S – 14S

### LED & Buzzer

Buzzer: 12V, 0.2A (included in the kit) LED 1-4: 12V, 0.2A per each channel (enough to power an LED strip of 25cm in length)

### Pressure Sensor Foam

The pressure sensor is highly sensitive to the air pressure noise generated by the props and sunlight. It’s highly recommended to add foam coverage on the pressure sensor to decrease the noise effect and improve measurements. This will result in more precise altitude hold positions. For example:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuQN62aHRrU_Act%2Fsmartap-v3-foam.png?alt=media\&token=1eb542b4-0e63-48f2-bccc-1bca44dc9d1e)

### Dimensions

Dimensions of the board are 80x80mm. Diameter of mounting holes is 3mm, and distance between the centre of the mounting holes and board edges is 4.5 mm.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuSCK5Ya65dUhfs%2Fsmartap-v3-x-dimensions.png?alt=media\&token=fc32326d-db29-4bdb-b1ea-8b95b2ed5eaf)

### SmartAP PRO v .2 pinout

![](https://github.com/aviaks/Sky-Drones-Docs/tree/82cf82d8af7e9ee9508fc8b5d1fedc54ad2d3266/.gitbook/assets/smartap-v3-2-pinout.png)

### SmartAP PRO v .1 pinout

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuMDGRviOpNfzU_%2Fsmartap-v3-1-pinout.png?alt=media\&token=91eedec2-5ce1-4ec8-811b-2597270d030c)

### SmartAP PRO v .0 pinout

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQ7mZ6gZ-FTyBiRNCB%2F-MTQ8LuKCivmGczgO2s2%2Fsmartap-v3-0-pinout.png?alt=media\&token=90aebabb-4c06-453a-989c-a4520c77e6f7)


# Drivers

Occasionally the operating system can not detect the drivers or detects the drivers incorrectly. If you're experiencing any issues with connecting to the flight controller or firmware update procedure then you should reinstall the driver.

{% hint style="info" %}
It's recommended to uninstall all previous drivers associated with the autopilot before proceeding to the next steps.
{% endhint %}

First of all go to the `Device Manager` and delete the existing drivers if they are already installed. Then plug the flight controller into the USB port. You'll see a message that the new device has been discovered:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBWXKK0LcmWvfBU%2Fdriver-install-1.png?alt=media\&token=824e469b-d43e-4c35-bd9c-af90b94634b3)

If you click on the message you'll see more detailed information. The operating system is trying to find the driver for SmartAP Autopilot and its bootloader.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBXedSnMtwKyPmO%2Fdriver-install-2.png?alt=media\&token=eeee5113-b911-4d3c-b746-43aa6959c5a8)

It is unlikely that the driver will be found automatically, so you'll need to go to `Device Manager` and set the correct driver. When you open `Device Manager` you'll see SmartAP as an unknown device.

{% hint style="info" %}
If you cannot see SmartAP bootloader in the devices list it's probably because the devices is hidden. To make the bootloader device visible (not only for the initial three seconds after power up but for the foreseeable) you can enable hidden devices in windows device manager using the steps below.
{% endhint %}

* Open CMD as administrator
* Run `SET DEVMGR_SHOW_NONPRESENT_DEVICES=1`&#x20;
* Type `devmgmt.msc` into the open device manager
* Click `View` > `Show hidden devices`

More information and further details on the steps above can be found [here](http://www.thewindowsclub.com/show-non-present-devices-windows)

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBYUEVqKpGX-fOK%2Fdriver-install-3.png?alt=media\&token=70e056af-619b-4b61-b095-fe8e8425ab3e)

Right click on it and choose `Update Device Driver`.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBZSkQS8rIwGZCy%2Fdriver-install-4.png?alt=media\&token=1eb8f0e3-4c9f-4e2a-9a9c-bb25dfa4eb3e)

Then choose `Browse my Computer for Driver Software`. Go to the [download](http://sky-drones.com/dload) section of the Sky-Drones website and get the driver .inf file for the autopilot. Specify the location of the driver in the `Browse` menu.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndB_EJ9JgM4OGTFz%2Fdriver-install-5.png?alt=media\&token=41f8610b-cb21-4deb-ae65-ac04a07c21b5)

When the below pop up window comes choose `Install this driver software anyway`

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBaFFPfLLEoCWQJ%2Fdriver-install-6.png?alt=media\&token=185c8fcd-d146-4998-8a0c-c92525b124fc)

The process might take a few minutes.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBbcs2-7cdppG6K%2Fdriver-install-7.png?alt=media\&token=9278d2da-91e7-4ae2-bba4-e2ebf188bd05)

Once it's completed you can see the message that the driver was successfully installed.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBcm5Ma0fcDhf7h%2Fdriver-install-8.png?alt=media\&token=287420f7-e85d-4013-a19b-0a2457aa6fdd)

Unplug and plug in the USB cable of the autopilot to reboot the board. When you next go to `Device Manager` you'll see that the driver is now installed successfully:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBdCMiYmMwro4yG%2Fdriver-install-9.png?alt=media\&token=8e5f7b8b-db2a-43df-83d2-5808af2986e4)


# Getting the Software

Go to <http://sky-drones.com> to download the all new [SmartAP GCS](https://sky-drones.com/smartap-gcs).

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2Fsync%2F69e57b77e888d58289788a502123389f39bc9e1d.jpg?generation=1613164704138204\&alt=media)

Please refer to[ SmartAP GCS sign up section](/flight-operations/smartap-gcs/sign-up)


# General Configuration

It's recommended to use USB connection instead of wireless telemetry connection for the steps below.

{% embed url="<https://www.youtube.com/watch?v=h67RtzKW6a4&feature=emb_title>" %}

First of all, connect to the flight controller using the links management menu in the top-right corner. Then, click the gear icon in the left side of the toolbar: flight controller settings will appear.

## General

The general tab provides major information about the hardware you're using, installed firmware version, and unique ID of the flight controller.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCPWoo2L4-rOmHm%2Fsmartap-gcs-settings-general.png?alt=media\&token=1906897a-d39f-49c2-aeba-975aa5dd509a)

## Airframe

The airframe tab allows you to configure your vehicle type.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCJDxoRmNu0SY8D%2Fsmartap-gcs-settings-airframe.png?alt=media\&token=c3cc94be-c6c4-4c52-809f-e5233f766364)

Click `AIRFRAME` and choose your airframe from the list. If you can’t see your airframe there – feel free to [contact us](https://sky-drones.com/contact-us) and we’ll add your specific airframe type for you.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCIADn6WWgZrSb0%2Fsmartap-gcs-settings-airframe-selection.png?alt=media\&token=4032cfd3-cd51-4031-82e7-17f06d973b53)

Channel mapping and propeller rotations are shown on the corresponding images.

### System Orientation

You can choose the desired orientation of the flight controller and GNSS module from corresponding orientation menus.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCRQ3W7L3HpzPFD%2Fsmartap-gcs-settings-orientation.png?alt=media\&token=71258fb2-076d-4d31-8d0e-ade85a14e58a)

### Landing Gear

SmartAP allows you to configure automatic control of retractable landing gear. Simply select the output channel where your servo is connected to and adjust the minimum/maximum values as you desire. You may apply reverse if needed.

### Motors IDLE Speed

If you want the motors slightly spinning when the system is armed you can set motors IDLE speed to the desired value.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCQ1Xzk3xWmsszA%2Fsmartap-gcs-settings-idle.png?alt=media\&token=7f291b49-4446-4eed-b29c-81baa24cdd40)

## Radio

Go to the `RADIO` tab and choose the RC receiver protocol corresponding to the one you’re using. SBUS or PPM receivers are recommended. This change will take effect after the system is has been reset. Therefore, you will need to reboot the autopilot and connect again if you have made such changes so as to ensure the changes are applied immediately.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCWnVp6FNiGn0ps%2Fsmartap-gcs-settings-radio.png?alt=media\&token=df5442cf-2585-436a-987f-6fb64da4e00f)

Go to `Settings` > `RADIO` and make sure that your RC radio is turned on. You’ll see the sposition of the sticks displayed. Press the`CALIBRATE` button and move all sticks to their end points. Switch off the radio.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCVyznOfpi-l18b%2Fsmartap-gcs-settings-radio-calibration.png?alt=media\&token=922648cf-7f39-44cf-adc4-214c61c83944)

When it’s done – press the STOP button to stop calibration and save parameters. You can remap any action to the desired channel and apply reverse if needed.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCUAD39sb3zDOy0%2Fsmartap-gcs-settings-radio-calibrated.png?alt=media\&token=eb46c70b-f118-4fbe-bc1b-b29e3f05d6b2)

## Sensors

Sensors configuration tab allows users to perform accelerometer, gyroscope and magnetometer calibrations which are very important for heightened flight performance.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCaHcxS974VzjZ6%2Fsmartap-gcs-settings-sensors.png?alt=media\&token=9558dc85-817d-4579-8a42-8f0dc54c415a)

### Accelerometer Calibration

Click the`CALIBRATE` button near accelerometer data. Click `START` and follow the instructions shown after the procedure has begun.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCXPCMlb-7vi7hz%2Fsmartap-gcs-settings-sensors-accel.png?alt=media\&token=e1a7ef63-21bb-4c7f-8af5-176be9b3735d)

For accelerometer calibration you’ll have to place the autopilot in 6 positions:

* Top side up
* Top side down
* Left side down
* Front side down
* Right side down
* Rear side down

{% hint style="info" %}
It’s highly important to hold the system still in each position during the calibration. In each step the axis should be aligned with g-acceleration vector as precise as possible.
{% endhint %}

### Gyroscope Calibration

Click the `CALIBRATE` button near gyroscope data. Keep the board vert still and click `START.` Follow the instructions shown once the procedure has begun.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCZAg_dkYMY10wh%2Fsmartap-gcs-settings-sensors-gyro.png?alt=media\&token=c8d0ddfb-546f-4120-8ef4-14ba4c5f5c3a)

### Magnetometer

Magnetometer calibration is highly important for precise position hold and autonomous flight modes. Make sure that you’re outdoors and don’t have any metals around you or in your pockets (e.g. keys, cell phones, etc) before calibration.&#x20;

Press `CALIBRATE` near magnetometer data and follow further instructions. You will need to rotate the vehicle around three major axes (roll, pitch, yaw). After 60 seconds, the magnetometer calibration will be automatically completed and the pop-up calibration message will disappear.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndC_jhcCkKu7zvxU%2Fsmartap-gcs-settings-sensors-mag.png?alt=media\&token=026638d3-115a-4671-a7c3-318396529e09)

### GNSS Configuration

{% hint style="info" %}
Make sure that the GPS module is connected to the autopilot before proceeding to this step. Also, make sure that the green LED indicating power supply of the module is solid green (NOT flashing)
{% endhint %}

The sensors tab allows users to configure the GNSS module with the default parameters and messages required to work in unison with SmartAP Autopilots. Click the`CONFIGURE` button near GNSS data. Click `CONFIGURE` in the new window again and configuration changes will take an effect after system reboot.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCYPS-uHGhpAJvZ%2Fsmartap-gcs-settings-sensors-gnss.png?alt=media\&token=87d72936-75d1-4f86-985e-a0f4d4f7afea)

## Battery

Set battery sensor type. The system supports several battery sensors, including:

* Generic power module
* SmartAP PDB
* SmartAP 3.x internal monitoring&#x20;
* Custom

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCKxzLLS8m8IUb2%2Fsmartap-gcs-settings-battery.png?alt=media\&token=e9f50694-849d-4b28-af44-607e00078c96)

Set battery cells number and capacity. The system will notify you when the charge is too low.

If you're using a custom sensor then select `Custom` and provide the scalers for voltage and current. The scale value can be calculated as follows:

SCALE VALUE = SENSOR RANGE / 4096

## Tuning

SmartAP Autopilot is based on P-PID control algorithm. It means that the stabilization (the ability to stay in the air) and navigation (the ability to follow a desired trajectory) control algorithms include two loops: angle and rates control and position and velocity control. By default the gains (PIDs) are set to be the average for the majority of airframes, configurations, etc. Of course the parameters can be tuned precisely for better flight performance.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCblDtdyXfXtGub%2Fsmartap-gcs-settings-tuning.png?alt=media\&token=aeca4058-47e5-4a8a-8a87-411d9230649b)

Here is a brief guide for PID tuning:

1. Set all values to default.&#x20;
2. It's very important to tune the stabilization loop as precisely as possible since navigation is based on stabilization, so if not done properly, the vehicle will not hover and fly waypoints as precisely as you might like.&#x20;
3. The most important parameters are Stabilization Rate Roll / Pitch. Increase it until you see high-frequency oscillations or decrease it if you can already see them. Normally, this value is in between 0.1 – 0.2 depending on your airframe size, motors, ESC, props and vibration levels.&#x20;
4. If you can see low-frequency oscillations – it means that your Stabilization Angle Roll / Pitch is too high and you need to decrease it. This value lays in range between 3 - 6.&#x20;

Navigation gains can be tuned using the same approach, however, this is not essential as the values are fine by default for the majority of vehicle types.

More information on default gains is available in the [Standard PID Presets](https://github.com/aviaks/Sky-Drones-Docs/tree/35fe35ced3e791ceb7e3ce50c0fc08a880876b97/configuration/standard-pid-presets/README.md) section of this documentation.

## Control

Control tab allows users to manual configure control sensitivity, horizontal and vertical speed limits in various modes, and failsafe actions.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCOq6PZlI6Ksrru%2Fsmartap-gcs-settings-control.png?alt=media\&token=ec998263-2f96-495d-bfb1-e300f83eab5c)

## OSD

The OSD tab provides settings for On-Screen Display module configuration.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCSy44WTHl28UtC%2Fsmartap-gcs-settings-osd.png?alt=media\&token=5cd072a6-1bfa-44f5-b4f3-cd83f31fab66)

In OSD settings you can:

* Enable / disable the OSD module&#x20;
* Select either metric or imperial units depending on your preference
* Narrow the overlay area to fit the information on the screen
* Choose specific parameters you would like to be shown

OSD supports both PAL and NTSC video standards with auto-detection and selection. A typical information layout is shown on the images below:

PAL Layout

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBxbDE5_WcJh3RZ%2Fosd-layout-pal.png?alt=media\&token=6baae59f-5283-453c-b8db-1d3cc831a07c)

NTSC Layout

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBwOQ6fWn5MduWq%2Fosd-layout-ntsc.png?alt=media\&token=55035256-ff1a-42a3-905e-58b238494099)

The actual layout on the screen typically looks as follows:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBzDAYvCTe1XjHf%2Fosd-monitor.png?alt=media\&token=85f71bca-2ef3-4df9-ae45-b94fdb3c8ede)

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBy1QPEGp-XfWTM%2Fosd-monitor-2.jpg?alt=media\&token=193cf872-7cf6-409c-b788-b7b9cf7dcb0e)

## Camera

The camera tab allows you to configure the camera gimbal and shutter control settings.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCNftV8fXI7_HAw%2Fsmartap-gcs-settings-camera.png?alt=media\&token=98a0bd30-f9c8-4859-97f9-3be942871211)

`Gimbal`: the system supports 3-axis gimbal stabilization with flexible configuration for minimum and maximum output angles as well as minimum and maximum raw output values on the physical layer (PWM is used). As an option, the output can be reversed.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCLgidN6jC8tSwn%2Fsmartap-gcs-settings-camera-gimbal.png?alt=media\&token=53c5d92c-0830-477b-90e2-c16d6572c231)

`Shutter`: shutter configuration has settings for minimum and maximum output values for the triggering pulse. Interval is the length of time the pulse should be in an active state to initiate the shutter of the camera to trigger.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCMfTjJq49gvQ4C%2Fsmartap-gcs-settings-camera-shutter.png?alt=media\&token=c868781f-b53e-4db9-aa00-a2c51fe6488e)

## Parameters

The parameters tab gives you direct access to all parameters available in the system.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCTyp2qOBcgaStt%2Fsmartap-gcs-settings-params.png?alt=media\&token=a7bfdefe-6811-4220-8711-757a45bc1870)


# Firmware Update

{% hint style="danger" %}
**DANGER!**\
**NO BATTERY, USB CONNECTION ONLY!**\
Do not connect the main battery for the steps below. Use USB connection only!
{% endhint %}

## Latest firmware installation

{% embed url="<https://www.youtube.com/watch?v=SRamk5T0FUo&feature=emb_title>" %}

If you can see an exclamation mark icon ( **!** ) when pulling out the left-hand toolbar, it means that there is a firmware update available.&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCf_2v46gQ4w9tS%2Fsmartap-gcs-update-available.png?alt=media\&token=f57087ae-10ac-47da-9a3e-09fd3c330ca0)

Click `Firmware` and you will see the pane containing all the necessary information about the latest firmware, the upgrade button, and a progress indicator.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCCuTXyV5NxxWHe%2Fsmartap-gcs-firmware-tab-update-available.png?alt=media\&token=09efd105-e47f-4246-9432-3685629c2754)

You can click `WHAT'S NEW` if you want to learn more about the features introduced in the latest update, or click `UPGRADE` to begin the procedure. The firmware will be downloaded from Sky-Drones Cloud platform.

Sometimes after pressing the button you might see the reboot request. Simply plug out and then plug in flight controller USB cable.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCBkLGMYrT_i7He%2Fsmartap-gcs-firmware-tab-reboot.png?alt=media\&token=a5b12f0c-25ff-4d64-b0f6-ea8b66b16cb2)

If the upgrade procedure still has not started, make sure you don't have any other serial (COM port) devices connected to your computer.

Once the procedure has begun, you will see a progress notification and status update like the image below. Usually, an update takes between 30 to 60 seconds.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCF1I92GdfNB6Gb%2Fsmartap-gcs-firmware-upgrade-progress.png?alt=media\&token=c3f250f7-0204-4e86-8583-17d5d714b301)

After upgrading, you will see this confirmation message:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCDK9-WsBOUrnf8%2Fsmartap-gcs-firmware-upgrade-completed.png?alt=media\&token=0ae80b80-cf37-47b4-8300-434e7f25e8c8)

## Custom firmware upload

{% embed url="<https://www.youtube.com/watch?v=n81L5MTuUrw&feature=emb_title>" %}

If you want to upload custom firmware you may do that by clicking the "Options" icon (three dots) in the top-right corner. Simply click `Custom Firmware File`, select the file you want to flash and follow further instructions.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCA4Snjh1ywAgIt%2Fsmartap-gcs-firmware-tab-custom-update.png?alt=media\&token=570384a4-e4bc-4038-abd7-e64775c9800b)

## Getting the Log

If you're struggling during the firmware upgrade you might want to see the logs to further understand the issue or provide this information to our support team if you choose to contact us for assistance. Simply click the "Options" icon (three dots) in the top-right corner and select `Show Update Log`.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCEjpBlfDY8AtI3%2Fsmartap-gcs-firmware-upgrade-log.png?alt=media\&token=0ec93ea7-ce56-4d5b-b0f8-4086e8ab950e)


# Standard PID Presets

This section includes default parameter examples for various configuration types. You can find the airframe that most suits you and have parameter values for reference during tuning.

## MicroDrones MD4-1000 Quadcopter

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBgWXMXCn1AdPkV%2Fframe-md4-1000.png?alt=media\&token=9c71d0aa-9305-4963-8d26-250569422e56) ![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBn8PsgGN7e2nhO%2Fgains-md4-1000.png?alt=media\&token=a17fa35f-4e97-4cc7-9f36-ceb4b34a029b)

## T960 Hexacopter

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBhl1-I1nSCUxUD%2Fframe-t960-hexa.png?alt=media\&token=f30581b2-e2f8-41a9-89b0-5168434f7fc0) ![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBogwOeCvgaxGFg%2Fgains-t960-hexa.png?alt=media\&token=f61edd84-b6ca-441c-9f71-6d03c7be1282)

## F450 Quadcopter

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBfiPLOAmgbbuvV%2Fframe-f450.png?alt=media\&token=3b77e904-b1e9-4d4d-bd15-60a7826f2501) ![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBmovMl7te_PH0a%2Fgains-f450.png?alt=media\&token=cf37f92d-f10f-475f-a491-c54ee01df87a)

## 3DR Hexacopter

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBePQvszvmR69YY%2Fframe-3dr-hexa.png?alt=media\&token=c2be1763-d82b-4d3c-b041-a0d591a60df9) ![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndBlfsz8wtdzOlYu%2Fgains-3dr-hexa.png?alt=media\&token=a2a45d5f-23f2-40c1-ba34-82adbbf31c41)


# Flashing Bootloader

## Tools Required

Manufactured boards come WITHOUT bootloader pre-installed. You can easily flash them yourself. The tools needed include:

* ST-Link v2 ARM JTAG Debugger
* ARM JTAG Mini connector 1.25 mm pitch

## Connections

ST Link debugger looks something like this:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCremvt6l7Ym9ez%2Fst-link.jpg?alt=media\&token=d9cf03de-bab9-4626-ae96-422d4b0e0338)

You will need to connect the ST-Link pins to your SmartAP Pins.

The reference for ST Link pins:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndClPJbg6ABNxanb%2Fst-link-pinout.jpg?alt=media\&token=533bf233-a170-4ff7-ae66-d8570a3e13f3)

The reference for SmartAP JTAG pins (view from top):

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCk1N6s3OHpO4Xe%2Fsmartap-max-jtag.png?alt=media\&token=aa29824f-a6a1-435c-9a03-50388160e8c3)

Your connection should look like the below:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCmJs8nVu_YqoCS%2Fst-link-smartap.jpg?alt=media\&token=e8636ca7-85e3-45f5-8fc6-c0444237fc01)

Your autopilot and ST Link debugger should be powered via USB only.

## Flashing

Open STM ST Link Utility and then go to `Target` > `Program and Verify`:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCqFIPzDUvraVHW%2Fst-link-utility-main.png?alt=media\&token=09f69f04-ccfd-4a41-a845-580e1440b8cc)

Select the bootloader file to flash:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCo9s00eUjMgi14%2Fst-link-utility-file.png?alt=media\&token=847e7e35-7214-4200-9818-a56e92d6e4d5)

Finally, press `Start`

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCpp0a2Im98-sPt%2Fst-link-utility-flash.png?alt=media\&token=f10ee6c7-764b-4e91-807b-d30b4572fc02)

Once completed you'll see the following:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCno7PbMxymX4Nd%2Fst-link-utility-done.png?alt=media\&token=8850ccfc-f8ae-4caa-aef5-d47ebdac8196)

If you now see the board LEDs flashing, congratulations! Bootloader has been successfully flashed! Now you're able to install the firmware.


# SmartAP GCS

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2FqWbDcMWdkpxLoaIapYHO%2Fimage.png?alt=media&amp;token=97ef6340-0423-4f2e-985b-cc8aab60a8fa" alt=""><figcaption></figcaption></figure>

Configure, plan missions, and operate your drone with our cross platform ground control station software. The LTE connectivity allows users to sync their data pre, post, or during flights, and integrated HD video streaming gives a clearer and wider image than ever imaginable.


# Sign Up

Go to [http://sky-drones.com/dload ](http://sky-drones.com/dload)to download the all new [SmartAP GCS](https://sky-drones.com/smartap-gcs).

<figure><img src="https://449459530-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F-MTMlWysgDtJq8Hid1v7%2Fuploads%2F0ltX79IxZUfHtMUnc3FI%2Fimage.png?alt=media&amp;token=50934c28-4b70-41d9-aed1-649026b5dc16" alt=""><figcaption></figcaption></figure>

This software will allow you to configure the autopilot for your specific requirements and prepare your UAV for flight. The software will run on all popular platforms such as:

* Desktops
* Laptops
* Tablets
* Smartphones

And is available for the major operating systems:

* Windows
* MacOS
* Android
* iOS
* Linux&#x20;

This quick video tutorial will help you to download SmartAP GCS, create your user profile, log in and start using the app:

{% embed url="<https://www.youtube.com/watch?v=h3Trii_gxl8&feature=emb_title>" %}

Follow the steps below to install the application:

## First run

Run the application after installation. If you're able to see the authorization window like the one below, this means that the application was installed successfully and you may proceed to the next steps.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndC8ynoFcu7MTUlc%2Fsmartap-gcs-authentication.png?alt=media\&token=0429d40d-672b-4373-b654-ca21eb49e845)

## Create account

If you don't have an account yet you'll need to create one. Click `SIGN UP` and follow the simple form: provide your name, email, create a password, and you're done. You need an account to sync data across your platforms and operating systems, and exchange UTM information.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCcVfAMEJOFdxic%2Fsmartap-gcs-signup.png?alt=media\&token=05090a04-8e8b-435e-bf07-443b36bfc446)

{% hint style="info" %}
We recommend choosing a strong password containing at least 8 symbols with at least one number and special character.
{% endhint %}

## World pane

Once you fill in the details click `SIGN UP`. If you're registered successfully you'll be taken straight into the app and will see the main pane which is called World, just like the image below:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndC7r_R8k5xkH1mh%2Fsmartap-gcs-after-signin.png?alt=media\&token=9eb4a12a-f124-417c-8945-9bb9c3b5f7cc)

World pane provides all the necessary information about your flight and allows you to control the flight modes and plan your missions.

Toolbar gives the following general information and control:&#x20;

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-srEcP4r6zb-mkH%2Fsmartap-gcs-toolbar.png?alt=media\&token=69a1655e-0c2d-4131-9dc0-0f66764a00f5)

## App menu

If you pull out the menu from the left hand side, or click the three bars button, you'll see the app menu. You can go into your account settings, log out or switch between the application panes.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndC9azN07J1qVrjY%2Fsmartap-gcs-drawer.png?alt=media\&token=163a2280-2bb4-496a-baec-18f6baad0355)

## UAV settings

Clicking the gear icon will open the UAV settings menu. The main tab shows information concerning hardware, installed firmware and your unique ID. Tabs to the left provide the navigation between various settings of the flight controller which will be described later on.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCeUG-y6hBKdmY7%2Fsmartap-gcs-uav-settings.png?alt=media\&token=07bd8549-14c3-47ad-9773-e9a2c329314e)

## Links Management

In the top right-hand corner we can see the Links icon. Clicking this icon shows the connections management menu. There are a few communication types available:

* Serial&#x20;
* UDP
* TCP / IP

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCGXMFtpzGzXc8O%2Fsmartap-gcs-links.png?alt=media\&token=ff10be5e-9525-4513-9176-ec34cf626f23)

You can create and store a new Serial / UDP / TCP/IP connection by choosing COM Port and Baud Rate or providing IP & Port details. Connection can be established via USB or wireless telemetry.

Usually, baud rate for wireless telemetry connection is **57600.**

If you are about to configure a new flight controller unit it is recommended to use USB connection instead of wireless telemetry.

## First connection

Select the desired connection, click `ADD` and then `CONNECT`.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndC6BLMMvT8UJQJs%2Fsmartap-gcs-after-connect.png?alt=media\&token=f5351417-73f5-45dd-9aeb-a94aea146667)

If you have successfully created a proper connection, you will see the icons changing their state and hear confirmation that the UAV has been connected and parameters are being loaded. The toolbar will show the current time, total flight time, radio connection status, GNSS satellites count and status, link health, battery information, and so on.

{% hint style="info" %}
Sometimes you might get a message that you're using a partially incompatible version. This means that the functionality introduced recently might not be supported by your currently installed firmware and it's highly recommended that you update it.
{% endhint %}

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTPl4DQGq5TdbhbI5lr%2F-MTPndCHjvteeLG9UHmc%2Fsmartap-gcs-old-version.png?alt=media\&token=170e8123-6f51-4f66-9e9d-70a18f498793)

Therefore, if you see the message above, please, proceed to "[Firmware Upgrade](/avionics/legacy-autopilots/firmware-update)" procedure described in the next chapter.


# Radio Settings

Sky-Drones provides seamless integration of [SmartLink](/avionics/smartlink) into SmartAP GCS. This includes real-time status monitoring of RSSI and SNR as well as configuration of major RF parameters such as frequency, bandwidth and power. Security settings for changing the network ID / key are in the same popup.

{% embed url="<https://www.youtube.com/watch?v=0E6cpf9NUco&feature=emb_title>" %}


# Autonomous Flights

## Flights using Waypoints

Autonomous mission flights are based on waypoints navigation. To create a new mission, or to choose from your pre-planned missions, simply click the `PLANNING` button and then click the `MISSIONS` button.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-ska4j_ybH6Bafh%2Fsmartap-gcs-plan-mission.png?alt=media\&token=d07bfe43-ffc1-465e-89d9-c511a78122ef)

* To create a new mission, type the mission name followed by clicking `CREATE`
* To choose the already existing mission, you need only click on it

The below demonstration entails creating a new mission, so we click `CREATE`.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sgHlJMIDm2v52H%2Fsmartap-gcs-mission-menu.png?alt=media\&token=e8461b04-2053-45d5-8455-23c7ee8305f4)

After creating the mission, we can see the mission settings menu and Home point icon placed in the centre of the map automatically. You can drag your home point wherever you want.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sfSXRVaVBwkMMJ%2Fsmartap-gcs-mission-home.png?alt=media\&token=86eeff4c-a330-4e48-9a7a-d603b6cfe5a1)

{% hint style="info" %}
Home point will be overwritten by the initial vehicle location upon arming the system.
{% endhint %}

To insert a new waypoint, you need only double-click on any location on the map.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sa4JbgbwS2mTPh%2Fsmartap-gcs-mission-first.png?alt=media\&token=0684b329-6800-4982-a202-9b3820efbd4c)

Mission menu will automatically switch to Waypoint tab. Individual waypoint settings can be adjusted here.

* `Altitude`: Altitude in meters above take-off point (home altitude)
* `Delay`: Amount of seconds to hover before landing after reaching the waypoint
* `Speed`: Speed of flying to the next waypoint
* `Heading`: Heading angle in degrees to hold when flying to the next waypoint

When no waypoints are selected - those settings are returned to default values for new waypoints.

New waypoints can be added by double-clicking on the map:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sYbY8yc6-JS0pD%2Fsmartap-gcs-mission-all.png?alt=media\&token=19a1e62f-19a4-45f8-968b-d963438d89ac)

Of course, waypoints can be:

* Adjusted, by dragging them
* Deleted, by double-clicking on them
* Inserted in-between by double-clicking on the path

Waypoint parameters can be adjusted anytime after selecting the desired waypoint to be changed.

The system supports the following waypoint types (Commands) which can be changed by clicking on Command cell for a specific waypoint:

* Waypoint: regular point to fly through the air
* Take off: start autonomous take off
* Landing: perform landing over the point

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-siVu0xqvwiE_o0%2Fsmartap-gcs-mission-takeoff-land.png?alt=media\&token=51671ff7-214e-4de0-a0fc-fa375b5003eb)

The system allows the creation of various mission scenarios, including autonomous take off and / or landing point types, or having only waypoints in the list:

* In the first case the vehicle should be airborne before activating autonomous mode. After AUTO mode has been activated the vehicle will start flying to the first waypoint. If the system is not airborne then the vehicle will not allow the switching to autonomous flight mode.&#x20;
* In the second case the vehicle should be on the ground before activating autonomous mode. After AUTO mode has been activated the vehicle will start autonomous take off and then continue to fly to the next waypoint. If the vehicle is airborne before starting AUTO it will skip the initial take off waypoint.

After the mission has been created it can be saved and / or uploaded to the vehicle.

If you click `UPLOAD` you will notice the status of sending the mission in the bottom right-hand corner of the application:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sj1IZY7N8l1rrz%2Fsmartap-gcs-mission-upload.png?alt=media\&token=2405c9e5-6242-403e-a97c-9615b71e6615)

Finally, you will see a "Waypoints Received" message.

Before the flight you need to arm the system. The system can be armed using the RC transmitter stick or by clicking the "ARM / DISARM" button in the Ground Control Station (GCS).

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-s_d0aOremAPtS3%2Fsmartap-gcs-mission-arm.png?alt=media\&token=38d653cf-bee1-48b6-ac03-6c88e3c7d0f2)

{% hint style="info" %}
`ARM` command should be confirmed to make sure it wasn't clicked accidentally.
{% endhint %}

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sZLLyHG46q-GJd%2Fsmartap-gcs-mission-arm-confirm.png?alt=media\&token=28e84d1f-1b8e-4f6f-b6aa-c28fec35c761)

{% hint style="info" %}
Home position (including altitude) is set on every arm event. Make sure to arm the system after it has received the stable GNSS satellite signal. Saving the valid home position and altitude is important for calculating the waypoints altitude and ensuring the safe return of your UAV.
{% endhint %}

After you arm the system you will notice the home icon might have moved on the map. This position will be used for RTH (Return to Home) mode and its altitude will be used as an altitude reference for the waypoints. If you want to change the home position manually you can simply drag & drop it.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-shMm2aYzOVq8F6%2Fsmartap-gcs-mission-new-home.png?alt=media\&token=d4e55f94-27e0-472e-8a23-e51c2d618648)

If you don’t have the take off type on the waypoint in your list of waypoints, you’ll need to take off manually or press the `TAKE OFF` button on the right. After the vehicle is airborne you can press the "Fly" button or switch to auto mode using your RC transmitter. The vehicle will start flying to the first waypoint.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sbRY2jHdO2O73t%2Fsmartap-gcs-mission-fly.png?alt=media\&token=c55624cb-40d1-4bb6-9450-02733f016565)

Flight progress and indication of the vehicle's path can be seen in real-time. After the last waypoint has been reached the vehicle will enter hovering mode and maintain the altitude and position of the last waypoint, or perform landing if it was planned to do so.

## Guided flight

Guided flight mode can also be known as "Fly here" mode. This allows setting and moving the desired position of the vehicle interactively in real-time. This mode is available only if the vehicle is already flying in the air. To activate the guided flight mode, simply click the `PLANNING` button and then the `GUIDED` button.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-se6dnpqX23SxAA%2Fsmartap-gcs-mission-flyhere.png?alt=media\&token=b76d30ed-f6db-436d-b3aa-812585cef94a)

Once you have clicked on the map the vehicle will start flying to your indicated point and you will see the cross on the map indicating the target position of the vehicle.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sc-Gp7sFsQY0AN%2Fsmartap-gcs-mission-flyhere-fly.png?alt=media\&token=6ae7ac5f-5ac9-4bf9-a4c3-fa5aeb833dec)

The altitude and speed for the guided point can be set in the "fly here" settings menu in the top-right corner:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sdB4UeqpjFWaB_%2Fsmartap-gcs-mission-flyhere-settings.png?alt=media\&token=cacad686-94b9-4aec-bb51-35488e9b6775)

If you want to change the position of the vehicle you can simply drag and drop the cross on the map or right-click on the map and click "fly here". Repositioning can be done any time.

Once the vehicle has achieved the target position it will start hovering at the point whilst waiting for the next waypoint or flight mode change.


# Multiple Drones

{% embed url="<https://www.youtube.com/watch?v=sgStzSjOlJ0>" %}

An unlimited number of drones can be supported simultaneously with super easy and intuitive control through SmartAP GCS. For example, the above video shows a couple of drones participating in a autonomous survey mission while the third one is monitoring what they do.

## Multiple Drones with SmartLink

{% embed url="<https://www.youtube.com/watch?v=ELM7x115p88&feature=emb_title>" %}


# Rally Points

{% embed url="<https://www.youtube.com/watch?v=LjVAxx5vbqg&feature=emb_title>" %}

We pay high attention to drone flight safety during beyond visual line of sight (BVLOS) operations. Mission rally points is our latest feature introduced in the SmartAP GCS software and autopilot hardware. It allows the operator to set multiple emergency landing points along the flight path instead of a single home position.


# UTM and Airspace

Altitude Angel's airspace services are integrated into SmartAP GCS. Make sure to check your flight area in the drone control app before planning your mission!

{% embed url="<https://www.youtube.com/watch?v=Ael1W6E-qYY>" %}

Realtime ADSB data is available in SmartAP GCS:

{% embed url="<https://www.youtube.com/watch?v=sJhzckVa1d8>" %}


# Elevation Data

Integrated elevation profile visualization is available within SmartAP GCS. This feature allows you to create missions in and around complex terrain easier and quicker than ever before.

{% embed url="<https://www.youtube.com/watch?v=bYpuynTLPTc&feature=emb_title>" %}


# Camera Settings

Camera settings are very important for high quality drone photogrammetry and mission planning. Sky-Drones provides an intelligent mapping grid generator in SmartAP GCS with popular cameras supported and the option to add new ones of your choice.

{% embed url="<https://www.youtube.com/watch?v=PQ_GYp6DDTE&feature=emb_title>" %}


# RTK GNSS

RTK (Real Time Kinematics) - technology that allows the increasing accuracy of the GNSS module to a mere few centimetres. SmartAP Autopilots support RTK GNSS based on UBlox NEO M8P modules. This article demonstrates the procedure of setting up the flight with RTK GNSS.

It is assumed that you already have the following equipment:

* RTK GNSS module installed on a drone (also called Rover)
* RTK GNSS module as a base station with a USB connector
* Active patch antenna located on a ground plane (the middle of a car roof is a good example)
* Computer with SmartAP GCS installed
* Telemetry modules configured and working on both drone and ground station (telemetry is used to transfer corrections from base station module to Rover)

## Locating the antenna

{% hint style="info" %}
&#x20;RTK GNSS is very sensitive and needs to be set up with care
{% endhint %}

The base station antenna position should be fixed at all times. Please make sure that it is not able to move and has a clear view of the sky far enough from surrounding buildings. Essentially, ensure it is not shadowed by obstacles. A tripod or a car roof are good locations for the base station antenna.

Once you have located the antenna, connect the SMA cable to the ground module and plug the module into the USB port on your computer.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sVPww47b09iWK3%2Fgnss-rtk-plug-in.png?alt=media\&token=a8796b5f-d572-498e-98dc-0c7d900d001d)

`Solid green LED` - Power is on and module is working\
&#x20;`Blinking blue LED` - GNSS module has 3D position fixed

## Connecting in SmartAP GCS

First things first, open SmartAP GCS and connect it to the drone. Then go to the RTK tab at the bottom part of the Main Window. Choose the COM port of the GNSS module and press the `Connect` button. Once you're connected you'll be able to see the status of the base station module.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sUFWp8rXWE3d6U%2Fgnss-rtk-gcs-opened.png?alt=media\&token=17acc066-4fa3-471b-aa2c-7085118fad8d)

### Starting Survey-In

Once the base station has enough visible satellites, as long as solid 3D fix and position deviation is not high, you can start the Survey-In procedure by pressing the  `Start Survey-In` button. This procedure determines the accurate position of the base station based on the measurements. By default, it’s set to run for at least 3 minutes, and the accuracy deviation should be less than 1 meter. Note that longer measurements and smaller deviations will increase the accuracy of readings sent to the Rover. The measured accuracy and progress are shown on-screen. This process may take a few minutes.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNBnXWUEa3G7Nb8IS5%2F-MTNC0HPHmi40kuQpWLL%2Fsmartap-gcs-rtk-gnss.jpg?alt=media\&token=f514d3a5-daa0-4516-a4d3-8c2a1f1d7d46)

`3D Accuracy` - Positioning accuracy estimation for the last measurement (single measurement) `Mean 3D STD` - Standard deviation of the accuracy after Survey-In process has begun

### Survey-In completed

After the Survey-In process is completed SmartAP GCS will start sending corrections to the Rover. Survey-In status will change from `In Progress` to `Completed`.

If you take a look at the [GNSS](/avionics/smartap-gnss) status of the vehicle shown on the top panel, you'll notice the change from `GNSS` to `D-GNSS` meaning that the Rover module is receiving readings. The D-GNSS mode becomes active after a few seconds as the base station module starts sending corrections.

### RTK Modes

RTK has two modes: `Float` and `Fixed`. `Float` mode is easier to reach as it usually becomes available in 30-60 seconds after D-GNSS mode is active, however, it's less accurate. Later, the system will automatically go to `Fixed` where the accuracy will be higher but the process may take a little longer to complete.

> What will happen if the Rover looses connection with the base station?

The drone will continue flying. It is likely to do so with slightly less accuracy, however, if the connection has not been regained in 60 seconds, the GNSS module will go into regular mode. Once the connection has been re-established, the system will automatically go back into RTK mode.


# Logs Analysis

[SmartAP GCS](https://sky-drones.com/smartap-gcs) allows users to view, analyse, and export logs recorded on their SD card located in the flight controller.

To view your logs, go to the SmartAP GCS app > Plot tab in the left-hand menu.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sPGrxHTz7lw717%2Fgcs-left-plot.jpg?alt=media\&token=76af105b-28c5-400d-91a7-a6d2a87cca80)

Once you've switched to the "Plot" tab, click "Settings" in the top-right corner and select `Open log file`:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sT5dt6IDz1wiTq%2Fgcs-plot-open.jpg?alt=media\&token=83e9603f-5b67-4519-8f73-2b70ecce8c28)

Select the log file you would like to analyse from the system file dialog and click `Open`. You will see the log with all the available parameters. Choose your desired fields to plot them:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sSVHJmlKPsTzak%2Fgcs-logs-view.jpg?alt=media\&token=4e84be10-2236-4a04-83a7-1f2eff7185d4)

If you would like to export the log data as an image, KML track, or CSV file for further analysis, simply click "Settings" in the top-right corner and select the preferred option:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sRZg0Cgg16qjw6%2Fgcs-logs-export.jpg?alt=media\&token=6193c2b2-4919-41b8-afb1-f51d4398faa4)


# Geotag Images

[SmartAP autopilot](/avionics/legacy-autopilots), along with SmartAP GCS, allows users to precisely geo tag images for further post-processing. When the camera feedback pin is connected to the autopilot, the autopilot detects the exact moment the picture was taken and engraves this information into the log file. It contains the following information:

* ID - image sequence number
* Latitude - latitude location of the image
* Longitude - longitude location of the image
* Altitude - altitude of the image (MSL - above mean sea level)
* Roll - roll of aircraft
* Pitch - pitch of aircraft
* Yaw - yaw of aircraft

To geotag images, download the log file. Then open SmartAP GCS and open the left side menu:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-smRghxpa3GaBiK%2Fsmartap-gcs-plot-drawer.png?alt=media\&token=bc4f0bc5-2bd8-4283-a929-0c0d1fcab6af)

And go to `Plot` tab:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-spj_92EKGI_4MX%2Fsmartap-gcs-plot.png?alt=media\&token=d5190f37-ab10-40a9-b191-dde1e6fb6821)

Click the `Options` menu in the top-right corner and click `Open log file...`

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-socnta-M87ewtm%2Fsmartap-gcs-plot-open.png?alt=media\&token=4be8dc2e-1978-4736-8b87-86895aadfc11)

You can also simply drag and drop the desired log file into the "Logs" pane. Once the file is open, locate the`CAM_TRIGGER` group on the right panel.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sXxZCHaBkLTosz%2Fsmartap-gcs-geotag-selection.png?alt=media\&token=0b6cd380-29a8-42f9-94ca-3ccf8f4352ac)

Select the checkboxes for the fields you would like to export. Normally, all fields are recommended for further processing. Once selected - click `Options` and click `Export CSV`.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sl80nU9Zaiz0rC%2Fsmartap-gcs-plot-csv.png?alt=media\&token=784943b0-7efa-4e4a-9ca8-f00ad36c5bc0)

Then you select the folder destination that you'd like the log file to be exported to. After that you can open the file with any file editor and check its content:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-sn-i3BiaNW0yIJ%2Fsmartap-gcs-plot-exported.png?alt=media\&token=566ab942-2546-48bf-a51f-536fc15fb945)

Later, this information can be used for further post processing and map stitching.


# Processing the Logs

Log files are stored on the SD card as binary files and they're encoded for security reasons. However, you can extract the data and view it in a understandable text format (CSV format which can be later exported in XLS, Matlab, or anything else for post-processing and analysis).

You'll need to use the following Python script: [ulog2csv.py](http://sky-drones.com/download.php?file=ulog2csv.zip)

{% hint style="info" %}
&#x20;Python should be installed on your computer.
{% endhint %}

If you don't have Python, you can download it here <https://www.python.org/downloads/>, version 2.7.

To export the log, follow these simple steps:

* Open command line
* Go to the folder where " ulog2csv.py " script is located `cd /path/to/script`
* Execute the command:

  `python ulog2csv.py filename.ulg`&#x20;

  (**filename.ulg** is the path to the log file)&#x20;
* You'll see the folder will all log messages split in separate files

For instance, if you're interested in GNSS (GPS/GLONASS) data you would need **GNSS\_REPORT.csv** file.


# Video Streaming

SmartAP GCS has integrated video streaming support from 2 cameras simultaneously:

{% embed url="<https://www.youtube.com/watch?v=6hqPTZRCU8c&feature=emb_title>" %}

## Latency vs Quality settings

[SmartLink](/avionics/smartlink) and SmartAP GCS support user configurable video streaming parameters - the feed can be optimised for latency and for quality depending on your application requirements:

{% embed url="<https://www.youtube.com/watch?v=z6XDhzrIDGs&feature=emb_title>" %}

* Variable bitrate and manual bitrate settings vs video quality
* Latency vs quality optimisation
* Buffering produces a smoother picture for broadcasting applications

## Variable video bitrate

[SmartLink](/avionics/smartlink) by Sky-Drones supports variable video bitrate which can be set manually. In this office test we show the difference in quality between 100 kbps to 10 mbps. Autopilot is moved in front of the camera to make the feed less static and to show you potential artefacts at low rates.

{% embed url="<https://www.youtube.com/watch?v=F8tujzvUfw8&feature=emb_title>" %}

## LTE Video streaming

This demo demonstrates LTE Video streaming:

{% embed url="<https://www.youtube.com/watch?v=6p_qSKJUNTo&feature=emb_title>" %}

## Starting the video

SmartAP GCS allows you to see the real-time video feed right there in the application. Click on the gear icon in the bottom-left corner and select the video source you would like to use.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-suq9i3FSUNxDEE%2Fsmartap-gcs-video-settings.png?alt=media\&token=1fd4fe35-064b-45e9-9ad8-71f4275f5c3e)

After the video has started, you'll see it in the bottom left corner:

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-stzr05-KkAhIIV%2Fsmartap-gcs-video-feed-small.png?alt=media\&token=55ada78a-1576-424c-be04-65b5cb90ed03)

You can also enable full-screen video mode by clicking on the small video window. This will swap the map and video widgets. Easily swap back by clicking on the map pane to bring the video back to full-screen.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTNEpknb7U_l7PiHVZQ%2F-MTNG-ssbba0Raa7R834%2Fsmartap-gcs-video-feed-large.png?alt=media\&token=7cf68e46-31f3-419d-83ea-926145be3c56)

If you can't see your video source in the list of available devices, make sure to connect the video source to your computer before starting [SmartAP GCS](https://sky-drones.com/smartap-gcs) application.


# Sky-Drones Cloud

Bringing the way you interact and work with drones online! Cloud-based web application for drone fleet management, performance monitoring, mission planning, real-time control, post-flight AI analytics

![Sky-Drones Cloud Dashboard](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQXqimcbooPal5QFWI%2F-MTQY9-8pcMJF3q66QvQ%2Fheader-sky-drones-cloud.png?alt=media\&token=477bc170-4068-4463-bbab-72fe3c9a6ae4)

With Sky-Drones Cloud we provide an "Everything is Integrated Everywhere" approach\
which completely redefines the way companies build and operate commercial drones.

### Everything

Sky-Drones Cloud is the place for all data when working with and operating your fleet of drones. You don't need to have your data being distributed across multiple services or excel sheets which are difficult to share and can be lost. A Sky-Drones centralized hub for all information is the key when getting drone workflow to the next level.

### Integrated

Sky-Drones Cloud is tightly integrated with all hardware and software products including autopilots and SmartLinks. The data transmitted from the drone to the ground station is also available in the cloud. Data can be synced either post-flight or during the flight with LTE connectivity. Payload data gathering is integrated as well.

### Everywhere

Cloud can be accessed from anywhere and anytime. Drone and operator can be at the flight location while mission managers can observe the flight sitting in a command center on the other side of the globe giving valuable advice and getting exactly what they need. This brings situational awareness of using drones to a completely new level.

### Concept Diagram

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQXqimcbooPal5QFWI%2F-MTQZtlHesGAg4KDFY3M%2Fsky-drones-cloud-concept.jpg?alt=media\&token=4de40d2b-0aa5-4475-b944-2dfd7618f12b)


# Sign up and Log in

To sign up and log in, go to <http://cloud.sky-drones.com/> and create a new account.&#x20;

Follow the video tutorial below:

{% embed url="<https://www.youtube.com/watch?v=VBEdQ6UKevU>" %}


# Dashboard

Sky-Drones Cloud's powerful and flexible dashboard provides all major information at a glance. General information about assets, users and flights allows you to quickly estimate fleet performance and make well-rounded decisions with confidence. Filter over a certain period of time and within a specific fleet - we provide all the necessary tools for increasing the efficiency of your drone workflows.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQXqimcbooPal5QFWI%2F-MTQY9-8pcMJF3q66QvQ%2Fheader-sky-drones-cloud.png?alt=media\&token=477bc170-4068-4463-bbab-72fe3c9a6ae4)


# Drones and Operators

Interested in which drone is used the most? Who your most experienced pilot is? The pilot the highest number of flight hours in the team? Drone and pilot analytics allows easy access to all this information, plus much more! Sky-Drones Cloud is just like Google Analytics... for Drones.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQXqimcbooPal5QFWI%2F-MTQcE_69VNggjMmfRjQ%2Fcloud-users.jpg?alt=media\&token=b22d56ed-c901-486d-bd61-3ea18008e054)


# Flight Locations

The flight locations widget allows fleet managers to understand how vehicles are being used, ensures that all operations are compliant, and that they stay within the required regulations. Filter for a certain period of time or specific fleet - all the tools needed for highlighting exactly what you need to see are readily available.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQXqimcbooPal5QFWI%2F-MTQcPAv8HKnXubYlhV6%2Fcloud-locations.jpg?alt=media\&token=9bfcbb1d-2f76-443d-bc55-d3a26f0f58b6)


# Fleet Management

The fleet management part of Sky-Drones Cloud allows you to keep track of all your assets within the company. Data is synchronized in real-time with drones using LTE networks. Check for the currently installed software version on the vehicle and update remotely when necessary. Interested in real-time flights? Use this page to see which drone and/or pilot is online now right now.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQXqimcbooPal5QFWI%2F-MTQcVHf-5agdLpXIaLh%2Fcloud-drones.jpg?alt=media\&token=54b91430-3d76-4481-ae81-37e128215172)

Sky-Drones Cloud provides entire-fleet readings and status updates on one screen, with clear visuals as to where each drone has been, where its next mission is, and the type of terrain that will be encountered. Meanwhile, located in the same hub of information, flight hours, battery life, and real-time flights/flight logs provide the necessary information to maintain a vast fleet of drones.


# Flight Logs

Every flight log is stored in the cloud and is accessible when you need it, no matter where you are in the world. Detailed flight log analytics helps to ensure the best possible flight performance of your vehicle and detect potential mechanical issues before your customers or pilots become aware.

Flight logs allow the user to create a detailed history of all historic, ongoing, and future drone operations. Constant flight log monitoring ensures safe and reliable operations for the whole fleet and for each individual drone/pilot.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQXqimcbooPal5QFWI%2F-MTQce493uTP48KcYIY_%2Fcloud-logs.jpg?alt=media\&token=aefc57b0-f776-4e59-a47f-f7f0a7eadfa7)

### DroneLogbook Integration

Sky-Drones Cloud offers Dronelogbook integration for exporting the flight logs to our partner.&#x20;

{% embed url="<https://www.youtube.com/watch?index=11&list=PLflAsraehVEZ567sdxgcvOXLVDb3JXF5k&v=amEAsH2Qbrk>" %}


# 3D Mission Planning

{% embed url="<https://www.youtube.com/watch?v=La3PkNGyZV4&feature=emb_logo>" %}

Add waypoints interactively and view the flight plan from any perspective. Rotate, change view angle, tilt, view from the surface, then get back to the orthogonal view again before completing your mission. Adjust waypoint position and altitude interactively to achieve the best mission planning user experience.


# Integrated UTM

Sky-Drones have integrated Altitude Angel, AirMap, and High Lander UTM services into Sky-Drones Cloud. To explore drone and airspace integration using Altitude Angel, watch the video below:

## Altitude Angel UTM Integration

{% embed url="<https://www.youtube.com/watch?v=ZqMWScIPCaY&t=4s>" %}

### 3D Terrain and Ground Hazards data

Instead of relying on elevation profiles to plan missions, pilots get an intuitive 3D view that allows them to visually create flight paths with interactive waypoints, all in the context of high-resolution World Terrain. Terrain data is integrated with weather information and airspace data from [Altitude Angel](https://www.altitudeangel.com/), helping pilots avoid ground hazards, manned flights, and other airspace restrictions.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQXqimcbooPal5QFWI%2F-MTQagfk9wG0tqjE2InC%2F3dwaypoints_mission_planning_and_ground_hazard_power_lines_display.jpg?alt=media\&token=31a9f20a-9bef-417b-bfd7-10ee4cde114f)

### Airspace Data

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQXqimcbooPal5QFWI%2F-MTQaprOxi-y81WVS8nU%2Fdetailed_information_about_the_area.jpg?alt=media\&token=6eac5635-4a4e-40a3-8582-8a82ec12aff5)

### Real-Time Flight Authorization

Sky-Drones Cloud supports real-time flight request and authorization with [Altitude Angel](https://www.altitudeangel.com/). Find your intended flight area and submit a flight plan. This airspace will be reserved for you and this will be publicly available on Altitude Angel's online Drone Safety Map.

#### Cylinder Flight Plan

{% embed url="<https://www.youtube.com/watch?v=3Iidbm2S9vQ&t=11s>" %}

#### Corridor Flight Plan

{% embed url="<https://www.youtube.com/watch?v=1bSr7rFWwMQ>" %}


# Real-Time Flights

Enjoy real-time LTE drone control and video streaming with Sky-Drones Cloud and SmartLink. Everything is web-based - you need only your login and password, no need to install any software whatsoever.

{% embed url="<https://www.youtube.com/watch?v=KqbPkaEFnIA>" %}

Sign in to the Cloud, select the desired online vehicle, fly via LTE networks. We provide the necessary infrastructure for ultra-low latency flights over the internet without any additional software requirements. Fly right in your web browser with HD video alongside all major telemetry. Operate multiple drones on a single page.

![](https://449459530-files.gitbook.io/~/files/v0/b/gitbook-legacy-files/o/assets%2F-MTMlWysgDtJq8Hid1v7%2F-MTQXqimcbooPal5QFWI%2F-MTQavek-gpXf1roU2mo%2Frealtime_cell_tower_inspection_and_video_streaming.jpg?alt=media\&token=cc55fb2b-6266-45ac-996d-04bbd078a76c)


# Sky-Drones API

API reference: <https://cloud.sky-drones.com/swagger/>